29 WSN Coverage Algorithms

More
Depth: Practitioner
Progress saves as you read. Mark sections complete as you go; your progress appears in the sidebar.
29.1 Start With the Field Story
This section: Start With the Field Story — Picture smoke sensors spread across a store room.
Treat Coverage as a Claim You Can Challenge
Picture smoke sensors spread across a store room. A map of neat circles may suggest that every point is watched. Shelves, weak batteries, poor placement, and a failed relay can still leave a gap that the drawing does not show.
Write the coverage claim in plain terms. Name the area or targets, the sensing limit, the number of independent views needed, the energy state, and the faults the design must survive. Then choose a method that checks that exact claim or selects which nodes stay awake.
Compare the planned result with known points in the real space. Turn off one active node, lower its range, and change the set that sleeps. Check whether the method detects the gap, selects a safe replacement, and preserves a path for the result.
A model only proves its own assumptions. The deeper sections compare checking, active-set choice, rotation, and gap repair so every result keeps its input facts, field check, and retest trigger.
Coverage algorithms are tools for choosing and checking active nodes. Start with the evidence they need: positions, ranges, redundancy target, energy state, failure assumptions, and a way to prove gaps are repaired rather than hidden.
29.2 In 60 Seconds
This section: In 60 Seconds — WSN coverage algorithms help a team answer four practical questions: is the claimed area covered, which sensors should stay active, how should active sets rotate, and what should happen when a gap appears.
WSN coverage algorithms help a team answer four practical questions: is the claimed area covered, which sensors should stay active, how should active sets rotate, and what should happen when a gap appears. The algorithm is only one part of the decision. A reviewer also needs the sensing model, communication path, energy state, operating limits, and retest trigger.
Use this chapter as an algorithm-selection guide. It keeps the algorithm families meaningful while avoiding claims that a diagram, rule of thumb, or simulation proves field coverage by itself.
29.3 Learning Objectives
This section: Learning Objectives
By the end of this chapter, you will be able to:
- Distinguish coverage verification, active-set selection, rotation scheduling, and gap repair algorithms.
- Select an algorithm family that matches the coverage claim and available evidence.
- Identify the assumptions that can invalidate an algorithm result in a real WSN.
- Build a review record for an algorithm decision.
- Avoid overclaiming lifetime, reliability, or automatic repair from algorithm output alone.
29.4 Quick Check: WSN Coverage Algorithms
This section: Quick Check: WSN Coverage Algorithms
29.5 Algorithm Families
This section: Algorithm Families — Coverage algorithms are easiest to review when each family is tied to a specific job.
Coverage algorithms are easiest to review when each family is tied to a specific job. A single chapter or design document may mention several algorithms, but each algorithm should still have a clear role.
Placement and scheduling problems are often expressed with familiar optimization vocabulary. A graph-coloring view can model neighboring sensors or cells that should not sleep at the same time, while a facility-location view can choose gateway or sensor positions that minimize distance, cost, or uncovered demand. Those formulations are useful only after the coverage type is clear, because the same graph or facility objective can optimize the wrong thing if the real claim is a barrier, path, point, or active-set coverage requirement.
29.6 Selection Route
This section: Selection Route — The next choice depends on separating Coverage Claim from Area, point, path,.
The next choice depends on separating Coverage Claim from Area, point, path,. The figure at Figure 29.1 makes that boundary visible before the chapter commits to selection route.
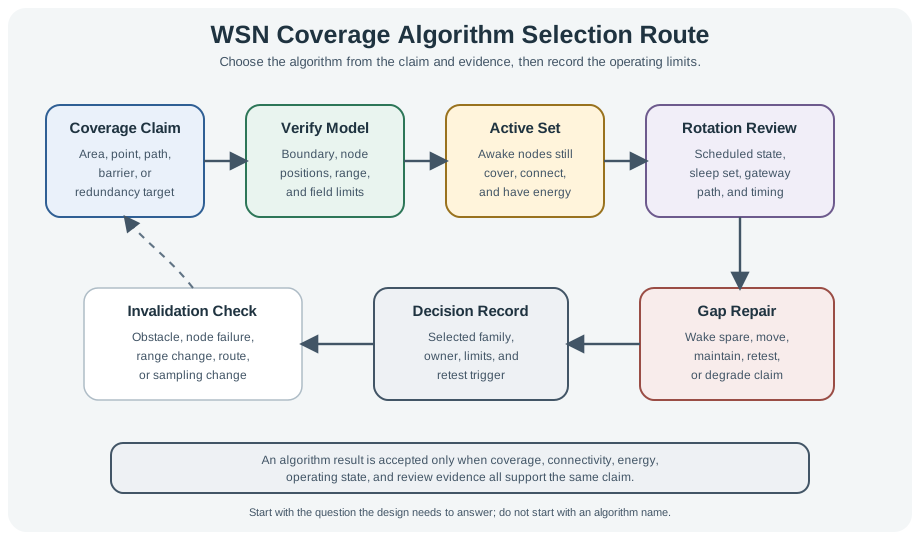
Enter Figure 29.1 at Coverage Claim, which defines what the design promises. Continue to Area, point, path,, where the visual fixes the spatial boundary; then check redundancy target, which defines what the design promises. This progression makes the point concrete: WSN coverage algorithm selection route that starts with the coverage claim, verifies the model, checks the active set, reviews rotation, repairs gaps, and records decision limits. The result feeds the chapter’s selection route decision with the boundary still attached.
29.7 Verification Algorithms
This section: Verification Algorithms — Verification algorithms test the claim.
Verification algorithms test the claim. They do not choose the best deployment by themselves; they tell the reviewer whether the current claim has enough support.
For area coverage, verification checks whether the monitored region meets the accepted sensing model. For point coverage, it checks the target list. For barrier coverage, it checks crossing paths or boundary segments. For redundant coverage, it checks whether the claimed redundancy survives the stated failure or sleep condition.
29.8 Active-Set Algorithms
This section: Active-Set Algorithms — Active-set algorithms select a subset of nodes to keep awake.
Active-set algorithms select a subset of nodes to keep awake. This can reduce energy use, but the review must check coverage, connectivity, and timing together. A set that covers the area but cannot deliver data is not an accepted active set.
The output should be recorded as a decision, not a guarantee. The record should say which nodes are active, which nodes are sleeping, which claim the active set supports, and what change invalidates the selection.
29.9 Crossing-Point and OGDC Checks
This section: Crossing-Point and OGDC Checks — The merged OGDC chapter adds useful detail for dense area-coverage designs.
The merged OGDC chapter adds useful detail for dense area-coverage designs. Crossing-point verification can focus a geometric review on likely hole boundaries, but only when the sensing model is close enough to disk-like area coverage for the shortcut to be valid.
Use crossing-point evidence when:
- the monitored boundary is known
- node positions and sensing ranges are bounded well enough for geometry to matter
- obstacles, directionality, weather, calibration drift, and position error are either represented or listed as limits
- the result is retested after node failure, range change, rotation, or field repair
Evidence for Crossing-Point and OGDC Checks starts in Figure 29.2. Look at Crossings not covered beside monitored square region before accepting the relationship behind Crossing-Point and OGDC Checks.

In Figure 29.2, one crossing between sensing disks falls outside every disk even though nearby regions appear covered. Check each such crossing against the monitored region before approving coverage; a visual impression of overlap is not enough.
OGDC-style active-set selection is also a review decision, not a guarantee. Record the local coordination rule, position evidence, candidate activation rule, suppression rule for redundant neighbors, frontier or uncovered-region response, rotation interval, and coverage verification after each accepted active set.
The geometric target behind OGDC’s coordination rule is worth naming so “optimal” is not taken on faith: for equal-radius disks, overlap between three neighboring active sensors is minimized when each is placed at distance sqrt(3) * r_s from the other two, where r_s is the sensing radius — an equilateral spacing, not an arbitrary one. OGDC selects already placed nodes close to that target without central coordination: a starting node begins the round, a neighbor near sqrt(3) * r_s from it is selected, and subsequent candidates use their deviation from the target position and a back-off timer to contend for the active role. The closest available node tends to be selected; the algorithm does not move nodes into the ideal positions.
Inspect Figure 29.3 to see how three local placement choices form the triangular spacing used by OGDC.

Start with X, which establishes the first active point. A node Y near √3 × r_s from X is selected; if the sensing radius is 10 m, the ideal target is about 17.3 m. A node Z near the corresponding target completes an approximately equilateral triangle. The three sensing disks can cover their crossings while avoiding the heavier overlap caused by placing nodes too close together. This is the geometric target, not proof of field coverage: actual node positions, obstacles, position error, failed nodes, and radio connectivity still need separate checks before nodes may sleep.
If the design depends on OGDC, the record should say which claim the sleeping nodes still support, which communication path remains connected, and what happens when the algorithm reports a hole or cannot converge.
29.10 Rotation Scheduling
This section: Rotation Scheduling — Rotation scheduling moves the active role between sensor sets.
Rotation scheduling moves the active role between sensor sets. It is useful when the deployment has enough overlap to rest some nodes without losing the accepted coverage condition.
The reviewer should inspect the worst scheduled state, not just the best state. If one rotation step leaves a target uncovered or isolates a node from the gateway, the rotation needs repair.
29.10.1 Rotation Review Record
Claim: what coverage must remain true during rotation. Schedule: which active set is used in each state. Evidence: coverage and connectivity check for each state. Limit: battery, failure, or layout condition that breaks the schedule. Retest trigger: node replacement, moved sensor, changed sampling interval, or changed duty cycle.
29.11 Gap Repair
This section: Gap Repair — Gap-repair algorithms turn detected weakness into a response.
Gap-repair algorithms turn detected weakness into a response. The response is not always activation. Sometimes the right response is to mark a zone as degraded, dispatch maintenance, change the route, or reject the coverage claim until a retest passes.
The diagram at Figure 29.4 earns attention because gap repair spans Trigger Evidence and Weak zone signal. Reading both prevents a local success from becoming a system claim.
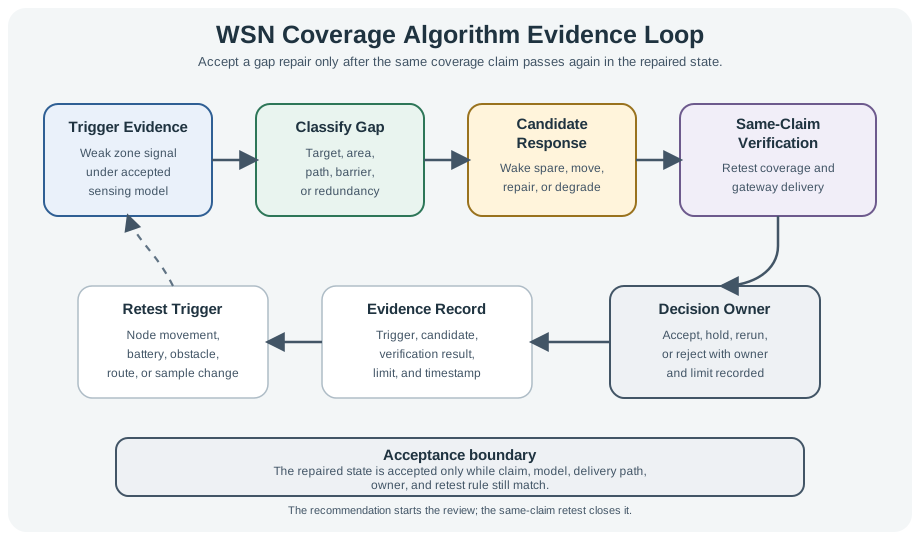
The visual logic of Figure 29.4 can be checked at three named points. Trigger Evidence establishes the starting condition; after that, Weak zone signal fixes the spatial boundary; at the boundary, under accepted records the bounded outcome. Together they mean that wSN coverage algorithm evidence loop tying weak-zone trigger evidence to gap classification, candidate response, same-claim verification, decision owner, and retest trigger. Keep that logic attached to gap repair.
29.12 Worked Review: Verification First
This section: Worked Review: Verification First — A team wants to deploy an area-coverage algorithm for a greenhouse.
A team wants to deploy an area-coverage algorithm for a greenhouse. The planning map looks complete, but the reviewer notices that one row of sensors is mounted behind dense foliage and the acceptance model has not been updated for the obstruction.
The review decision is to hold the claim. The algorithm may still be useful, but the sensing model is not yet aligned with field conditions.
29.13 Worked Review: Active Set
This section: Worked Review: Active Set — A facility chooses an active-set algorithm to reduce always-awake operation.
A facility chooses an active-set algorithm to reduce always-awake operation. The selected nodes cover all machine targets, but two selected nodes route through a sleeping relay.
The active set is not accepted as operational coverage. The fix may be to keep a relay awake, choose a different active set, add a gateway path, or separate the sensing and routing roles in the review record.
29.13.1 Decision
The coverage part of the active set is plausible, but the communication part is incomplete. The record should say “retest required” rather than “accepted” until the selected active state can sense and deliver the readings.
29.14 Worked Review: Gap Repair
This section: Worked Review: Gap Repair — A deployment detects a weak zone after a sensor fails.
A deployment detects a weak zone after a sensor fails. The gap-repair algorithm suggests waking a nearby spare node. The reviewer asks for three pieces of evidence before accepting the repair.
29.15 Implementation Checklist
This section: Implementation Checklist — Use this checklist when reviewing or selecting a coverage algorithm.
Use this checklist when reviewing or selecting a coverage algorithm.
29.16 Common Mistakes
This section: Common Mistakes
29.17 Knowledge Check: Algorithm Role
This section: Knowledge Check: Algorithm Role
29.18 Knowledge Check: Repair Evidence
This section: Knowledge Check: Repair Evidence
29.19 Match the Coverage Algorithm Concept
This section: Match the Coverage Algorithm Concept
29.20 Order the Algorithm Review Process
This section: Order the Algorithm Review Process
29.21 Algorithm Output Is an Approval State
This section: Algorithm Output Is an Approval State — For Algorithm Output Is an Approval State, inspect Figure 29.5 before deciding how Requirement constrains or k-coverage.
For Algorithm Output Is an Approval State, inspect Figure 29.5 before deciding how Requirement constrains or k-coverage. That labelled relationship grounds WSN coverage algorithm review map.
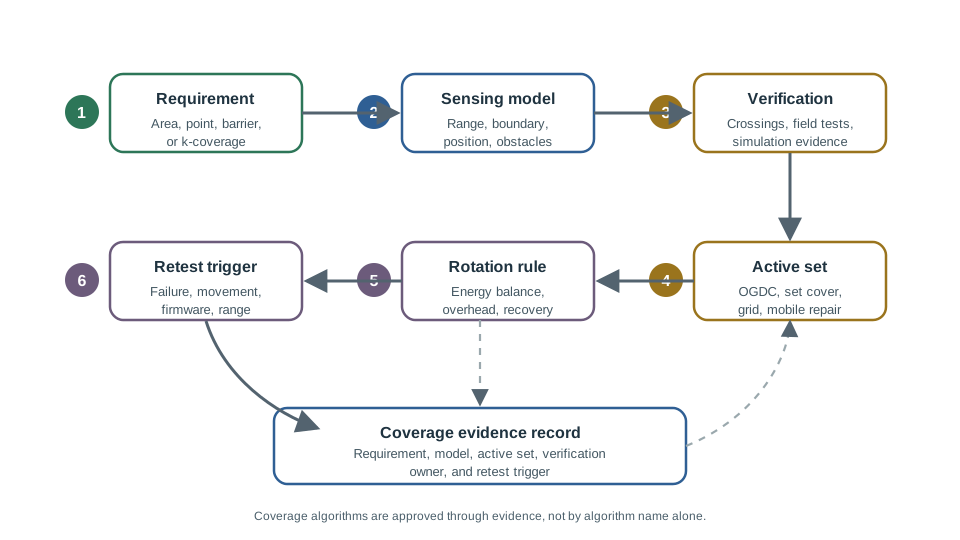
Figure Figure 29.5 places an algorithm result inside a coverage decision. The requirement first names area, point, barrier, or k-coverage. A sensing model then states range, boundaries, positions, and obstacles; verification needs crossings, field tests, or simulation evidence. The active set says which nodes actually count, and the rotation rule covers energy balance, overhead, and recovery. A failure, move, firmware change, or range change triggers review again. This explains why a selected node set is only an approval state for one model and operating window. The evidence record also names the owner who must close remaining field checks.
This framing prevents a common failure in WSN coverage work. A team may run an active-set algorithm, see that the selected nodes cover the drawing, and then describe the result as accepted coverage for the site. The approval state is narrower than that. It says: under this sensing model, with these active nodes, this delivery path, this sleep rule, and this operating window, the claim passed this verification check. The decision can be useful and still remain conditional.
The state also exposes who owns the next action. A verification algorithm may return “covered” while the field team still owes a mounting retest. A rotation schedule may look balanced while the network team still owes a route check for the worst scheduled state. A gap-repair algorithm may find a spare node while operations still owns the maintenance decision. The algorithm output is therefore the start of an evidence record, not a substitute for one.
29.22 Build an Active-Set Ledger
This section: Build an Active-Set Ledger — For a practitioner, the most useful artifact is a short ledger for each accepted active set.
For a practitioner, the most useful artifact is a short ledger for each accepted active set. The ledger does not need to be complex. It needs to keep the algorithm’s output connected to the evidence that made it acceptable. Each row should name the selected nodes, the sleeping nodes that matter, the coverage claim, the delivery path, the energy or duty-cycle condition, the owner of the decision, and the trigger that forces a retest.
The ledger is especially important when an active-set algorithm and a rotation schedule are both used. The active-set algorithm might identify several candidate awake sets. The rotation schedule then chooses when each set runs. A reviewer should not approve the average schedule while ignoring the weakest state. The accepted state is the worst scheduled state that still passes sensing, delivery, and energy checks. If the first set covers the target list but the second set loses the gateway route, the schedule is not accepted even if the lifetime estimate improves.
| Ledger field | What to record | Why it matters |
|---|---|---|
| Claim | Area, point, barrier, path, redundant, mobile, or hybrid claim. | Prevents an active-set result for one problem type from being reused as proof for another. |
| Active nodes | Node IDs, role, sensing state, and communication role for the accepted set. | Separates nodes that sense from nodes that only forward data. |
| Sleeping nodes | Nodes allowed to sleep, plus any reserved node that must wake on failure. | Makes the energy-saving claim auditable and repairable. |
| Verification result | Coverage condition, route condition, and timestamp of the accepted evidence. | Shows whether the set passed in the state that will actually run. |
| Limit and retest | Battery, firmware, obstacle, relocation, sampling, or target-list change that reopens the decision. | Stops a stale algorithm output from surviving after the field state changed. |
A good ledger also handles partial acceptance. A selected set can be accepted for point coverage of machine targets and rejected for area coverage between those machines. A spare node can be accepted as a repair candidate and still require a route retest before it becomes operational. A mobile or rotating state can pass during one operating window and fail during another. Recording those limits is not bureaucracy; it is how the team avoids turning an optimization result into a broader coverage promise.
If the algorithm output cannot be written as a ledger row, it is not ready for release. The missing field tells the reviewer what evidence to request next.
29.23 Finite Geometry Model Boundaries
This section: Finite Geometry Model Boundaries — For finite geometry model boundaries, a result at disk 1 is incomplete without disk 2.
For finite geometry model boundaries, a result at disk 1 is incomplete without disk 2. The figure in Figure 29.6 shows why those labels belong in one review.

Read disk-disk last in Figure 29.6. disk 1 has already adds a distinct review condition, and disk 2 has adds a distinct review condition; the final label adds a distinct review condition. This order makes the caption operational: Two overlapping sensing disks over a rectangular monitored region boundary, with circled dots marking the crossing points: where the two disk boundaries intersect each other, and where each disk boundary crosses the region boundary. It supplies the evidence hand-off for finite geometry model boundaries.
The shortcut becomes unsafe when the model is looser than the geometry. Directional antennas, obstacles, foliage, enclosure placement, calibration drift, radio interference, uncertain node position, and duty-cycled sampling can all make the real sensing footprint different from a clean disk. In that case, the geometric candidates are still useful test points, but they are not the whole acceptance record. The algorithm can say “under this disk model, the finite candidates pass.” The field record must still say whether the disk model is accepted for the deployed state.
Voronoi and Delaunay structures have the same review boundary. They are excellent ways to find local sparse regions, likely hole corners, and neighbor relationships without brute-force scanning every point. They are not proof that a sensor actually measured the target variable under final conditions. That is why the chapter pairs geometric checks with active-state, route, energy, and retest evidence. The geometry narrows the search; the review record decides whether the narrowed result is enough.
29.24 Knowledge Check: Active-Set Evidence
This section: Knowledge Check: Active-Set Evidence
29.25 Summary
This section: Summary — WSN coverage algorithms are decision aids.
WSN coverage algorithms are decision aids. Verification algorithms test the claim, active-set algorithms choose awake nodes, rotation schedules move work over time, and gap-repair algorithms choose responses to weak coverage. None of these outputs should be accepted without the sensing model, connectivity path, energy state, operating limits, owner, and retest trigger.
The highest-quality algorithm review is specific. It says what question the algorithm answered, what assumptions were used, what output was accepted, and when that decision must be reopened.
29.26 Key Takeaway
This section: Key Takeaway — Select the coverage algorithm from the claim, then accept the output only when the sensing model, operating state, evidence, owner, and retest trigger are recorded.
Select the coverage algorithm from the claim, then accept the output only when the sensing model, operating state, evidence, owner, and retest trigger are recorded.
29.27 Concept Relationships
This section: Concept Relationships — WSN Coverage Fundamentals supplies the sensing models, target claims, and boundary assumptions that algorithm results depend on.
WSN Coverage Fundamentals supplies the sensing models, target claims, and boundary assumptions that algorithm results depend on. WSN Coverage: Problem Types separates area, point, barrier, path, and hybrid coverage before choosing an algorithm family. WSN Coverage: K-Coverage and Rotation expands redundancy and scheduled coverage review.
29.28 What’s Next
This section: What’s Next — WSN Coverage Worked Examples applies verification, active-set, rotation, and repair decisions to review scenarios.
WSN Coverage Worked Examples applies verification, active-set, rotation, and repair decisions to review scenarios. WSN Coverage Implementations carries algorithm evidence into deployment acceptance and operations. WSN Coverage: K-Coverage and Rotation deepens redundant coverage and scheduled active-set review.
Find help
3 reviewed answers.
Where should I start in a module?
Open the module page from the sidebar to see its chapters in order. Use the module map to return to a topic you need.
Modules and pathsReviewed
What can I try when a project does not work?
Check the symptom, then work through the diagnostic steps. Keep the error message and the smallest example that reproduces it.
When you are stuckReviewed
How do interactive examples work?
Use the interactive guide to check how examples and simulations work before changing your project.
Interactive examples guideReviewed