31 Production Sensor Fusion and Validation
More
Depth: Practitioner
Progress saves as you read. Mark sections complete as you go; your progress appears in the sidebar.
31.1 Start With the Measurement Story
This section: Start With the Measurement Story — Picture a delivery robot entering a bright loading bay.
Let Independent Sensors Disagree
Picture a delivery robot entering a bright loading bay. Its camera says the way is clear, while its distance sensor reports an object ahead. A system that always prefers one reading may turn a useful warning into a confident mistake.
Start with the decision and the conditions that can fool each sensor. Record what each part measures, its unit, update time, useful range, and known weak cases. Keep the original readings beside any combined result so a reviewer can see whether agreement was real or forced.
-
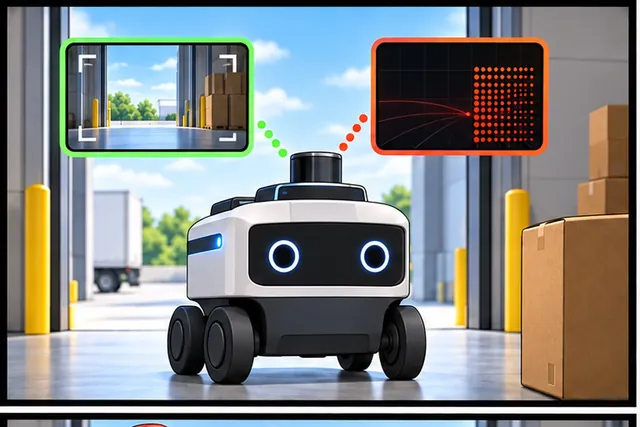
A delivery robot enters a bright bay and its two sensors disagree.
-
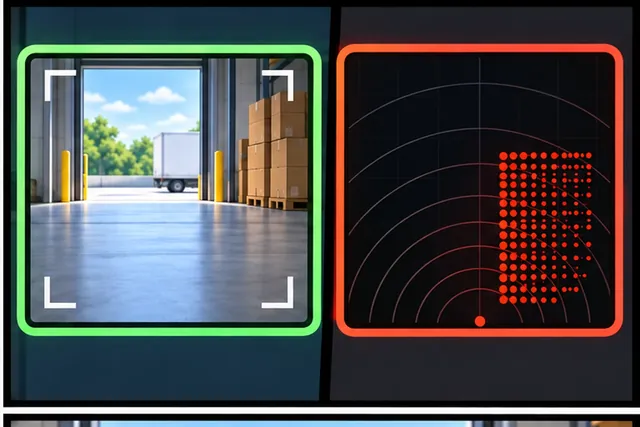
The camera sees a clear path while the distance sensor sees an object.
-
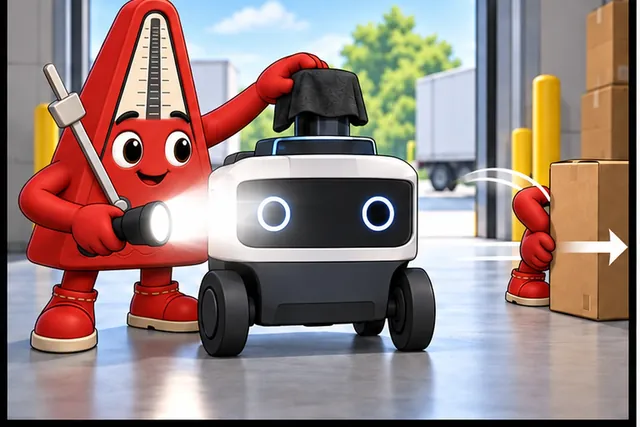
Add glare, cover a sensor, delay one reading, and move the target.
-
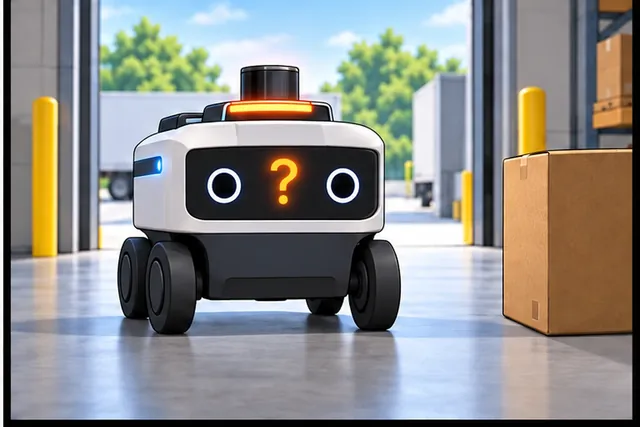
Mark doubt or stop safely instead of hiding conflict in one number.
Illustrated scene: A delivery robot enters a bright bay and its two sensors disagree.
Test a normal scene, then cover one sensor, delay another, add glare, and move the target quickly. The system should mark uncertainty, reject an impossible jump, or choose a safe action. It should not hide disagreement behind one smooth number.
More sensors do not always mean a better answer. Shared placement, weather, or code can make several parts fail together. The deeper sections explain how production checks and fusion methods handle bias, timing, quality, and common-cause failure without claiming certainty that the evidence cannot support.
Production fusion is less about clever math and more about accountable evidence. Start with the deployment claim, then define sensor health checks, disagreement rules, fallback behavior, and validation data before trusting a fused result.
The mathematical gist. For fixed electrode geometry, capacitance changes in the same ratio as soil permittivity. The chapter’s cubic model gives at 10% VWC and 6.12 at 12%, a 14.5% rise. At 30% and 32% VWC it gives 16.9 and 18.4, a 9.2% rise. The same two-point moisture change therefore creates a nonlinear electrical change, and fouling can imitate that change without any real shift in water content.

This chapter moves from field reliability to practical fusion choices:
- First we look at why bench-tested sensors fail in production, including field drift, dirty sensing surfaces, and unit mismatches.
- Then we turn those failures into validation rules: retries, range checks, last-good fallback, alerts, and logs.
- Next we choose between complementary, competitive, and cooperative fusion strategies.
- After that we tune a complementary IMU filter and decide when Kalman-style filtering is worth the added complexity.
- Finally we connect the fusion math back to averaging windows, production pitfalls, quizzes, and next chapters.
Checkpoints recap the operational rule you should be able to use immediately; optional “deep” sections are useful on a second pass.
31.2 Production-Quality Sensor Systems
This section: Production-Quality Sensor Systems — This section uses field-failure mechanisms to plan validation and maintenance.
Building on the earlier sensor-fusion, noise-characterization, and Kalman-filtering chapters, this page shifts from algorithm theory to field reliability: sensor health, disagreement rules, fallback behavior, validation evidence, and maintenance.
This section uses field-failure mechanisms to plan validation and maintenance.
31.2.1 Why Sensors Fail in Production
Bench calibration does not establish field performance. The following table lists plausible mechanisms to check; its examples are not measured deployment results.
| Deployment | Possible field influence | Evidence to collect |
|---|---|---|
| Agricultural soil moisture (capacitive) | Soil composition, temperature, water distribution, and probe installation | Reference samples across local soils and seasons |
| Urban air quality PM2.5 (optical) | Humidity, aerosols, and optical contamination | Collocation against a reference monitor, with cleaning records |
| Bridge structural vibration (MEMS accelerometer) | Mounting change, temperature, offset drift, and damaged wiring | Baseline and self-test trends, plus periodic reference checks |
Key lesson: The installed measurement chain needs a documented verification interval based on the sensor, site, and consequences of error. A sealed package does not guarantee unchanged accuracy. A built-in self-test can reveal some faults but does not replace calibration against a reference.
31.2.2 Mars Climate Orbiter Unit Mismatch
Mars Climate Orbiter (1999) illustrates a failed engineering-unit interface in navigation.
What happened: NASA’s mishap investigation found that a ground software file supplied impulse data in pound-force seconds where the interface required newton-seconds. Navigation used those data in trajectory estimation; the mismatch was a factor of about 4.45. The incident is a unit-interface failure, not evidence that a particular sensor fusion algorithm failed.
Sensor fusion lessons learned:
- Unit consistency is non-negotiable - All sensor data entering a fusion system MUST use consistent units
- Validate at boundaries - Check that incoming data is within expected ranges
- Document sensor specifications - Every sensor interface should explicitly state units, ranges, and update rates
- Independent verification - Have a separate system verify fused outputs make physical sense
The fix that’s now standard: Modern sensor fusion systems include:
- Explicit unit metadata in all data streams
- Automatic unit conversion layers
- Sanity checks (e.g., “is this thrust value physically possible?”)
- Independent trajectory validation
Root cause reported by NASA: the specified metric unit was not used in a ground software file; verification and communication failures contributed.
31.2.3 Fitbit Sensor Fusion
How consumer wearables achieve accurate step counting and activity tracking
A Fitbit Charge 6 combines sensor signals for activity features. Its user manual lists the components below; sampling rates and a universal step-counting accuracy are not specified there.
The sensor array:
| Sensor | Purpose |
|---|---|
| 3-axis accelerometer | Detect motion patterns |
| Optical heart-rate tracker | Measure pulse-related optical changes |
| Built-in GPS receiver | Track location during workouts |
The fusion challenge: Arm movement can resemble steps to a simple threshold on acceleration. A device can use motion history and other available signals to reduce false counts, but the specific algorithm and accuracy must be verified for the named product. Do not assume a gyroscope or barometer is present in Charge 6.
Illustrative step-counting workflow (not a published Charge 6 algorithm):
1. Detect candidate steps from repeated accelerometer motion.
2. Reject isolated arm gestures using timing and motion history.
3. Use heart-rate and GPS readings, when available, as activity context rather than proof of each step.
Why single-sensor fails:
A simple accelerometer threshold can mistake some arm gestures for steps. Motion history and other available signals can help an activity classifier, but the Charge 6’s step-counting algorithm and accuracy percentages are not published in the cited product specifications.
Key insight: Better activity tracking can depend on sensor choice, software, testing and power budget; compare measured performance and full product cost before attributing a price difference to fusion algorithms.
Reliability Checklist:
| Aspect | Requirement | Implementation |
|---|---|---|
| Power supply | Filtered, stable | LDO regulator + decoupling caps |
| Communication | Error detection | CRC on sensor data |
| Redundancy | Backup sensors | Dual sensors for critical measurements |
| Calibration | Traceable | NIST-traceable reference, documented |
| Logging | Fault tracking | Store raw + processed data |
| Watchdog | Recovery | Hardware watchdog, auto-reset |
| Updates | Field upgradeable | OTA firmware updates |
Error Handling Best Practices:
A production sensor read should follow this sequence:
- Try more than once: attempt the read up to three times before declaring failure.
- Validate before using: reject missing values, impossible values, and values outside the sensor’s physical range.
- Cache the last good value: use it only as a temporary fallback, not as permanent truth.
- Count repeated failures: one bad read is noise; many bad reads indicate a real fault.
- Alert and log: notify operators when the failure count crosses the threshold, and keep raw evidence for debugging.
This pattern keeps the system running safely while making sensor faults visible instead of silently hiding them.
This section:
Checkpoint: Production Validation
You now know:
- Bench accuracy does not establish field accuracy: validate soil probes in the actual soil and installation.
- Set verification and cleaning intervals from manufacturer guidance and site evidence, then adjust with observed drift.
- A robust read path tries again, rejects impossible values, uses the last good value temporarily, counts repeated failures, then alerts and logs.
31.2.4 Try It: Sensor Validation SimulatorTry: Sensor Validation Simulator
Simulate sensor readings with configurable failure modes and see how robust validation catches bad data.
31.2.5 Sensor Fusion Decision Guide
Sensor fusion falls into three categories based on how sensor data relates to each other:
| Strategy | When sensors measure… | Example | Algorithm |
|---|---|---|---|
| Complementary | Different aspects of the same phenomenon | GPS (position) + IMU (motion) + barometer (altitude) for 3D tracking | Kalman filter, complementary filter |
| Competitive | The same quantity independently | Three temperature sensors on the same pipe for redundancy | Voting, weighted average, median |
| Cooperative | Data that individually is insufficient | Camera + LiDAR for object detection (appearance + depth) | Deep learning, feature fusion |
These three labels trace back to Durrant-Whyte’s (1988) classification of multi-sensor configurations, and the textbook illustrations are worth knowing because they make the boundary between complementary and cooperative concrete. The classic complementary example is about coverage, not accuracy: mount several cameras around a room so each one watches a different, non-overlapping corner. No single camera sees the whole room and none of them contradicts another — each is simply filling a gap the others cannot see, which is why complementary fusion is described as resolving incompleteness rather than boosting accuracy. The classic cooperative example is stereoscopic vision: two ordinary 2D cameras at slightly different viewpoints, each individually incapable of measuring depth, are combined by triangulation to derive a 3D image that neither camera alone could produce. That is also why cooperative fusion is the hardest of the three to design well — the output does not exist in any single input, so an error in either camera degrades the fused result directly, with no redundant reading available to vote it down.
| If your project needs… | Choose… | Because… |
|---|---|---|
| Broader coverage across a scene | Complementary fusion | Different sensors fill gaps in what each can observe |
| Fault tolerance for safety-critical measurement | Competitive fusion | Triple redundancy with voting rejects faulty readings |
| Information that no single sensor can provide | Cooperative fusion | Combined data creates emergent capabilities (e.g., gesture recognition from accelerometer + gyroscope + magnetometer) |
| Real-time filtering with known system dynamics | Kalman filter | Optimal for linear systems with Gaussian noise, runs on MCU |
| Quick prototype, two complementary sensors | Complementary filter | Single tunable parameter (alpha), simpler than Kalman |
| Non-linear system (e.g., attitude estimation) | Extended Kalman (EKF) or Madgwick | Handles rotation quaternions, common in IMU fusion |
Quick Decision Flowchart:
- Are you combining redundant sensors for fault tolerance? Yes —> Competitive fusion (voting/median)
- Are you combining sensors that measure different physical quantities? Yes —> Complementary fusion (Kalman filter)
- Do you need new information neither sensor provides alone? Yes —> Cooperative fusion (ML-based)
- Is the system linear with well-known dynamics? Yes —> Standard Kalman filter
- Is the system non-linear (rotation, complex motion)? Yes —> Extended Kalman or Unscented Kalman filter
- Default: Start with a complementary filter (simple alpha-blend), upgrade to Kalman when accuracy demands it
This section:
Checkpoint: Fusion Strategy
You now know:
- Complementary fusion combines different views of the same phenomenon; competitive fusion compares redundant readings; cooperative fusion creates information no single sensor can provide.
- A simple accelerometer threshold can mistake arm gestures for steps; evaluate any added signals against manually counted steps in the intended activities before claiming better accuracy.
- The first design question is whether you need better accuracy, fault tolerance, or a new capability.
31.2.6 Try It: Fusion Strategy RecommenderTry: Fusion Strategy Recommender
Answer a few questions about your project and get a recommended sensor fusion strategy.
31.2.7 Complementary IMU Tilt Filter
Scenario: An IoT inclinometer for construction equipment measures tilt angle using an accelerometer and gyroscope. The accelerometer provides absolute tilt but is noisy (vibration). The gyroscope provides smooth rotation rate but drifts over time. Combine them using a complementary filter.
Step 1: Understand sensor characteristics
Accelerometer (measures gravity vector):
- Accuracy: ±2° (when stationary)
- Noise: ±10° (with vibration from engine)
- No drift over time
Gyroscope (measures rotation rate):
- Short-term accuracy: ±0.1°/s
- Drift: 0.5°/minute accumulated error
- Smooth, no vibration noise
Step 2: Implement complementary filter
The filter trusts the gyroscope for short-term changes (smooth) and the accelerometer for long-term reference (no drift).
import math

class ComplementaryFilter:
    def __init__(self, alpha=0.98, dt=0.02):
        """
        alpha: Weight for gyroscope (0.98 = 98% gyro, 2% accel)
        dt: Sample time interval (0.02s = 50 Hz)
        """
        self.alpha = alpha
        self.dt = dt
        self.angle = 0  # Current tilt angle estimate

    def update(self, accel_x, accel_y, accel_z, gyro_x):
        """
        accel_x/y/z: Accelerometer readings (m/s²)
        gyro_x: Gyroscope rotation rate (°/s) around X-axis
        """
        # Calculate angle from accelerometer (noisy but absolute)
        accel_angle = math.atan2(accel_y, accel_z) * 180 / math.pi

        # Integrate gyroscope (smooth but drifts)
        gyro_angle = self.angle + gyro_x * self.dt

        # Complementary filter: blend both estimates
        self.angle = self.alpha * gyro_angle + (1 - self.alpha) * accel_angle

        return self.angle

import time

# Usage example
filter = ComplementaryFilter(alpha=0.98, dt=0.02)  # 50 Hz update rate

while True:
    # Read sensors
    ax, ay, az = read_accelerometer()
    gx, gy, gz = read_gyroscope()

    # Update filter
    tilt_angle = filter.update(ax, ay, az, gx)

    print(f"Tilt: {tilt_angle:.1f}°")
    time.sleep(0.02)  # 50 Hz loop
Step 3: Tune alpha parameter
| Alpha | Gyro Weight | Accel Weight | Result |
|---|---|---|---|
| 0.90 | 90% | 10% | Fast response to tilt, but vibration noise visible |
| 0.98 | 98% | 2% | Smooth output, slow correction of drift (recommended) |
| 0.995 | 99.5% | 0.5% | Very smooth, but drift accumulates noticeably after 5 minutes |
Step 4: Measured performance
Testing on a vibrating platform (simulated construction equipment):
| Method | RMS Error (stationary) | RMS Error (vibrating) | Drift after 10 min |
|---|---|---|---|
| Accelerometer only | 1.8° | 9.2° | 0° (no drift) |
| Gyroscope only | 0.3° | 0.3° | 5.1° (significant drift) |
| Complementary filter (α=0.98) | 0.8° | 1.2° | 0.3° (minimal drift) |
Key insight: The complementary filter trades some short-term gyro accuracy for much less long-run drift and far less vibration error than accelerometer-only estimation; its value is the combined trade-off, not the lowest value in every table column.
When to upgrade to Kalman filter: If you need to fuse more than 2 sensors (e.g., add magnetometer for heading), or need to model complex dynamics (vehicle motion with GPS, IMU, wheel odometry), use a Kalman filter. For simple 2-sensor fusion, complementary filter is sufficient.
Checkpoint: Complementary Filters
You now know:
- Alpha is a trust knob: alpha = 0.98 means 98% gyroscope weight and 2% accelerometer weight each update.
- The example filter runs at 50 Hz, so each update uses dt = 0.02 s.
- In the vibrating-platform test, the complementary filter keeps RMS error to 1.2 deg with only 0.3 deg drift after 10 min.
31.2.8 Complementary Alpha Tuner
Adjust the alpha parameter to see how it balances gyroscope smoothness against accelerometer drift correction. The simulation shows a tilting platform with engine vibration.
Legend: Gray = accelerometer (noisy), red dashed = gyro only (drifts), teal = complementary filter, orange dashed = true angle (15 deg).
31.2.9 Quadcopter Fusion Decision
Using the decision framework above for an ESP32-based quadcopter flight controller:
- Sensors: MPU6050 (accel + gyro), BMP280 (barometer), GPS.
- System: Non-linear (attitude uses quaternions).
- Computational budget: ESP32 (240 MHz) can handle 1000 Hz EKF.
- Memory constraints: Particle filter requires too much RAM; unknown noise is not an issue (MPU6050 is well-characterized).
Decision path:
Start by attitude (roll/pitch/yaw) — 3 sensors, non-linear dynamics —> Extended Kalman Filter. Finally altitude — 3 sensors (barometer + GPS + accel Z-axis), approximately linear —> Standard Kalman filter.
Alternative for beginners: Start with a complementary filter for roll/pitch (accel + gyro), use barometer-only for altitude, then add GPS later with Kalman when ready.
31.3 Longer Averaging Can Mislead
This section: Longer Averaging Can Mislead — The scenario: An engineer averages 100 capacitive soil moisture readings over 10 seconds, expecting 10x noise reduction.
The scenario: An engineer averages 100 capacitive soil moisture readings over 10 seconds, expecting 10x noise reduction. After deployment, readings still wander by +/-3%.
The root cause: As explained in Part 1, the sensor’s 1/f corner frequency (0.5 Hz) means averaging below that frequency captures more drift, not less. The optimal window is ~1 second (staying above the corner), not 10 seconds.
Real-world example: The Vegetronix VH400 soil moisture sensor has a 1/f corner at ~0.2 Hz. The manufacturer recommends averaging for 2 seconds maximum. Customers who averaged for 30 seconds (0.033 Hz) saw WORSE stability than those using 2-second averages---because they were averaging in the 1/f-dominated region.
Key lesson: Always check the sensor’s 1/f corner frequency before choosing an averaging window. Refer to the mitigation strategies in Part 1 for solutions.
This section:
Checkpoint: Averaging Windows
You now know:
- More samples do not automatically mean a better production value when 1/f noise dominates.
- The soil-moisture example shows why 100 readings over 10 seconds can be worse than an averaging window near 1 second.
- The VH400 example reinforces the rule: 2 seconds maximum worked better than 30 seconds because the longer window fell into the 0.033 Hz drift region.
31.4 Key Takeaway
This section: Key Takeaway — Single sensors have inherent limitations that only multi-sensor fusion can overcome.
Single sensors have inherent limitations that only multi-sensor fusion can overcome. The Kalman filter is the gold standard for optimally combining noisy measurements with predictions, but start with a simpler complementary filter for prototyping. Production systems must include error handling, retry logic, range validation, and watchdog timers to achieve reliability.
31.5 Concept Check: Production RobustnessCheck your understanding: Production Robustness
This section: Concept Check: Production Robustness
31.6 Perspectives: Who Uses This and How?
This section: Perspectives: Who Uses This and How?
31.6.1 Sensor Fusion in Classes
In Physics class, you’ve learned about measurement uncertainty. 1/f noise is what happens when that uncertainty isn’t random---it wanders systematically over time. The Kalman filter is essentially optimal Bayesian inference: updating your belief (prediction) based on new evidence (measurement).
In Math class, the Kalman filter uses matrices (for multi-dimensional systems) and statistics (covariance, variance). The core equation is just weighted averaging where weights depend on uncertainties.
For your projects: Start with a complementary filter for your science fair IMU project---it’s simpler and works great for tilt sensing. Save Kalman filters for when you need to fuse 3+ sensors or track complex motion.
College prep tip: Understanding sensor fusion will give you a head start in robotics, aerospace, or mechatronics programs. This is the math behind self-driving cars and drone navigation!
31.6.2 Theory Behind the Practice
Mathematical foundations:
The Kalman filter is the optimal linear estimator for systems with: Start by linear state transition: where . Finally linear observation: where .
The optimality is in the minimum mean squared error (MMSE) sense. For non-linear systems, the Extended Kalman Filter (EKF) linearizes around the current estimate, while the Unscented Kalman Filter (UKF) uses sigma points to capture non-linear transformations more accurately.
Research directions:
Start by particle filters for non-Gaussian, non-linear systems. Then factor graphs and SLAM (Simultaneous Localization and Mapping). Next neural network-based sensor fusion (learned Kalman gains). Finally information-theoretic approaches to sensor selection.
Key papers:
Start by kalman, R.E. (1960). “A New Approach to Linear Filtering and Prediction Problems”. Then julier & Uhlmann (1997). “Unscented Kalman Filter” (UKF introduction). Finally madgwick (2011). “An efficient orientation filter for inertial and inertial/magnetic sensor arrays” (IEEE ICORR 2011, widely used in drones).
1/f noise theory: Also called “flicker noise,” 1/f noise appears in systems with many timescales (e.g., charge trapping in semiconductors). The Allan variance is the standard tool for characterizing noise types: white noise slopes at -1/2, 1/f noise is flat, random walk slopes at +1/2.
31.6.3 Field Implementation Tips
Common production pitfalls we’ve seen:
- Trusting datasheet specs: Lab specifications do not prove field accuracy; test the installed sensor across the expected temperature, contamination, and ageing range.
- Ignoring sensor warm-up: Many sensors (gas, optical, thermal) need 30+ seconds to stabilize. Reading immediately gives garbage.
- Forgetting cable effects: Long cables add capacitance (affects analog signals) and resistance (affects current loops). Use shielded cables and 4-20mA for runs >10m.
- No self-test capability: Build in ways to verify sensors are working. The accelerometer’s built-in self-test is a model---stimulate the sensor electrically and verify response.
Tool recommendations:
- Allan deviation analysis: Use this to characterize your sensor’s noise profile and find the optimal averaging time.
- Sensor fusion libraries: Use battle-tested code like
MadgwickorMahonyfor IMU fusion instead of rolling your own. - Edge computation: Run Kalman filters on ESP32/STM32 locally; don’t send raw data to cloud for fusion.
Vendor selection criteria:
Start by asking whether the datasheet specifies the 1/f corner frequency, which is a good sign of engineering rigour. Then check whether there is a built-in self-test for field diagnostics. Finally, record the MTBF and warranty, and reject sensors rated only for laboratory use when the deployment requires field reliability.
31.6.4 Executive Brief: Strategic Implications
Business case for sensor fusion:
- Accuracy from existing sensors: Fusion can improve an estimate when signals are complementary and the full measurement chain is validated; compare cost and accuracy for the specific design.
- Graceful degradation: Fused systems continue operating (with reduced accuracy) when individual sensors fail. This reduces costly downtime and emergency maintenance.
- Competitive differentiation: “AI-powered sensing” (which is often just well-implemented Kalman filtering) commands premium pricing.
ROI considerations:
Start by recognizing that fusion may add MCU cost while reducing the number or cost of separate sensors. Then self-diagnostics can help reduce field service calls when faults are detected and handled correctly. Finally, predictive maintenance using sensor health monitoring may extend equipment life when maintenance actions address the detected wear.
Risk factors:
Start by sensor fusion complexity requires skilled engineering talent. Then poorly tuned fusion performs worse than single sensors. Finally regulatory approval (medical, automotive) requires explainable algorithms---black-box ML fusion may not qualify.
Bottom line: Invest in sensor fusion capabilities. It’s a competitive moat that’s hard to copy and provides measurable accuracy and reliability improvements.
31.7 For Kids: Meet the Sensor Squad!
This section: For Kids: Meet the Sensor Squad! — Temperature Terry had a tricky problem: the longer he averaged his readings, the less the averaging helped!
Temperature Terry had a tricky problem: the longer he averaged his readings, the less the averaging helped! “That is 1/f noise,” explained the microcontroller. “It is like pink noise — the longer you wait, the more your baseline wanders.”
But Max had a secret weapon: sensor fusion! “Instead of relying on just one friend, I ask MULTIPLE friends and combine their answers.” Max asked the GPS for position, the accelerometer for movement, and the barometer for altitude. “Each friend has weaknesses, but together they are stronger!”
the LED was fascinated by the Kalman filter. “It is like a smart guesser! First it predicts where you SHOULD be based on how you were moving, then it checks what the sensors ACTUALLY say, and it blends the two together — trusting whichever one is more reliable at that moment!”
the battery added: “And in a real product, we always have a watchdog timer — like a guard dog that barks if the system freezes. If Max stops responding for too long, the watchdog reboots everything automatically!”
31.8 Knowledge Check: Noise and Filter TrustCheck your understanding: Noise and Filter Trust
This section: Knowledge Check: Noise and Filter Trust
31.9 Label the Diagram
This section: Label the Diagram
31.10 Code Challenge
This section: Code Challenge
Common Pitfalls
This section: Common Pitfalls
31.10.1 1. MEMS Shock Damage
MEMS sensors contain delicate micromachined structures that can be permanently damaged by mechanical shock exceeding their rated g-limit. Dropping a PCB with a MEMS gyroscope can instantly destroy the sensor. Check the datasheet shock rating and use shock-absorbing mounting in vibration-prone environments.
31.10.2 Electrochemical Cross-Sensitivity
Electrochemical gas sensors respond to their target gas but also to other species undergoing similar reactions. A CO sensor may also respond to hydrogen and ethanol. Always check the cross-sensitivity table and account for potential interferents in the deployment environment.
31.10.3 3. ToF Sensor Failure on Dark Surfaces
Time-of-flight sensors depend on reflected light returning to the detector. Highly absorptive surfaces (matte black, carbon fiber) absorb most laser energy, causing range measurements to fail or read maximum distance. Test sensor performance on actual target surfaces before finalizing the design.
31.10.4 Load Cell Mechanical Stops
Load cells have a rated capacity and a maximum safe overload; the Omega LCCD/LCMCD series, for example, specifies safe overload at 150% of rated capacity. Dynamic impacts or user misuse exceeding this permanently deforms the elastic element and changes sensitivity. Include a mechanical stop where needed, sizing its maximum force below the selected load cell’s safe overload limit with a margin for dynamic impacts.
31.12 You Might Also Like
This section: You Might Also Like
Based on the topics covered in this chapter, you may find these related chapters valuable:
| If you enjoyed… | Then explore… | Why? |
|---|---|---|
| 1/f Noise & Signal Processing | Signal Processing & Filtering | Deeper dive into filtering techniques and noise characterization |
| Sensor Fusion | Mobile Sensor APIs | See sensor fusion in action for activity tracking and mobile sensing |
| Kalman Filtering | Signal Processing Essentials | Foundational signal processing concepts behind Kalman filtering |
| Production Systems | Sensor Selection Guide | Choosing the right sensors for reliable production deployments |
| IMU & Motion Sensing | Common Sensors in IoT | Details on accelerometers, gyroscopes, and other motion sensors |
Find help
3 reviewed answers.
Where should I start in a module?
Open the module page from the sidebar to see its chapters in order. Use the module map to return to a topic you need.
Modules and pathsReviewed
What can I try when a project does not work?
Check the symptom, then work through the diagnostic steps. Keep the error message and the smallest example that reproduces it.
When you are stuckReviewed
How do interactive examples work?
Use the interactive guide to check how examples and simulations work before changing your project.
Interactive examples guideReviewed