13 Sensor Circuits: Bridges and Noise
More
Depth: Practitioner
Progress saves as you read. Mark sections complete as you go; your progress appears in the sidebar.
13.1 Start With the Situation
This section: Start With the Situation — A conditioned voltage has been adjusted so the input can read it.
A conditioned voltage has been adjusted so the input can read it. A bridge sensor turns small resistance changes into a small voltage. Gain makes that voltage larger; noise is an unwanted change in it. Long field wiring can expose small errors. The team must calculate gain, trace noise and ground-reference and return paths, and decide where analog conditioning should end.
13.2 Overview
This section: Overview — This route develops bridge interfaces and follows their noise and grounding risks into a sensor choice.
This route develops bridge interfaces and follows their noise and grounding risks into a sensor choice.
This is part 2 of 2. Review Sensor Circuits: Conditioning and Filters when you need the first route.
13.3 Learning Objectives
This section: Learning Objectives
By the end of this chapter, you will be able to:
- calculate load-cell bridge amplification
- identify sensor circuit noise and ground loops
- compare analog and digital sensor boundaries
Scenario: A load cell for a beehive monitoring system uses a Wheatstone bridge with strain gauges. The bridge outputs only 2mV/V at full scale (50kg). You need to interface this with an Arduino Uno’s 10-bit ADC.
Before calculating load-cell gain, inspect Figure 13.5 to connect the bridge’s millivolt output to its mechanical source. Mounting, preload, wiring, and cable strain can change the evidence before any amplifier or ADC sees it.

A metal bar load cell removed from a digital weighing scale with its signal cable attached
Read Figure 13.5, start with the metal sensing beam and its mounting holes, then follow the attached cable toward the bridge excitation and differential output leads. That physical path explains why the HX711 calculation below sets electronic resolution but cannot remove mechanical installation error or drift.
Given:
- Load cell sensitivity: 2mV/V (with 5V excitation = 10mV full scale at 50kg)
- Bridge output at 0kg: 0mV (ideally balanced)
- Arduino ADC: 10-bit, 5V reference
- Required accuracy: Better than 100g resolution
Steps:
-
Calculate signal range:
- At 50kg: 2mV/V x 5V = 10mV
- At 0kg: 0mV
- Signal range: 0-10mV
-
Determine minimum required gain:
- Arduino LSB: 5V / 1024 = 4.88mV
- To detect 100g (0.2% of 50kg): need 0.002 x 10mV = 0.02mV resolution
- Required gain to make 0.02mV visible: 4.88mV / 0.02mV = 244x minimum
- Use gain of 500x for safety margin
-
Select a bridge ADC: HX711 (dedicated load-cell amplifier and ADC)
- Built-in 128x gain option
- 24-bit ADC (much better than Arduino’s 10-bit)
- Includes filtering and offset compensation
-
Check the HX711 range and nominal codes:
- At 5 V analog supply and gain 128, channel A accepts approximately ±20 mV differential input; the assumed 0–10 mV load-cell output fits.
- Its signed 24-bit output has 2^23 positive codes over the 0–20 mV positive half-range. The 10 mV load-cell span uses about 2^22 nominal codes.
- Ideal weight per code over 0–50 kg: 50 kg / 4,194,304 ≈ 0.012 g/code. This is a code-size calculation, not a measured resolution or accuracy specification.
Result: The nominal code size is far smaller than 100 g, but noise-free resolution, repeatability, and accuracy must be measured with the actual bridge, mounting, excitation, and calibration weights. A 24-bit word does not guarantee 24 useful bits.
Key Insight: For precision measurements like load cells, dedicated signal conditioning ICs (HX711, ADS1231) outperform general-purpose solutions. They combine optimized gain, filtering, and high-resolution ADC in a single chip designed for the specific application.
This section:
 Checkpoint: Worked Interfaces
- A 20mV thermistor span can use almost the full ADC range after amplification.
- A 2mV/V load cell with 5V excitation produces only 10mV at 50kg.
- HX711 combines 128x gain, filtering, and a 24-bit ADC for bridge measurements.
13.4 Signal Conditioning Circuit Detail
This section: Signal Conditioning Circuit Detail — The earlier pipeline named functions; Figure 13.1 shows how analogue circuit stages implement them before the ADC.
The earlier pipeline named functions; Figure 13.1 shows how analogue circuit stages implement them before the ADC. Read from the instrumentation amplifier through the filter and level-shift stages, checking what each block changes and what it must preserve.
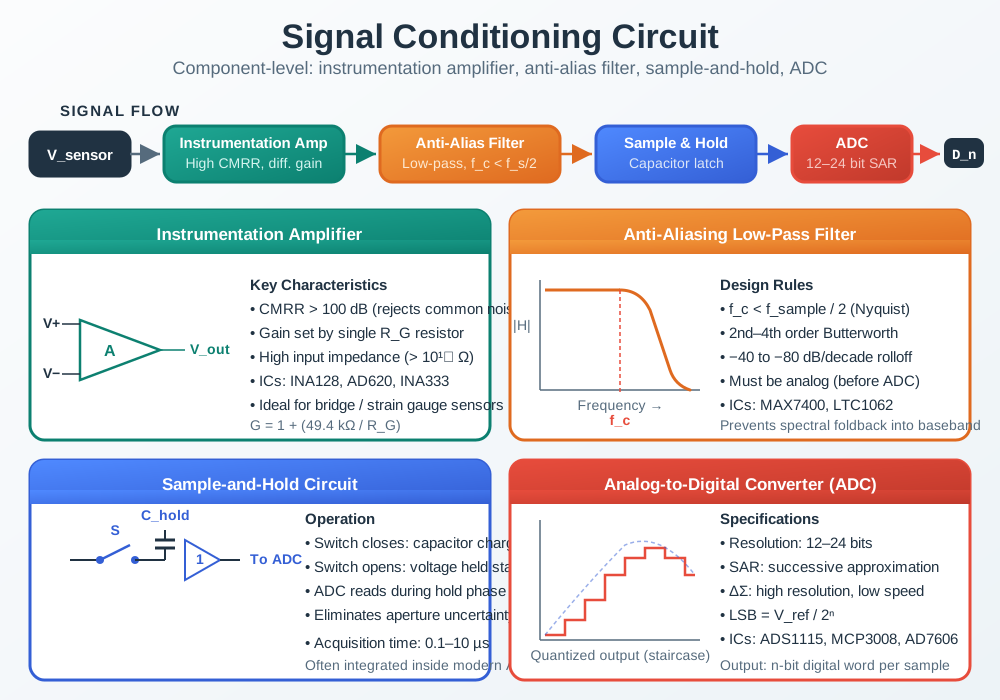
A sensor signal passes through an instrumentation amplifier, anti-alias filter, sample-and-hold and ADC. Component panels explain gain, cutoff, held voltage and quantized output.
In Figure 13.1, amplification raises the differential signal while rejecting common-mode content, filtering limits unwanted bandwidth, and level shifting places the result inside the ADC input range. The order matters: a clipped amplifier output or overloaded ADC cannot be repaired by downstream processing. This circuit view turns the chapter’s gain, cutoff, and range calculations into one interface contract.
Now step outward with Figure 13.2. Follow the diagram from the physical phenomenon through transduction and conditioning to data processing, and locate the detailed circuit at the conditioning stage rather than mistaking it for the whole measurement system.
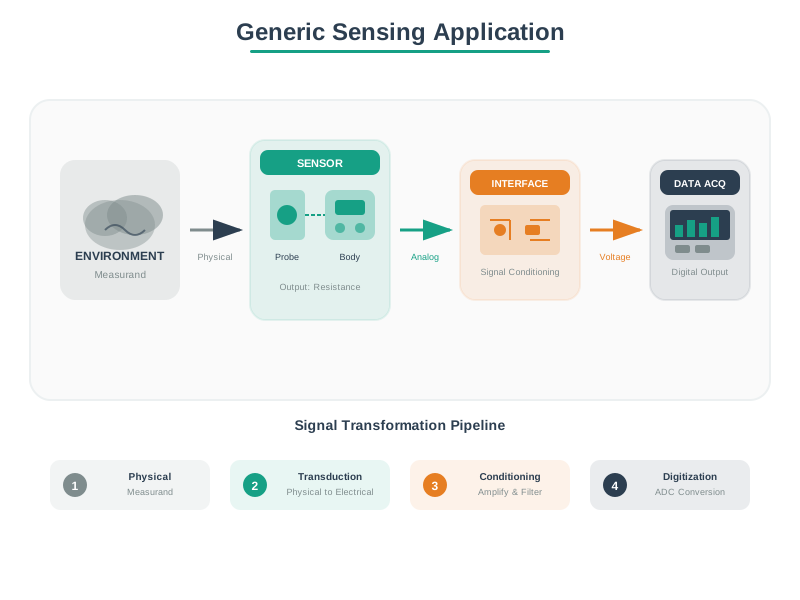
Geometric block diagram of complete sensing system showing physical phenomenon input, sensing element transduction, signal conditioning with amplification and filtering, and output to data processing unit for IoT sensor integration
Read Figure 13.2 left to right. The sensing element first converts the phenomenon into an electrical quantity; conditioning makes that quantity compatible with conversion; data processing then scales, checks, or acts on the result. Every stage can add limits, so the detailed circuit earns its place only when its output preserves the physical change the application needs to distinguish.
13.5 Noise Sources and Mitigation
This section: Noise Sources and Mitigation — Understanding where noise enters the signal path helps design effective mitigation strategies.
Understanding where noise enters the signal path helps design effective mitigation strategies.
Before choosing a filter or averaging interval, inspect Figure 13.3 to diagnose the disturbance by source and frequency behaviour. Mitigation works best when it targets the coupling mechanism rather than merely smoothing every sample.
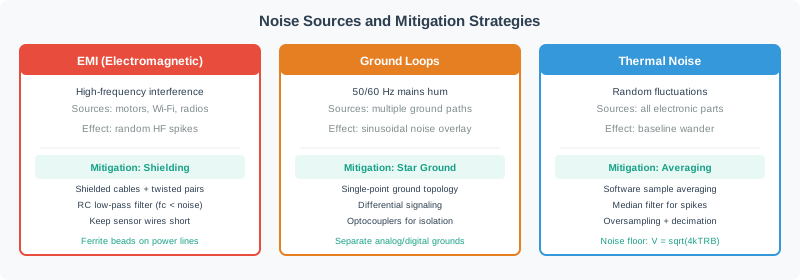
Noise sources and mitigation strategies diagram showing EMI high-frequency interference mitigated with shielding, ground loops causing 50/60Hz hum mitigated with star grounding, and thermal noise mitigated with sample averaging.
Read Figure 13.3, compare the high-frequency interference path with the mains-frequency ground-loop path, then note the unavoidable thermal-noise floor. Shielding, grounding, hardware filtering, and averaging address different mechanisms, carrying the chapter from noise symptoms to defensible countermeasures.
Core Concept: Sensor signals are corrupted by three main noise sources - EMI (high-frequency interference from motors/radios), ground loops (50/60Hz hum from multiple ground connections), and thermal noise (random fluctuations inherent to all electronic components). Why It Matters: In industrial IoT deployments, unmitigated noise can produce large ADC reading variations, causing false alarms, missed events, and unreliable control loops that waste energy or create safety hazards. Key Takeaway: Apply a two-stage defense - use hardware filtering (RC low-pass with cutoff above your signal frequency but below noise) to remove high-frequency EMI, then apply software median filtering to reject impulse spikes before averaging for thermal noise reduction.
13.6 Analog vs Digital Sensor Tradeoff
This section: Analog vs Digital Sensor Tradeoff
Decision context: When selecting sensors for a new IoT design, choosing between raw analog sensors with custom signal conditioning versus integrated digital sensors with built-in ADC.
| Factor | Analog Signal Chain | Digital Sensor (I2C/SPI) |
|---|---|---|
| Power | Lower sensor power; conditioning circuit adds 1-10mA | Higher sensor power (built-in ADC, processor); 0.1-5mA typical |
| Cost | Lower sensor cost ($0.10-$5); conditioning adds $1-$10 | Higher sensor cost ($2-$30); minimal external components |
| Accuracy | Customizable; can optimize for specific application | Fixed by manufacturer; often excellent out-of-box |
| Flexibility | Full control over gain, filtering, sampling rate | Limited to manufacturer’s configuration options |
| Development Time | Longer (circuit design, PCB layout, calibration) | Shorter (library exists, drop-in replacement) |
| Noise Immunity | Susceptible to EMI on analog traces | Digital signals resistant to noise; shielded internal ADC |
| Board Space | Larger (op-amps, capacitors, resistors) | Smaller (single IC, minimal passives) |
Choose Analog Signal Chain when:
Choose an analog signal chain when you need custom gain or filtering, need the lowest component cost at high volume (10,000+ units), require a non-standard sampling rate or resolution, or can obtain the sensor only with analog output.
Choose Digital Sensor when:
Choose a digital sensor when development speed, calibrated measurements, compact board space, noise resilience, or simpler multi-sensor wiring is the stronger requirement.
Default recommendation: Digital sensors (I2C/SPI) for most IoT projects unless you have specific signal conditioning requirements that cannot be met by available digital sensors, or you are optimizing BOM cost at scale.
This section:
Checkpoint: Noise and Sensor Choice
- Industrial noise can add substantial full-scale variation, depending on the installation.
- Ground loops can inject interference; twisted pairs can reduce pickup when used with a suitable receiver.
- Digital I2C/SPI sensors simplify design, while analog chains keep custom gain, filtering, and sampling control.
13.7 Ground Loop Pitfall
This section: Ground Loop Pitfall
The Mistake: Connecting sensor returns to the measurement ground at multiple points, creating a closed return path that can carry 50/60Hz mains hum and motor noise into sensor readings.
Why It Happens: A second connection between ground points closes a loop; voltage differences then drive circulating current that can couple noise into analog measurements.
The Fix: Implement star-ground topology:
- Single ground point: All sensor grounds connect to ONE central point near the ADC.
- Ground plane: Use a copper pour on PCB as low-impedance ground reference.
- Twisted pairs: Run signal and ground wires twisted together (3-4 twists per inch).
- Differential measurement: Use instrumentation amplifiers (INA128, AD620) for long cable runs.
Specific values:
Start by Ground loop voltage can reach 10-100mV in industrial environments. Then On 12-bit ADC (0.8mV/step), this adds +/-125 counts of noise. Next Twisted pair reduces magnetic pickup by 20-40 dB. Finally Adding 100nF ceramic capacitor from signal to ground at ADC input provides additional filtering.
13.8 Voltage Divider and Bridge Circuits
This section: Voltage Divider and Bridge Circuits — The Wheatstone bridge (covered above) and simple voltage dividers are the two fundamental resistive sensor interface circuits.
The Wheatstone bridge (covered above) and simple voltage dividers are the two fundamental resistive sensor interface circuits. The voltage divider provides a simple output proportional to resistance ratio, while the bridge offers differential measurement with superior noise rejection.
Before reusing a divider at the ADC boundary, inspect Figure 13.4 to identify the source, resistor ratio, output node, and loading assumptions.
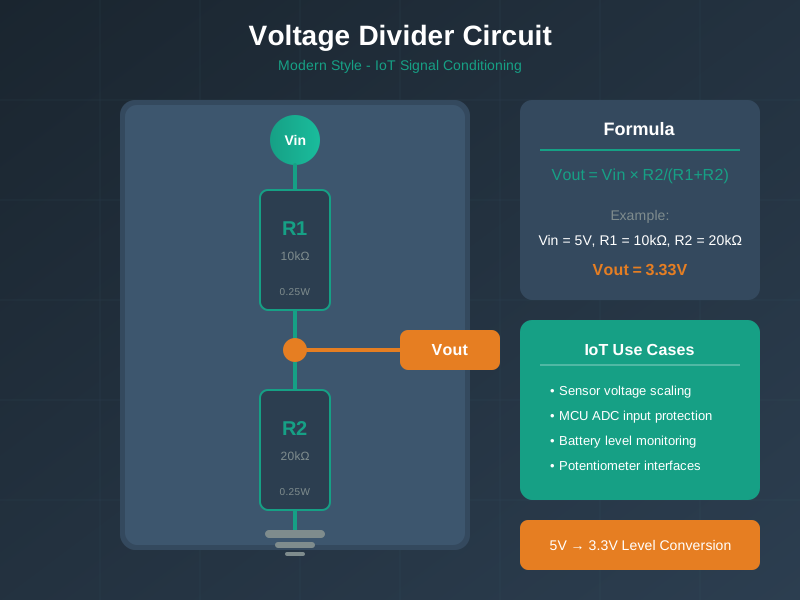
Voltage divider circuit with two resistors in series, an output tap, and the formula for scaling a sensor voltage before ADC measurement.
Read Figure 13.4 from the input through both series resistors to the midpoint voltage. The output is taken across the lower resistor, so its share of the source follows the lower resistance divided by the series total. That ratio explains the intended scaling, but the drawing also exposes the node that the ADC loads. Source impedance and acquisition current therefore connect this simple circuit to the buffering and settling checks discussed in the chapter.
Voltage divider circuit for resistive sensor interfaces
This section:
Signal conditioning is the difference between garbage data and precision measurement. Raw sensor signals are almost never suitable for direct ADC connection — they need amplification (to use the full ADC range), filtering (to remove electrical noise), and level shifting (to match voltage requirements). For precision applications like load cells and strain gauges, dedicated signal conditioning ICs (HX711, INA128) outperform general-purpose circuits by combining optimized amplification, filtering, and high-resolution ADC in a single chip.
This section:
This section:
Temperature Terry was working in a factory, trying to measure the weight of honey jars on a conveyor belt. But there was a problem…
“My strain gauge signal is only 1.25 millivolts!” Sammy cried. “That’s like trying to hear a mouse whisper in a thunderstorm!”
the microcontroller couldn’t read it. “Sorry Sammy, my ADC needs at least a few hundred millivolts to see anything useful. Your signal is just lost in the noise.”
the LED had an idea. “What if we use a WHEATSTONE BRIDGE? It’s like a perfectly balanced seesaw. When no weight is on the scale, everything is balanced and the output is zero. But when a honey jar sits on it, the tiny change in the strain gauge tips the seesaw just a little bit!”
“But 1.25 millivolts is still too quiet!” Max protested.
“That’s where the AMPLIFIER comes in!” said the battery. “Think of it like this: the Wheatstone bridge whispers the weight reading, the amplifier is a super-powered hearing aid that makes the whisper 500 times louder! Now that 1.25 millivolt whisper becomes a nice, clear 625 millivolt shout!”
“And before the signal reaches me,” Max added, “it passes through a FILTER that removes all the buzzing from the factory motors. It’s like noise-canceling headphones for electrical signals!”
Sammy was amazed. “So the signal conditioning chain is: Bridge detects tiny change, Amplifier makes it louder, Filter cleans up the noise, then Max can read it perfectly?”
“Exactly! And with a special chip called the HX711, all of this happens in one tiny package. In our 50 kg example, one ADC code is about 0.012 grams, though real noise and the load cell limit practical resolution.”
“Signal conditioning really is a superpower!” Sammy beamed.
This section:
The Mistake: An industrial vibration monitoring system samples an accelerometer at 1 kHz (1000 samples/second) without any anti-aliasing filter between the sensor output and the ADC input. The system is supposed to detect bearing faults by analyzing vibration frequencies up to 400 Hz. During testing, engineers observe mysterious “ghost frequencies” around 150 Hz that don’t correspond to any actual mechanical vibration.
Why It Happens: The Nyquist-Shannon theorem states that you can only accurately represent frequencies up to half your sampling rate (called the Nyquist frequency). For 1 kHz sampling, the Nyquist frequency is 500 Hz. Any frequency components above 500 Hz in the input signal will “alias” — appear as false lower frequencies in the digitized data.
Real Example:
- Sampling rate: 1000 Hz → Nyquist frequency: 500 Hz
- Actual vibration at 650 Hz (above Nyquist)
- Aliased frequency: |650 - 1000| = 350 Hz (false signal!)
- This 350 Hz “ghost” corrupts your analysis
Aliasing Rule of Thumb: any input frequency above half the sampling rate folds back into the measured data as a false lower frequency.
With 1 kHz sampling:
- A real 650 Hz vibration can appear as a false 350 Hz signal.
- A real 1200 Hz vibration can appear as a false 200 Hz signal.
- A real 2800 Hz vibration can also appear as a false 200 Hz signal, which means two different physical problems can look identical after sampling.
Why It’s Dangerous:
- You can’t distinguish real from aliased signals in the digital data
- Multiple high frequencies can alias to the same low frequency (collision)
- Filtering after ADC doesn’t help — damage is already done
The Fix: Add an anti-aliasing filter (analog low-pass filter) BEFORE the ADC:
Design Steps:
- Determine maximum frequency of interest: 400 Hz (bearing fault signatures)
- Choose sampling rate: 1000 Hz (2.5× maximum frequency, provides margin)
- Calculate filter cutoff frequency:
- Nyquist frequency: 500 Hz
- Anti-aliasing filter cutoff: 450 Hz (between max interest and Nyquist)
- Filter type: 2nd-order Butterworth for flat passband
- Implement RC filter: Design a second-order Sallen–Key Butterworth stage for about 450 Hz with Q=1/√2. Equal 10 kΩ resistors and 33 nF capacitors alone give a 482 Hz pole frequency; choose the amplifier gain or component ratios needed for Butterworth Q, then check passband gain, ADC headroom, and the measured cutoff.
Filter Performance (2nd-order Butterworth, fc = 450 Hz):
- At 400 Hz (max interest): -2.1 dB (78% of signal passes)
- At 450 Hz (cutoff): -3.0 dB (71% of signal)
- At 650 Hz (alias example): -7.3 dB (43% of signal)
- At 1000 Hz: -14 dB (20% of signal)
Note: The -2.1 dB attenuation at 400 Hz is a tradeoff inherent to placing the cutoff close to the maximum frequency of interest. If signal preservation near 400 Hz is critical, increase the cutoff to 480 Hz (at the cost of less alias rejection), or use a higher-order filter (4th-order Butterworth gives about -1.43 dB at 400 Hz with the same 450 Hz cutoff).
Key Specifications:
| Parameter | Value | Purpose |
|---|---|---|
| Passband | 0-400 Hz | Preserve vibration signals of interest |
| Transition band | 400-500 Hz | Gradual rolloff (steeper = more complex filter) |
| Stopband | 500+ Hz | Attenuate frequencies above Nyquist |
| Stopband roll-off | ≈12 dB/octave asymptotically | Choose filter order and sample rate for the required alias rejection. |
| Attenuation at 500 Hz Nyquist | ≈4.0 dB (2nd order); ≈5.2 dB (4th order) | Neither supplies 40 dB; set the alias-rejection target before choosing the filter. |
Real-World Impact:
| Scenario | Without Anti-Aliasing | With Anti-Aliasing Filter |
|---|---|---|
| True 350 Hz fault | Reads 350 Hz (correct) | Reads 350 Hz (preserved) |
| 650 Hz harmonic | Aliases to 350 Hz (false positive) | Attenuated -7 dB with 2nd-order filter; use 4th-order for better rejection |
| EMI at 50 kHz | Aliases to multiple low freqs (noise) | Attenuated >60 dB |
Industry Best Practices:
- Sample at 2.5-5× your highest frequency of interest (not just 2×)
- Anti-aliasing filter cutoff at 0.4-0.45× sampling rate
- Use at least 2nd-order filter (4th-order for critical applications)
- Verify with spectrum analyzer before deployment
- Document filter specs in technical documentation
Quick Test: To verify your anti-aliasing filter is working, inject a known high-frequency signal (e.g., 800 Hz sine wave) into your system. If it correctly shows up as highly attenuated (or doesn’t appear at all) in your ADC data, your filter is working. If you see it aliased to a low frequency with significant amplitude, your filter is inadequate.
Cost-Benefit: A low-cost RC filter can reduce false alarms that could trigger unnecessary maintenance or hide real faults. Anti-aliasing is mandatory for any system that processes signals with unknown high-frequency content.
This section:
Checkpoint: Anti-Aliasing
- Sampling at 1 kHz gives a 500 Hz Nyquist frequency.
- A 650 Hz vibration can appear as 350 Hz; 1200 Hz and 2800 Hz can both appear as 200 Hz.
- Filter before the ADC, because filtering after sampling cannot remove aliases.
13.9 Practice CheckCheck your understanding: Practice Check
This section: Practice Check
13.10 Concept Relationships
This section: Concept Relationships
| This Concept | Relates To | Relationship Type |
|---|---|---|
| Instrumentation Amplifier | Wheatstone Bridge | Amplifies differential voltage from bridge output |
| Gain Calculation | ADC Range | Formula maps sensor output to full ADC span |
| Anti-Aliasing Filter | Nyquist Theorem | Attenuates frequencies above fs/2 enough to meet the application’s alias-error limit |
| Common-Mode Rejection | Noise Immunity | CMRR rejects interference present on both inputs |
| Ground Loops | Noise Source | Single-point grounding prevents circulating currents |
13.11 Bridge Linearity and Amplifiers
This section: Bridge Linearity and Amplifiers — The worked examples above show where bridge and amplifier blocks sit in a signal-conditioning chain.
The worked examples above show where bridge and amplifier blocks sit in a signal-conditioning chain. Continue to Bridge Linearity and Instrumentation Amplifiers when the sensing element is a strain gauge, load cell, pressure bridge, or other millivolt differential source. That page separates the practical sizing details from this overview: bridge baseline cancellation, quarter-bridge gain calculations, instrumentation-amplifier common-mode rejection, and thermal dummy-gauge cancellation.
13.12 Summary
This section: Summary
This chapter covered signal conditioning essentials:
- Signal Processing Pipeline: Six stages from physical phenomenon to digital output.
- Wheatstone Bridge: Precision measurement of small resistance changes using differential voltage.
- Gain Calculation: Match sensor output range to ADC input range for maximum resolution.
- Instrumentation Amplifiers: High CMRR, adjustable gain, designed for bridge circuits.
- Noise Mitigation: Hardware filtering, grounding practices, and software averaging.
- Design Tradeoffs: Analog flexibility vs digital simplicity based on project requirements.
13.13 See Also
This section: See Also
- Sensor Circuit Fundamentals - Voltage dividers, RC filters, basic building blocks.
- Electronics Fundamentals - Op-amp theory, semiconductor devices.
- Analog and Digital Electronics - ADC/DAC conversion theory.
- Sensor Interfacing - I2C, SPI communication protocols.
- Signal Processing Essentials - DSP algorithms.
Common Pitfalls
This section: Common Pitfalls
Most standard op-amps cannot swing their output all the way to the supply voltage — they saturate 1-2 V below the rail. For 3.3 V single-supply designs, use a rail-to-rail op-amp (e.g., MCP6001) to avoid clipping the conditioned signal before it reaches the ADC.
Setting excessive amplifier gain causes the ADC to clip when the sensor produces large outputs. Calculate the maximum sensor output, multiply by the gain, and confirm the result fits within 90% of the ADC reference voltage to leave headroom for noise and signal peaks.
Long unguarded analog traces running next to digital clock lines pick up switching noise through capacitive coupling. Keep analog signal traces short, route them away from high-frequency digital lines, and add a ground guard trace alongside sensitive analog paths.
Bridge sensitivity scales with excitation voltage, but higher voltage increases self-heating in the sensing resistor, changing its resistance and introducing error. Use the manufacturer’s recommended excitation voltage and avoid increasing it to improve sensitivity.
13.14 What’s Next
This section: What’s Next
Find help
3 reviewed answers.
Where should I start in a module?
Open the module page from the sidebar to see its chapters in order. Use the module map to return to a topic you need.
Modules and pathsReviewed
What can I try when a project does not work?
Check the symptom, then work through the diagnostic steps. Keep the error message and the smallest example that reproduces it.
When you are stuckReviewed
How do interactive examples work?
Use the interactive guide to check how examples and simulations work before changing your project.
Interactive examples guideReviewed