26 Sensor Power: Accuracy and Field Hardening
More
Depth: Practitioner
Progress saves as you read. Mark sections complete as you go; your progress appears in the sidebar.
26.1 Start With the Decision
This section: Start With the Decision — A lab prototype wakes on cue, but a cold field unit misses interrupts and reports stale values.
A lab prototype wakes on cue, but a cold field unit misses interrupts and reports stale values. Wake sources, conversion timing, and error flags must survive the real site.
26.2 Route Overview
This section: Route Overview — This is part 3 of 3.
This is part 3 of 3. Review Low-Power Sensors: Duty Cycles and Fusion for the preceding evidence.
26.3 Learning Objectives
This section: Learning Objectives
- Configure wake sources and data-ready timing before deep sleep.
- Test power estimates against accuracy, temperature, and field failures.
26.4 Chapter Roadmap
This section: Chapter Roadmap
- Power Accuracy and Field Hardening
- Summary
- What’s Next
- Related Chapters
26.5 Power Accuracy and Field Hardening
This section: Power Accuracy and Field Hardening
26.5.1 Start With the Measurement Story
26.5.1.1 Make the Reading Survive the Site
Firmware is the software stored inside a device. Latency is the time between an event and the result that depends on it.
Picture a water-level sensor on a cold, wet pump site. It reads well on the bench. In the field, cable strain, weak battery power, moisture, and a slow network can turn one fault into a believable but wrong value.
Build a threat list before choosing protection. Include the coldest start, the lowest useful battery level, vibration, water entry, dirty connectors, blocked vents, and lost communication. For each threat, name the expected sign, the limit for safe use, and the fallback. Keep raw reading, time, unit, quality flag, and device identity together.
Then run the checks in combinations, not only one at a time. A cold battery during retries may fail where either test alone passes. This review does not prove all future weather or ageing. It defines the tested envelope. The deeper sections show how calibration, power design, filtering, enclosure choices, and maintenance evidence support that boundary.
A field sensor has to be accurate after vibration, moisture, temperature swings, and low battery states. The design starts by naming the threats and deciding which protection, calibration, and evidence checks keep the reading usable.
The mathematical gist. With fixed-resistor excitation, current follows battery voltage and self-heating follows its square: . Drooping from the chapter’s 3.6 V fresh rail to 3.0 V gives , so a 0.10 °C fresh-cell rise becomes 0.0694 °C. But the excitation signal also falls to 83.3%, so the smaller thermal error can hide worsening resolution.

26.5.2 Learning Objectives
After this page, you should be able to:
- Explain how self-heating and settling delay can make low-power readings inaccurate.
- Calculate when excitation current violates a temperature sensor’s self-heating error budget.
- Configure wake-source and adaptive-sampling patterns without hiding recovery costs.
- Build a field-hardening checklist for radio bursts, peripherals, wake latency, and battery behavior.
26.5.3 Why This Follows the Main Power Chapter
Low-Power Sensor Networks builds the normal wake-read-transmit-sleep cycle. This page tests the cycle against the failure modes that appear after deployment: the sensor warms itself, conversion timing changes the reading, firmware sleeps without a recovery path, or adaptive sampling saves energy while losing important events.
26.5.4 Saving Power Can Corrupt the Measurement
Low-power sensor nodes live by duty-cycling: sleep, wake, read, sleep again. But two power-related effects sit directly between "save energy" and "get a correct reading," and both are easy to miss because the data still looks plausible.
The first is self-heating: the very current you push through a resistive sensor to read it dissipates power and warms the element, biasing a temperature reading upward. The second is warm-up and settling: a sensor that was just powered on after sleep has not yet stabilised, so an eager reading taken too soon is wrong. Both are trade-offs of energy against accuracy.
A practical power plan therefore starts with a measurement-quality budget, not just a battery-life target. For a thermistor node, for example, the designer chooses the excitation current, the on-time, the settling delay, and the radio schedule together. Reducing current may improve battery life but lower ADC signal-to-noise ratio; increasing current may clean up the code but heat the sensing element; shortening the delay may save milliseconds but sample a filter that is still moving.
The field symptom is subtle: the node seems reliable because it wakes on schedule and uploads data, yet its readings shift with sample rate, enclosure airflow, or firmware changes. When changing a power setting changes the measured value, the measurement chain is part of the power design. Treat each wake cycle as a small experiment: energise the sensor, wait for the documented condition, convert, verify the result is within range, transmit only when needed, and then sleep. If the number changes after only the sleep interval changes, investigate timing before recalibrating the sensor.
Intuition: a thermistor is a tiny heater as well as a thermometer. Read it gently and briefly and it reports the world; read it hard and continuously and it partly reports itself.
Overview Knowledge Check
26.5.5 Self-Heating Math and Excitation Budget
The temperature error from self-heating is the dissipated power divided by the sensor's dissipation constant (a datasheet figure in milliwatts per degree):
Power dissipated:  P = I^2 × R
Self-heat error:   ΔT = P / δ
δ = dissipation constant (mW per °C), from the datasheet
Worked example: why doubling the current is not free
Thermistor, dissipation constant δ = 2 mW/°C (still air).

Read with sense power P = 0.2 mW:
  ΔT = 0.2 / 2 = 0.10 °C error   (small, tolerable)

Push 2x the current for a bigger signal. Because
P = I^2 R, power rises 4x to 0.8 mW:
  ΔT = 0.8 / 2 = 0.40 °C error

Push 4x the current -> 16x power = 3.2 mW:
ΔT = 3.2 / 2 = 1.6 °C error
Signal grows with current, but self-heating error grows with current squared. That is the crux of the trade-off: cranking up excitation to improve SNR quietly poisons accuracy far faster than it helps.
Use the equation as a gate before firmware is considered done. If the error budget allows only 0.25 °C of self-heating and the dissipation constant is 2 mW/°C, the excitation budget is 0.5 mW. A 10 kΩ thermistor at that limit can carry only about 0.22 mA, because I = sqrt(P/R) = sqrt(0.0005 W / 10000 Ω). A convenient 1 mA test current would dissipate 10 mW and create about 5 °C of self-heating in the same condition.
That arithmetic explains why production firmware often pulses a divider or sensor rail through a MOSFET, discards the first sample after wake, averages only inside a bounded measurement window, and stores the actual excitation time with the reading. The goal is not the lowest instantaneous current; it is a repeatable energy packet whose thermal error, ADC noise, and settling time are all known.
The low-power win: pulse the excitation. Power the sensor only during the brief moment of measurement, so the average dissipation — and thus the steady self-heat rise — stays tiny while the instantaneous signal is strong.
Practitioner Knowledge Check
26.5.6 Warm-Up, Airflow, Accuracy
Duty-cycling introduces its own errors on top of self-heating, and they interact in ways that shape the whole power budget.
Warm-up is both an energy event and a measurement-validity interval. The average-current ledger in Figure 26.1 includes warm-up, radio use, and exception reserves that a sleep-current headline omits.
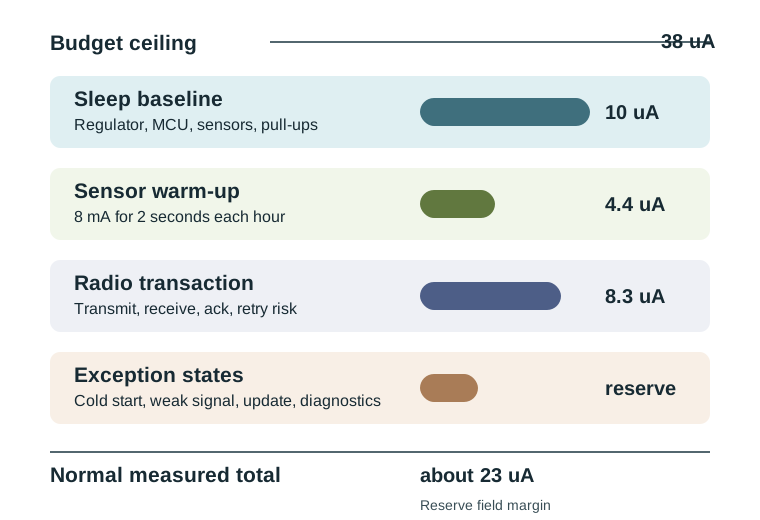
An energy ledger separates sleep, sensor warm-up, radio and exception states under a 38 µA ceiling. The normal measured total is about 23 µA, leaving field reserve margin.
Read Figure 26.1 against its Budget ceiling 38 µA: the Sleep baseline consumes 10 µA and the Sensor warm-up contributes another 4.4 µA even though the sensor draws 8 mA for only two seconds each hour. The Radio transaction adds 8.3 µA for transmit, receive, acknowledgement, and retry risk, bringing the Normal measured total to about 23 µA. Exception states—cold start, weak signal, update, and diagnostics—then occupy the remaining field margin rather than disappearing from the calculation. The ledger explains the section’s operating rule: power the sensing element long enough to settle in its real airflow and temperature environment, accept readings only after that interval, and preserve reserve for the conditions most likely to extend it.
Settling after wake
A freshly powered sensor and its filter network need time to stabilise. Electrically, a filtered node settles over several RC time constants; many sensors also quote a start-up or stabilisation time that must elapse before the reading is valid.
Thermal mass lags
A temperature sensor has physical mass, so it follows the environment with a lag. Sample too soon after a change, or too soon after wake, and you read where the world was, not where it is.
Airflow changes self-heating
The dissipation constant is smaller in still air than in moving air or liquid, so the same sense power causes a larger self-heat rise in still air. The identical sensor can read differently just because the breeze changed.
Settling dominates the energy bill
For slow sensors, the time spent waiting to settle can use more energy than the conversion itself. That creates real tension: wait longer for accuracy, or sleep sooner to save charge.
The ledger view also changes how failures are budgeted. A node that normally sleeps for 99% of the hour may still need a reserve for cold starts, low-battery retries, cloud outages, or a stuck sensor that forces extra reads. If the normal cycle already consumes the whole budget, exception paths drain the battery first and accuracy degrades next as firmware starts cutting settle time to recover.
The design that wins treats accuracy and energy as one coupled problem: pulse the excitation to limit self-heating, allow just enough settling time for the required accuracy, measure the radio burst separately from the sensor warm-up, and pick a sensor whose thermal and electrical time constants fit the duty cycle. Optimising energy while ignoring settling gives a node that lasts for years and reports numbers that were never quite right.
Under-the-Hood Knowledge Check
26.5.7 ESP32 Deep-Sleep Wake Sources
The ESP32 offers multiple wake sources for deep sleep mode (see also Common Power Pitfalls for what happens when you forget to configure one):
- Timer wake —
esp_sleep_enable_timer_wakeup(microseconds)— Most common for periodic sensing. - GPIO wake (EXT0) — Wake on single RTC GPIO pin state change (e.g., button press, PIR sensor).
- GPIO wake (EXT1) — Wake when multiple RTC GPIOs match condition (AND/OR logic).
- Touchpad wake — Wake on capacitive touch sensor activity (ESP32 has 10 touch-capable pins).
- ULP coprocessor — Ultra-low-power coprocessor can monitor sensors and wake main CPU only when thresholds are exceeded.
ESP32 power mode comparison:
| Mode | Current | What Stays On |
|---|---|---|
| Active (CPU + Wi-Fi) | 160-240 mA | Everything |
| Modem sleep | 20-40 mA | CPU active, Wi-Fi wakes at DTIM intervals |
| Light sleep | 0.8 mA typical | CPU paused, Wi-Fi suspended, RAM retained |
| Deep sleep | 10-150 uA | RTC controller + RTC memory only |
| Hibernation | 2.5-5 uA | RTC timer only (no RTC memory) |
26.5.8 Concept Check: Deep Sleep Wake Sources
26.5.9 Basic Deep Sleep
Goal: Make ESP32 read a sensor, send data, then sleep for 10 minutes.
Code structure:
#include <esp_sleep.h>

void setup() {
    // Read sensor
    float temp = readTemperature();

    // Send data (Wi-Fi or LoRa)
    sendDataToCloud(temp);

    // Configure wake timer
    esp_sleep_enable_timer_wakeup(10 * 60 * 1000000ULL); // 10 minutes in µs

    // Enter deep sleep
    esp_deep_sleep_start();
}
void loop() { /* Never runs */ }
Expected result: Current drops from 80mA active to 10µA sleep
26.5.10 Power-Aware Sensor Fusion
Goal: Combine GPS + accelerometer + barometer, but only wake GPS when movement detected.
Strategy:
- Accelerometer runs continuously (low power)
- GPS off unless accelerometer detects motion
- Barometer updates every minute
- Transmit fused data every 5 minutes
Power savings: GPS uses 40-60mA. In this movement-gated GPS design, assume motion is rare enough that running GPS only when moving saves over 80% of its active energy.
26.5.11 Variance-Based Adaptive Sampling
Goal: Sample faster when sensor values change rapidly, slower when stable.
Algorithm:
Start by calculate rolling standard deviation of last 10 readings. Then if stddev > threshold: sample every 10s. Next if stddev < threshold: sample every 60s. Finally transmit only when value changes by >5%.
Challenge: Implement this for temperature sensor with automatic adaptation
26.5.12 Try It: Adaptive Sampling Power SavingsTry: Adaptive Sampling Power Savings
26.5.13 Concept Relationships
| Core Concept | Related Concepts | Why It Matters |
|---|---|---|
| Deep Sleep | Wake Sources, RTC, ULP Coprocessor | Reduces current from mA to µA range |
| Transmission Buffering | Data Aggregation, Batch Updates | Wi-Fi/LoRa dominates power budget |
| Duty Cycling | Active %, Sleep Time, Average Power | Extends battery life proportionally |
| Sensor Fusion | Complementary Filter, Kalman Filter | Combines multiple sensors for accuracy |
Common Pitfalls
Wireless transmission (Wi-Fi, LoRa, BLE advertising) can draw far more power than a sleeping microcontroller; compare each device’s measured active and sleep currents. Profile transmit current separately and minimize transmission frequency and payload size.
Voltage regulators, pull-up resistors, and always-on LEDs all draw continuous current. Switch off peripherals using power gating transistors and remove unnecessary pull-ups on unused pins.
Some sensors require a warm-up or stabilisation period after power-on before they produce accurate readings. Factor this into duty-cycle calculations or keep critical sensors powered continuously.
Battery voltage drops nonlinearly with state-of-charge and temperature. Lithium cells lose capacity at low temperatures; alkaline cells have a steeper voltage drop curve. Test your system at expected operating temperature extremes.
26.5.14 Release Checklist
Before accepting a low-power sensing design, capture this evidence:
Start by measured sleep, sensor-warm-up, conversion, and radio currents as separate ledger entries. Then a self-heating estimate for the highest excitation current used in firmware. Next a settling-time check showing when the first valid post-wake reading is allowed. After that a configured wake source plus a development fail-safe wake path. Continue by adaptive-sampling thresholds with proof that rapid events are not skipped. Finally cold-temperature, low-battery, retry, and network-outage behavior.
26.5.15 See Also
Start by Low-Power Sensor Networks - main power-management workflow. Then Sensor Data Processing - filtering and event detection before transmission. Finally Sensor Calibration Techniques - accuracy evidence over time.
26.5.16 What’s Next
Return to Low-Power Sensor Networks for the module path, or continue to Common Sensor Mistakes to audit broader measurement failures.
26.6 Summary
This section: Summary
This chapter covered power management strategies for sensor networks:
- Multi-Sensor Aggregation: Structured data collection with JSON payloads.
- Deep Sleep Modes: Reduce consumption from milliamps to microamps.
- Power Budget Calculations: Estimate battery life for design decisions.
- Transmission Buffering: In the chapter’s Wi-Fi node model, buffering eight readings reduces transmissions by 87.5% and raises estimated battery life about 3.1×.
- Sensor Fusion Tradeoffs: Complementary vs Kalman filters, smart vs raw sensors.
- Wake Source Configuration: Critical for deep sleep recovery.
26.7 What’s Next
This section: What’s Next — The next chapter covers Sensor Applications, including smart home environmental monitoring, automated blinds control, and temperature-controlled relay systems with practical implementation examples.
The next chapter covers Sensor Applications, including smart home environmental monitoring, automated blinds control, and temperature-controlled relay systems with practical implementation examples.
- Sensor Data Processing - Filtering and calibration
- Sensor Communication Protocols - I2C, SPI interfaces
- Edge Computing - Edge processing patterns
26.8 Continue Your Route
This section: Continue Your Route — The tests for Power Accuracy and Field Hardening connect to the broader evidence routes in Related Chapters.
The tests for Power Accuracy and Field Hardening connect to the broader evidence routes in Related Chapters. Return to Low-Power Sensors: Duty Cycles and Fusion or continue from the sensors module index.
Find help
3 reviewed answers.
Where should I start in a module?
Open the module page from the sidebar to see its chapters in order. Use the module map to return to a topic you need.
Modules and pathsReviewed
What can I try when a project does not work?
Check the symptom, then work through the diagnostic steps. Keep the error message and the smallest example that reproduces it.
When you are stuckReviewed
How do interactive examples work?
Use the interactive guide to check how examples and simulations work before changing your project.
Interactive examples guideReviewed