11 Hardware Components: Power and Load Integration
More
Depth: Practitioner
Progress saves as you read. Mark sections complete as you go; your progress appears in the sidebar.
11.1 Start With the Decision
This section: Start With the Decision — A controller pin sends a command signal; it is not the supply for the motor or valve used here.
A controller pin sends a command signal; it is not the supply for the motor or valve used here. A motor or valve is an actuator, a part that acts on its surroundings, and is the powered load. Prove both the power path that carries current to the load and the control path through its driver and protection.
11.2 Route Overview
This section: Route Overview — This is part 2 of 2.
This is part 2 of 2. Review Hardware Components: Selection Evidence for the preceding evidence.
11.3 Learning Objectives
This section: Learning Objectives
- Select drivers, protection, and supplies for actuator loads.
- Check logic levels, radio fit, reset, and power-loss states.
11.4 Chapter Roadmap
This section: Chapter Roadmap
- Actuators and Loads
- Do Not Debug Actuators Only in Firmware
- Communication Modules
- Power, Protection, Level Fit
- Fast Compatibility Rule
- Bench Tools and Evidence
- Incremental Examples
- Component Record Template
- Try It Now
- Find Missing Evidence
- Level-Shift Before Connecting
- Component Acceptance Evidence
- Match Evidence to Component Decisions
- Order the Integration Review
- Common Failure Patterns
- Choose Components From Evidence
- Breakouts Are Not Final Hardware
- Test Components One by One
- 4. Ignoring Reset and Power-Loss States
- Summary
- Key Takeaway
- See Also
11.5 Actuators and Loads
This section: Actuators and Loads — Actuator selection starts with the load.
Actuator selection starts with the load. A controller pin is a command signal; it is not a motor supply, heater supply, relay supply, valve supply, or lighting supply.
The pump example in Figure 11.1 separates the controller command from the power that moves the load.
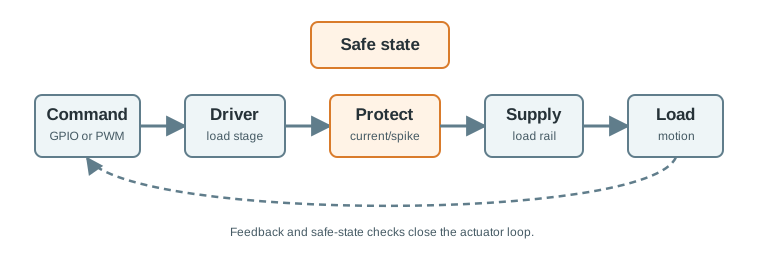
The GPIO line carries a command to the driver; it does not carry the pump current. The load supply powers the 5 V pump, while the driver and any needed flyback protection sit between the controller and that load. Measure startup current before choosing the driver, then scope the 3.3 V controller rail as the pump starts to check for a brownout. Current sensing or a measured output can confirm what happened after a command. A safe state defines what the pump does if the controller resets or communication fails. Those observations decide whether this drive path is fit for the prototype.
Review the full drive path:
Common actuator categories:
- Motion outputs include servos, brushed motors, steppers, solenoids, pumps, and valves. Review stall current, startup current, mechanical stops, and thermal limits.
- Switching outputs include relays, solid-state switches, load switches, and transistor stages. Review contact type, leakage, isolation, and failure mode.
- Human feedback outputs include indicators, displays, haptic devices, and audio outputs. Review visibility, brightness, acoustic level, update rate, and user context.
- Power outputs include heaters, lighting loads, and external switched rails. Review current path, connector rating, wiring strain, and thermal evidence.
If a motor, relay, heater, pump, or light causes resets, the fix is often in power distribution, grounding, driver sizing, protection, or wiring layout. Firmware retries can hide the symptom without removing the electrical cause.
11.6 Communication Modules
This section: Communication Modules — Communication modules are hardware components with system-level consequences.
Communication modules are hardware components with system-level consequences. They affect antenna placement, provisioning, credentials, energy use, enclosure design, update paths, and operational support.
11.6.1 Module Review Lanes
Use broad communication families cautiously:
- Local IP modules suit prototypes that can depend on existing network infrastructure and need direct application connectivity.
- Short-range personal-area modules suit pairing, commissioning, nearby control, and low-energy local interaction.
- Long-range low-throughput modules suit sparse telemetry where gateway placement and antenna evidence are part of the prototype.
- Wide-area modules suit remote prototypes that cannot rely on site infrastructure, but they add provisioning, power-state, and service-management evidence.
- Wired interfaces suit noisy environments, fixed equipment, lab rigs, and cases where power and data can share a controlled harness.
11.7 Power, Protection, Level Fit
This section: Power, Protection, Level Fit — Power components make the prototype survivable.
Power components make the prototype survivable. Many integration failures are caused by treating the power tree as an afterthought.
Use the six-field pump check in Figure 11.2 before connecting the load to the controller.
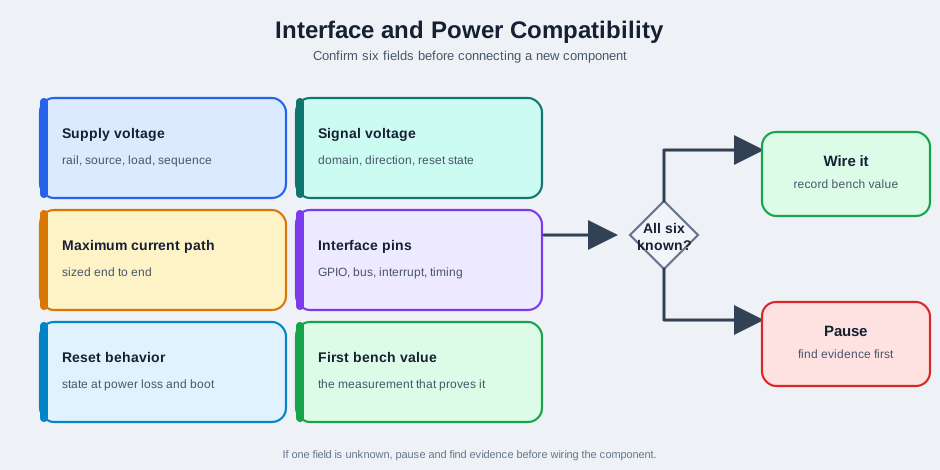
The worked pump check in Figure 11.2 begins with a mismatch: the controller has a 3.3 V rail, while the pump needs a 5 V load path. A GPIO can command a driver but cannot power that load. The six fields then expose missing facts: startup current, driver input, and safe reset state still need evidence. The first bench value is a measured startup current from a current-limited supply; the rail should also be scoped during pump start. Until those checks and a suitable driver and protection are chosen, the gate says pause. This is a wiring decision tied to measured load and reset behavior.
11.7.1 Power Review Checklist
11.7.2 Interface Checks
- GPIO needs voltage compatibility, pull state, drive strength, interrupt behavior, and reset defaults.
- Analog inputs need input range, source impedance, filtering, reference stability, and noise review.
- I2C-style buses need address uniqueness, pull-up selection, bus capacitance, shared-ground integrity, and recovery from a stuck device.
- SPI-style buses need chip-select separation, clock mode, signal integrity, and cable length review.
- UART-style links need level compatibility, baud tolerance, direction clarity, and boot-message behavior.
- One-wire or pulse interfaces need timing margin, cable effects, and interrupt or timer support.
Before connecting a new component, write down the supply voltage, signal voltage, maximum current path, required interface pins, reset behavior, and first bench measurement. If one field is unknown, pause and find evidence before wiring.
11.8 Bench Tools and Evidence
This section: Bench Tools and Evidence — Tools are part of the prototype process because they determine what can be proven.
Tools are part of the prototype process because they determine what can be proven. A team with only a working demo but no measurements has weak evidence.
Figure 11.3 shows which bench observation can answer each kind of integration question.
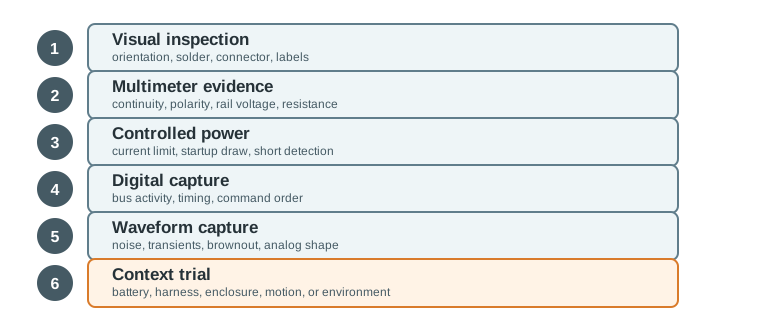
Visual inspection catches orientation, connector, and solder faults before power is applied. A multimeter then checks continuity, polarity, and rail voltage; a current-limited supply exposes startup draw or a short without relying on the controller rail. Digital capture answers a different question: whether bus traffic and command order match the intended sequence. Waveform capture can reveal transients, noise, or a brownout that a digital trace misses. The last context trial repeats the check with the battery, harness, enclosure, or motion expected in use. Choose the observation that addresses the suspected fault, and keep its result with the prototype decision.
11.8.1 Essential Bench Capabilities
11.8.2 Tool Selection Questions
- What failure would be invisible without this tool?
- Does the tool measure the signal at the same point where the failure occurs?
- Can the result be captured and attached to the component record?
- Will the tool still be useful when the prototype moves from breadboard to a wiring harness or PCB?
11.9 Incremental Examples
This section: Incremental Examples
11.9.1 Accept Temperature Sensor Module
A classroom logger needs temperature readings inside a plastic enclosure. A BME280 breakout looks convenient, but the acceptance decision should stay tied to the measurement task.
- Confirm the required range, accuracy, and update interval against the enclosure use case, not against the breakout-board popularity.
- Check whether the module is powered from 3.3 V or 5 V, whether the SDA and SCL pull-ups are already installed, and whether the I2C address conflicts with another part.
- Wire the module alone to the selected controller, record a stable room reading, warm the enclosure by hand, and save the raw reading plus the library version used for conversion.
The component can be accepted only if the team can explain both the measurement fit and the interface fit. If the same sensor later moves from a breakout board to a PCB footprint, the pull-up and placement decisions must be reviewed again.
11.9.2 Drive a Small Pump Safely
A plant-watering prototype needs a small 5 V pump. The controller GPIO cannot power that load directly, so the component decision includes the pump, driver, supply, protection, and feedback path.
- Measure the pump’s startup current with a current-limited bench supply before connecting it to the controller rail.
- Select a MOSFET, relay module, or motor-driver board that can handle startup current and thermal load, then add a flyback path or transient suppression where the load requires it.
- Scope the 3.3 V controller rail while the pump starts, and record whether the controller resets, whether sensor readings shift, and whether wiring changes reduce the disturbance.
This example is harder because the selected “component” is really a drive path. A firmware command that turns the pump on is not enough evidence unless the power rail, driver stage, and safe state are also understood.
11.9.3 Portable Environment Logger
The logger must record temperature, humidity, light level, and enclosure-open events while supporting local storage and small-battery operation. Component acceptance therefore needs evidence for both the readings and the electrical connections. Record supply and signal voltages, required pins, current paths, and reset behavior before wiring.
Begin with the controller on a current-limited source, recording idle and active current. Add sensors individually, checking rail voltage, interface detection, and believable readings before extending the build. Once the sensor bus is stable, add local storage and observe writes during reset and low-power transitions. Move to battery operation after reviewing the bench current measurements. Keep each result beside the component’s role and unresolved risks so debugging can follow observations rather than assumptions.
11.9.4 Candidate Components by Role
11.9.5 First Integration Pass
- Power the controller alone from a current-limited source and record idle and active current.
- Add one sensor at a time, proving rail voltage, interface detection, and a believable reading before adding the next component.
- Add local storage after the sensor bus is stable, then test write behavior during reset and low-power transitions.
- Add battery operation only after the bench supply current evidence is understood.
- Record every accepted component with its role, required pins, power state, first test result, and unresolved risks.
11.9.6 Evidence Record
11.10 Component Record Template
This section: Component Record Template — Use a short record so future revisions can understand the decision without reconstructing the whole bench session.
Use a short record so future revisions can understand the decision without reconstructing the whole bench session.
- Role: What the component does in the prototype.
- Requirement: The measurement, output, communication, or power need it satisfies.
- Electrical fit: Supply rail, signal voltage, current path, protection, and reset state.
- Interface fit: Protocol, pins, addresses, timing, pull-ups, level shifting, and cable concerns.
- Mechanical fit: Connector, mounting, orientation, enclosure exposure, and service access.
- Bench proof: Measurement, screenshot, log, or observation that proves the component works in context.
- Open risk: Any assumption that must be checked again before PCB, enclosure, or field use.
- Decision: Accepted, conditional, rejected, or deferred.
11.11 Try It Now
This section: Try It Now — Pick one component from a prototype you have seen or built.
Pick one component from a prototype you have seen or built. Write a four-line acceptance note:
- The component role and the requirement it supports.
- The supply voltage, signal voltage, current path, and interface pins.
- The first bench measurement or log that would prove it works before full integration.
- The unresolved risk that would block a PCB, enclosure, or field trial.
11.12 Find Missing Evidence
This section: Find Missing Evidence — A team selects a 3.3 V SHT31 temperature/humidity sensor, an ESP32 development board, a microSD module, and a single-cell LiPo charger board for a greenhouse logger.
A team selects a 3.3 V SHT31 temperature/humidity sensor, an ESP32 development board, a microSD module, and a single-cell LiPo charger board for a greenhouse logger. Their notes say “all libraries installed and demo sketch runs.”
Name two missing pieces of component evidence before the prototype is accepted. Strong answers include measurable details such as I2C pull-up voltage, bus address, sleep current, SD-card write current, charger protection behavior, enclosure airflow, calibration reference, or how the logger behaves during a low-battery reset.
11.13 Level-Shift Before Connecting
This section: Level-Shift Before Connecting
11.14 Component Acceptance Evidence
This section: Component Acceptance Evidence
11.15 Match Evidence to Component Decisions
This section: Match Evidence to Component Decisions
11.16 Order the Integration Review
This section: Order the Integration Review
11.17 Common Failure Patterns
This section: Common Failure Patterns
Example projects prove that a component can work somewhere. They do not prove that it matches your measurement range, enclosure, power state, interface boundary, or deployment environment.
Breakout boards are useful for bench evidence, but they hide layout, connector, pull-up, regulator, and protection choices that must be reviewed before a durable design.
When several new parts are added at once, failures become ambiguous. Add one component at a time and preserve the evidence that each new boundary works.
Many components behave differently during startup, brownout, sleep exit, or reset. Review the safe state before a prototype controls real loads or records important data.
11.18 Summary
This section: Summary — Hardware components are accepted through evidence, not familiarity.
Hardware components are accepted through evidence, not familiarity. A good component record connects the requirement to the electrical fit, interface fit, power behavior, mechanical constraints, bench proof, and unresolved risks. This keeps prototypes readable, debuggable, and ready for the next revision.
11.19 Key Takeaway
This section: Key Takeaway — Component choices should be justified by electrical fit, availability, firmware support, environmental limits, testability, and lifecycle risk, not only by module convenience.
Component choices should be justified by electrical fit, availability, firmware support, environmental limits, testability, and lifecycle risk, not only by module convenience.
11.20 See Also
This section: See Also
- Hardware Getting Started - build the first hardware prototype with a controlled setup sequence.
- Hardware Introduction - review the hardware prototyping path at a higher level.
- MCU vs MPU - decide what kind of controller belongs at the center of the prototype.
- PCB Design - move component evidence toward layout and fabrication decisions.
11.21 Continue Your Route
This section: Continue Your Route — This is the last part of this chapter.
This is the last part of this chapter. Return to Hardware Components: Selection Evidence or continue from the prototyping module index.
Find help
3 reviewed answers.
Where should I start in a module?
Open the module page from the sidebar to see its chapters in order. Use the module map to return to a topic you need.
Modules and pathsReviewed
What can I try when a project does not work?
Check the symptom, then work through the diagnostic steps. Keep the error message and the smallest example that reproduces it.
When you are stuckReviewed
How do interactive examples work?
Use the interactive guide to check how examples and simulations work before changing your project.
Interactive examples guideReviewed