5 Hardware Prototyping: First-Build Experiments
More
Depth: Practitioner
Progress saves as you read. Mark sections complete as you go; your progress appears in the sidebar.
5.1 Start With the Decision
This section: Start With the Decision — An LED and resistor can test a new board without hiding faults.
An LED and resistor can test a new board without hiding faults. Use the first build to prove power, pins, and code.
5.2 Route Overview
This section: Route Overview — This is part 1 of 2.
This is part 1 of 2. Continue with Hardware Prototyping: Board and Breadboard Bring-Up.
5.3 Learning Objectives
This section: Learning Objectives
- Test first build as experiment with a concrete scenario and pass criteria.
- Evaluate first measurement with range, error, power, and interface evidence.
5.4 Chapter Roadmap
This section: Chapter Roadmap
- In 60 Seconds
- Phoebe’s Field Notes: Why “LED Plus Resistor” and “LDR Divider” Are the Same Circuit
- Start With the Story
- First Build as Experiment
- Bring Up One Boundary at a Time
- First Failures Hit Boundaries
- The First-Bench Route
- Do Not Skip the Board-Only Test
- Set Up the Bench
- First Measurement
5.5 Start With the Story
This section: Start With the Story — The first bench build often fails for ordinary reasons: a jumper is in the wrong rail, a sensor has no ground reference, a board package is stale, or the supply current limit is set too low.
The first bench build often fails for ordinary reasons: a jumper is in the wrong rail, a sensor has no ground reference, a board package is stale, or the supply current limit is set too low. A novice sees a broken project. A good prototyper sees a sequence to make the failure visible without guessing.
Start this chapter with one safe circuit and one observable result. Power first, signal second, firmware third, notes throughout. When the bench record is clear enough for another person to repeat, the prototype has become evidence instead of a private memory.
5.6 First Build as Experiment
This section: First Build as Experiment — Use Figure 5.1 to build a board, 3.3 V rail, and one red LED in measured stages.
Use Figure 5.1 to build a board, 3.3 V rail, and one red LED in measured stages.
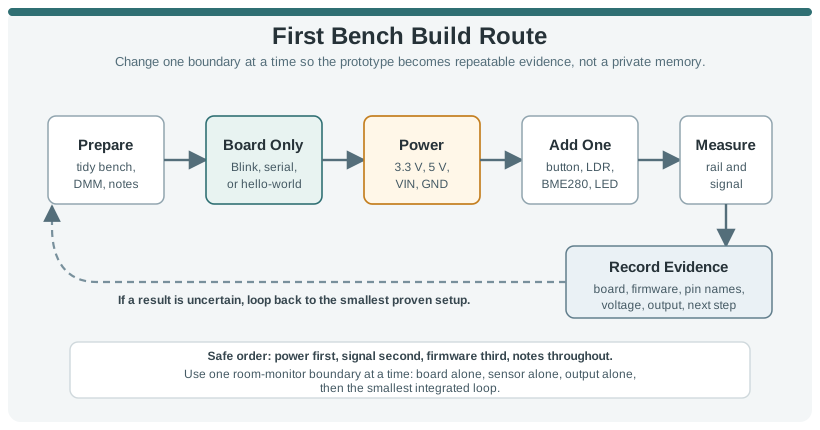
First run Blink, serial, or hello-world firmware with the board alone. Next connect 3.3 V and ground to the breadboard and measure that rail before adding a part. The final stage drives a red LED through 130 Ω; with a 2.0 V LED drop, (3.3 − 2.0) V ÷ 130 Ω = 10 mA. The pin note maps tutorial D2 to board GP2 and firmware GPIO2, but the real pinout and wire still need checking. Record the board, firmware, pin names, measured voltage, and output before adding complexity. That staged record makes a failed rail or wrong pin easier to isolate.
The reliable path is board first, power second, one external part third. A room-monitor demo, button-and-LED test, or sensor-readout sketch should never start with every wire, library, and enclosure choice changing at once.
- Prove the board alone before external components can be blamed for upload, USB cable, boot mode, or serial-port failures.
- Measure the rail before and after each new part so a load, reversed sensor, or short is caught early.
- Keep the record small but include board name, firmware file, pin names, measured voltage, observed output, and next step.
For example, a first room-monitor build with an Arduino Uno R4 WiFi, Raspberry Pi Pico W, ESP32 DevKit, or Adafruit Feather should begin with the board by itself. Upload Blink, a serial heartbeat, a CircuitPython print loop, a MicroPython script, or an ESP-IDF hello-world example and write down the board target, USB port, tool version, and observed output. If that baseline fails, the next useful action is not wiring a BME280, relay board, or OLED display. It is checking the cable, boot mode, driver, board package, and power state while the setup is still simple.
The board-only step is easier to understand when the physical interfaces are visible. In Figure 5.2, inspect the power and USB entries before the labelled headers, because those are the boundaries that must work before a sensor can be blamed.

Read Figure 5.2 from the USB connector and barrel jack to reset, the microcontroller, and the header labels. USB can supply both power and the programming path, while the alternate power input changes the electrical assumptions. Reset and the onboard controller provide a simple heartbeat target, and the labelled headers are where later wiring begins. Proving this unchanged board state keeps the first external component from being mixed into cable, target-selection, or upload faults.
Photo: Creative Tools, CC BY 2.0.

After the baseline works, add one boundary. A beginner temperature indicator might add only a BME280 on I2C, measure the 3.3 V rail before and after wiring, scan or log the detected address, and print one raw reading. The next build might add an LED through a resistor or a MOSFET input for a low-current indicator. The point is to leave a trail of working states: board alone, sensor alone, output alone, then the smallest integrated loop. When the final loop fails, you know which boundary changed last.
5.7 Bring Up One Boundary at a Time
This section: Bring Up One Boundary at a Time — A useful beginner bench can be simple: a development board, breadboard, jumper wires, resistors, USB cable, digital multimeter, and, when available, a current-limited bench supply.
A useful beginner bench can be simple: a development board, breadboard, jumper wires, resistors, USB cable, digital multimeter, and, when available, a current-limited bench supply. The discipline is in the sequence, not the price of the tools.
- Board baseline: upload Blink, a serial heartbeat, CircuitPython REPL print, MicroPython script, Arduino sketch, PlatformIO project, ESP-IDF hello-world, or Zephyr sample before wiring a sensor.
- Power check: identify 3.3 V, 5 V, VIN, GND, EN, RESET, and battery pins; measure with a DMM; avoid treating GPIO pins as load supplies.
- First input: test a button with pull-up or pull-down, an LDR divider, a potentiometer on an ADC pin, or an I2C sensor such as BME280 or SHT31 by itself.
- First output: start with an LED plus resistor, small buzzer, display message, or driver input; use a transistor, MOSFET, relay module, or motor driver before switching real loads.
A practical first-bench log should be boring and specific. Start with the date, board model, power source, current limit if a bench supply is used, firmware file, toolchain, and the exact stop condition. Before applying power to a breadboard circuit, use continuity mode to check that supply and ground are not shorted. Then power the board and measure the rail at the board header and at the breadboard rail. A USB-powered Pico W or ESP32 board may look fine at the USB connector while a loose jumper leaves the sensor rail unpowered. Measuring both places prevents that mistake from becoming a library problem.
The jumper-wire photo in Figure 5.3 shows the removable connections used in an early bench build.

A metal male pin enters a board header or breadboard row, and the black housing gives a place to hold the lead while placing it. The coloured conductor helps a builder follow a path by eye, but colour does not prove electrical continuity or destination. Trace both ends to their numbered rows, then use a meter on a suspect lead before treating a missing sensor reading as a firmware fault. The photograph shows a connection style and its visible parts; the board rail and row measurements establish whether this particular wiring works.
Choose tools for the symptom. A digital multimeter can prove polarity, voltage, continuity, and a missing ground. A serial monitor can prove firmware identity and show whether the loop is running. A Saleae Logic, Bus Pirate, or sigrok/PulseView capture can show whether I2C SCL and SDA are moving and whether the sensor NACKs its address. A current-limited bench supply can keep a wiring mistake from damaging a regulator. Beginners do not need all of these at once, but they should understand what each tool can and cannot see.
The multimeter in Figure 5.4 turns a wiring question into a chosen measurement.

The rotary selector chooses continuity, voltage, or current, and the LCD reports the result for the connected probes. For a new breadboard, check continuity with power removed; then measure voltage between the board rail and ground at the points the circuit uses. A current reading requires opening the circuit and placing the meter in series, so it cannot be taken like a voltage reading. The red and black probes identify the two measurement points, but their position in the photo is not a circuit test. Record the selected mode, points, and reading before changing firmware.
5.8 First Failures Hit Boundaries
This section: First Failures Hit Boundaries — Beginner hardware failures often happen at boundaries: USB to board, board to breadboard, GPIO to load, 3.3 V logic to 5 V module, firmware pin name to package pin, or I2C address to library setting.
Beginner hardware failures often happen at boundaries: USB to board, board to breadboard, GPIO to load, 3.3 V logic to 5 V module, firmware pin name to package pin, or I2C address to library setting.
- Electrical boundary: check voltage domain, current draw, polarity, shared ground, current-limiting resistor, flyback diode, and pull-up or pull-down path.
- Firmware boundary: record board target, port, baud rate, bootloader mode, library version, pin constant, firmware hash, and serial output timing.
- Breadboard boundary: confirm row breaks, rail splits, jumper continuity, component orientation, and whether the supply rail is connected on both sides.
- Debug boundary: return to the known-good firmware and board-only measurement whenever a new symptom appears after adding a wire, module, or library.
That habit turns a first build from a pile of parts into a repeatable engineering setup.
Many early faults are caused by two names for the same physical point not being checked against each other. A tutorial may say D2, a board silkscreen may say GP2, a microcontroller data sheet may name the package pin differently, and a framework may expose the pin as GPIO2 or a board-specific constant. A breadboard adds another mapping layer because the power rails may be split and the rows are connected only in groups. Under the hood, a first build succeeds when those maps agree: schematic or pinout, physical wire, firmware constant, measured voltage, and observed behavior.
Signal level and current limits are the other hidden boundaries. A 5 V sensor output can overdrive a 3.3 V GPIO unless a divider, level shifter, or compatible module is used. A relay coil, pump, motor, solenoid, or LED strip can reset or damage a controller if it is driven directly from a GPIO instead of a transistor, MOSFET, relay module, or motor driver with the right supply and flyback path. A first-bench workflow catches those limits before the circuit is enclosed, soldered, or copied into a more complex prototype.
5.9 Learning Objectives
This section: Learning Objectives
By the end of this chapter, you will be able to:
- Prepare a first hardware prototyping bench with safe power, measurement, and wiring habits.
- Bring up a development board using a known-good firmware test before adding external components.
- Wire a simple input and output on a breadboard while checking power, ground, and signal direction.
- Debug first-build failures using measurement evidence instead of random rewiring.
- Record the prototype setup so the next revision can be repeated and improved.
5.10 The First-Bench Route
This section: The First-Bench Route — Getting started is not a race to a complex demo.
Getting started is not a race to a complex demo. The fastest reliable path is to prove the smallest useful circuit, then add one boundary at a time.
Use this route every time you begin a new hardware prototype:
If the board, cable, toolchain, and serial monitor have not been proven alone, every later wiring problem becomes harder to diagnose. A board-only test is your baseline.
5.11 Set Up the Bench
This section: Set Up the Bench — Your first bench does not need to be elaborate.
Your first bench does not need to be elaborate. It needs to be repeatable and measurable.
5.11.1 Minimum Useful Bench
5.11.2 Before Applying Power
Inspect Figure 5.5 and ask which evidence must exist before the next component is allowed onto the powered build.
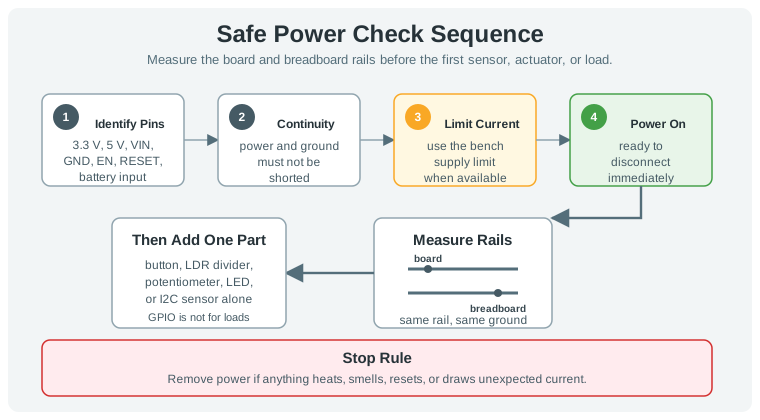
Follow Figure 5.5 from the documented supply, ground, enable, reset, and battery pins into the power-off continuity check. A current-limited source adds protection where available, but the operator must still energize ready to disconnect. Measure the rail at both the board header and breadboard before adding one part. Heating, smell, repeated resets, or unexpected current invokes the stop rule: remove power before touching wiring. This makes electrical safety the entry condition for each incremental experiment.
Run these checks before the first power-on:
- Identify the intended supply pin and ground pin.
- Confirm the supply voltage expected by the board or component.
- Look for accidental bridges between power and ground.
- Set a current limit if using a bench supply.
- Keep one hand ready to disconnect power if the circuit behaves unexpectedly.
Before you connect any sensor or actuator, measure the board supply rail while the board is running. Write down the value. That number becomes the reference for later checks.
5.12 Continue to the Next Part
This section: Continue to the Next Part — Carry this evidence into Hardware Prototyping: Board and Breadboard Bring-Up, which begins with Bring Up the Development Board.
Carry this evidence into Hardware Prototyping: Board and Breadboard Bring-Up, which begins with Bring Up the Development Board.
Find help
3 reviewed answers.
Where should I start in a module?
Open the module page from the sidebar to see its chapters in order. Use the module map to return to a topic you need.
Modules and pathsReviewed
What can I try when a project does not work?
Check the symptom, then work through the diagnostic steps. Keep the error message and the smallest example that reproduces it.
When you are stuckReviewed
How do interactive examples work?
Use the interactive guide to check how examples and simulations work before changing your project.
Interactive examples guideReviewed