30 I2C: Transactions and Bus Design
More
Depth: Practitioner
Progress saves as you read. Mark sections complete as you go; your progress appears in the sidebar.
30.1 Overview
This section: Overview — This first route builds I2C from electrical signaling through addressed transactions and bus constraints.
This first route builds I2C from electrical signaling through addressed transactions and bus constraints.
This is part 1 of 2. Continue with I2C: Bring-Up and Diagnosis for the second focused route.
30.2 Start With Many Chips Sharing Two Wires
This section: Start With Many Chips Sharing Two Wires — Picture three sensors sharing two wires until adding a fourth makes every reading stop.
Find the First Device Holding the Shared Bus
Picture three sensors sharing two wires until adding a fourth makes every reading stop. A microcontroller means a small computer on one chip that starts transfers and controls the device.
Name each address, pull-up, wire length, bus voltage, clock rate, and expected reply. Test one sensor, all sensors, a duplicate address, and a device holding a line low.
Keep the wiring, settings, address scan, signal edges, acknowledgements, and failure time. This proves one local bus setup, not every board layout; the deeper sections explain transfers, electrical limits, timing, arbitration, and recovery.
I2C is useful because one controller can talk to many nearby devices using only SDA and SCL. The shared bus works only when addresses, pull-ups, capacitance, timing, and acknowledgements all stay inside the design limits.
Follow one read from controller to sensor and back. The story shows why a missing ACK, slow edge, duplicate address, or stretched clock is not a mystery; it is a specific bus promise being broken.

30.4 Learning Objectives
This section: Learning Objectives
- Explain I2C Architecture: Describe the two-wire bus structure with SDA and SCL, and justify why open-drain outputs require pull-up resistors
- Calculate Pull-Up Resistor Values: Apply the RC rise-time formula to select appropriate resistor values for a given bus capacitance and speed mode
- Distinguish I2C Addressing: Identify how 7-bit addresses map to write and read bytes, and select device addresses to avoid bus conflicts
- Implement I2C Transactions: Explain the read and write transaction sequences (START, address frame, ACK, data, STOP) and translate them into test steps
- Diagnose I2C Failures: Analyze bus-level symptoms — missing ACK, slow rise times, address conflicts, clock stretching — and identify their root causes
- Build I2C Applications: Plan and verify sensor/display connections over a shared I2C bus before writing firmware
I2C (pronounced eye-squared-see) is a simple way to connect multiple sensors and chips using just two wires. Think of it as a shared phone line where each device has its own phone number — the main controller calls each device by its address and they take turns sharing information. It is one of the most common ways to connect sensors in IoT projects.
“I love I2C!” said Temperature Terry. “I need just two signal wires — SDA for data and SCL for the clock — plus power and ground. Up to 112 of us can share those wires (fewer in practice)!”
the microcontroller explained how it works. “I am the master. When I want Sammy’s temperature reading, I send his address — say 0x48 — on the bus. Only Sammy responds. Then I send a request, and he sends back the data. Everyone else stays quiet because it was not their address.”
“The pull-up resistors are super important though,” warned the LED. “The wires need them to work properly. If you forget the pull-ups, nothing talks! It is the number one beginner mistake with I2C. And sometimes two sensors accidentally have the SAME address — then you get conflicts.”
“I2C is not the fastest,” admitted the battery, “only 100 to 400 kHz for most IoT work. But it is incredibly simple — just two wires for dozens of sensors! Perfect for when you have a temperature sensor, a humidity sensor, a pressure sensor, and a display all connected to one microcontroller. Minimal wiring, maximum flexibility.”
30.5 Prerequisites
This section: Prerequisites
Before diving into this chapter, you should be familiar with:
- Wired Communication Fundamentals: Understanding of synchronous communication, multi-drop topology, master-slave architecture
- Digital Electronics: Understanding of open-drain outputs and pull-up resistors
Follow one shared I2C bus from wiring to release:
- First identify why SDA, SCL, open-drain outputs, and pull-ups make many devices share two wires.
- Then map each device to a unique address and translate the 7-bit address into write and read bytes.
- Next walk the START, ACK, repeated START, data, and STOP sequence that makes a real transaction work.
- After that use scanner and BME280 labs to turn bus symptoms into evidence.
- Finally calculate pull-up limits and build a reliability record for speed, capacitance, lockup, and recovery.
Checkpoints recap the main design decisions; collapsed material deepens the same path.
30.6 I2C Overview
This section: I2C Overview — Start with the physical promise: every device sees the same two wires, so the bus only works if each participant releases the lines and waits its turn.
Start with the physical promise: every device sees the same two wires, so the bus only works if each participant releases the lines and waits its turn.
I2C (IIC, I-squared-C) is a popular multi-device communication bus developed by Philips (now NXP) in the 1980s.
Pronunciation: “I-squared-C” or “I-two-C”
Full name: Inter-Integrated Circuit
30.6.1 Characteristics
| Feature | Value |
|---|---|
| Signal wires | 2 (SDA + SCL; power and ground are also needed) |
| Topology | Multi-drop (bus) |
| Sync/Async | Synchronous (SCL = clock) |
| Duplex | Half-duplex (SDA is bidirectional) |
| Speed | 100 kHz (standard), 400 kHz (fast), 1 MHz (fast+), 3.4 MHz (high-speed) |
| Distance | Typically < 1 m (same PCB or short cable); longer runs need lower speed or bus buffers. |
| Address values | 112 non-reserved ordinary 7-bit values; 10-bit addressing has 1024 values. Practical device count is limited by loading and address conflicts. |
| Master/Slave | Multi-master capable |
Trace each line in Figure 30.1 from one end of the bus to the other before you add a device to a real board.
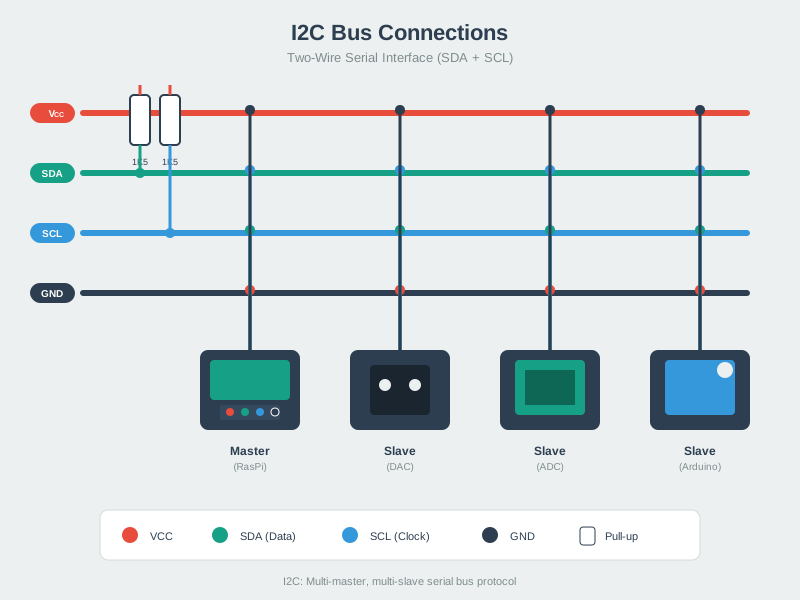
Four boards hang off the same two wires: a Raspberry Pi as controller, and a DAC, an ADC and an Arduino as devices. SDA and SCL run straight past all of them, and a ground line runs with them, which is easy to forget on a long lead. Near the supply rail sit two 1K5 pull-up resistors, one per line. They are the reason the bus idles high. Every device drives low only, so any one of them can pull a line down without fighting another. Figure 30.1 shows the full electrical cost of adding a device: two shared wires, one ground, and one pair of pull-ups for the whole bus.
30.7 Why I2C is Popular
This section: Why I2C is Popular
Advantages:
- Only 2 wires (minimal pin usage)
- Multiple devices on same bus
- Simple addressing (each device has unique address)
- Bidirectional (master can read/write to slaves)
- Well-supported by sensors, displays, EEPROMs
30.8 I2C Signals
This section: I2C Signals — Look at where the pull-ups attach in Figure 30.2, because that placement is what makes the shared lines work.
Look at where the pull-ups attach in Figure 30.2, because that placement is what makes the shared lines work.
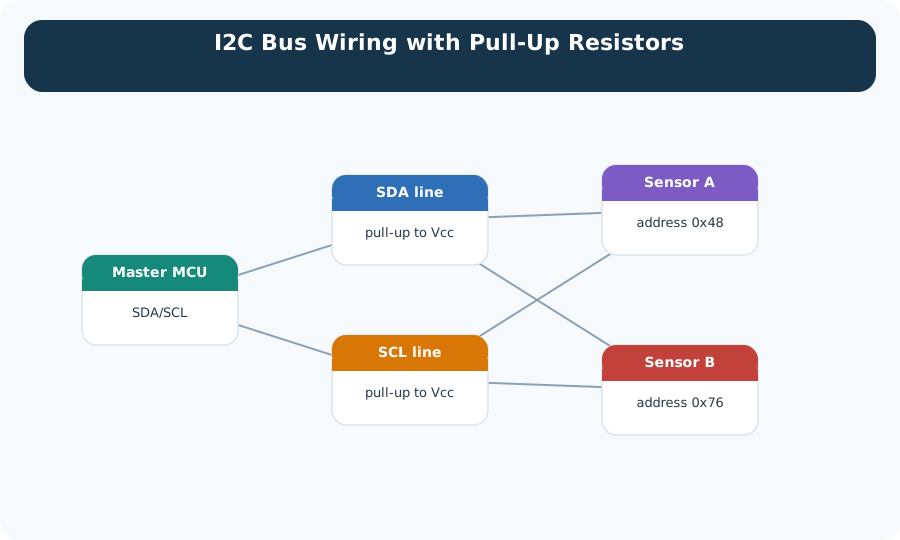
The controller on the left drives SDA and SCL, and both lines run on to two sensors, one at address 0x48 and one at 0x76. Each line has its own pull-up to Vcc, drawn between the controller and the sensors rather than at any single device. That is deliberate. The resistors belong to the bus, not to a board, so adding a third sensor adds no more of them. The two addresses in Figure 30.2 carry the other rule. The wires are shared by everyone, so the address is the only thing that decides which device is being spoken to.
SDA (Serial Data):
- Bidirectional data line
- Carries address and data
- Open-drain (requires pull-up resistor)
SCL (Serial Clock):
- Clock signal from master
- Slaves can hold it LOW (“clock stretching”) to slow master
- Open-drain (requires pull-up resistor)
30.9 Pull-Up Resistors
This section: Pull-Up Resistors — Treat pull-up selection as a bounded electrical calculation.
Treat pull-up selection as a bounded electrical calculation. Start with the highest resistor that still charges the measured bus capacitance within the mode’s rise-time limit, then check the lowest resistor that every connected device can safely pull below the permitted low-level voltage. Compare the resulting window with the fitted value, not with a universal favourite. A 4.7 kΩ part is common because it often fits short 100 kHz or 400 kHz boards, but cable length, device count, level shifting, and breadboard capacitance can move the valid window. Verify the decision on SDA and SCL with an oscilloscope at the intended clock rate.
Critical requirement: Both SDA and SCL need pull-up resistors to VCC.
Typical values:
- 4.7 kohm - Most common (400 kHz, few devices, short traces)
- 2.2 kohm - For longer cables, many devices, or fast mode
- 10 kohm - For very short cables, few devices, 100 kHz only
Why needed? I2C uses open-drain outputs - can only pull LOW, not HIGH. Pull-up resistors provide the HIGH level. See the detailed calculation in the Worked Example section for guidance on choosing the right value.
Checkpoint: Shared Bus Basics
You now know:
- I2C gets its pin savings from two shared lines, SDA and SCL, rather than one private wire per peripheral.
- Open-drain signalling means devices pull low or release; pull-up resistors create the high level.
- That same sharing makes capacitance, pull-up strength, and bus length design constraints.
The wiring is only half the contract. Once every device is attached to SDA and SCL, the controller still needs a way to choose exactly one responder.
30.10 I2C Addressing
This section: I2C Addressing — Each device on the bus needs a unique 7-bit address.
Each device on the bus needs a unique 7-bit address.
Address space:
- 7-bit addresses: 0x08 to 0x77 (112 addresses)
- Some addresses reserved (0x00-0x07, 0x78-0x7F)
Common I2C device addresses:
| Device | Address (Hex) | Address (Decimal) |
|---|---|---|
| OLED Display (SSD1306) | 0x3C or 0x3D | 60 or 61 |
| BME280 (Temp/Humidity) | 0x76 or 0x77 | 118 or 119 |
| MPU6050 (IMU) | 0x68 or 0x69 | 104 or 105 |
| RTC DS3231 | 0x68 | 104 |
| EEPROM 24C256 | 0x50 - 0x57 | 80 - 87 |
Finding device addresses:
Use an I2C scanner when a board powers up but a sensor library cannot find its device.
| Step | What you check | Expected evidence |
|---|---|---|
| 1. Power and ground | Sensor VCC and GND match the controller voltage | Sensor board powers on; no hot components |
| 2. Bus wiring | SDA to SDA, SCL to SCL, shared ground | Scanner can probe the bus without lockup |
| 3. Pull-ups | SDA and SCL have pull-ups to the correct voltage | Lines idle HIGH on a meter or oscilloscope |
| 4. Address scan | Probe addresses from 0x08 to 0x77 | Known devices appear at their documented addresses |
| 5. Conflict check | Compare detected addresses against the design | Duplicate addresses are resolved with address pins or a mux |
Example scan result:
| Detected address | Likely device | What to do next |
|---|---|---|
0x3C | OLED display | Use the OLED library with address 0x3C. |
0x76 | BME280/BMP280 | Use the sensor library with address 0x76. |
| No addresses | Wiring, pull-up, or power problem | Check SDA/SCL order, VCC, ground, and pull-up resistors. |
30.11 I2C Communication Protocol
This section: I2C Communication Protocol — Read the two traces in Figure 30.3 together, because on this bus the meaning of the data line depends on what the clock is doing.
Read the two traces in Figure 30.3 together, because on this bus the meaning of the data line depends on what the clock is doing.
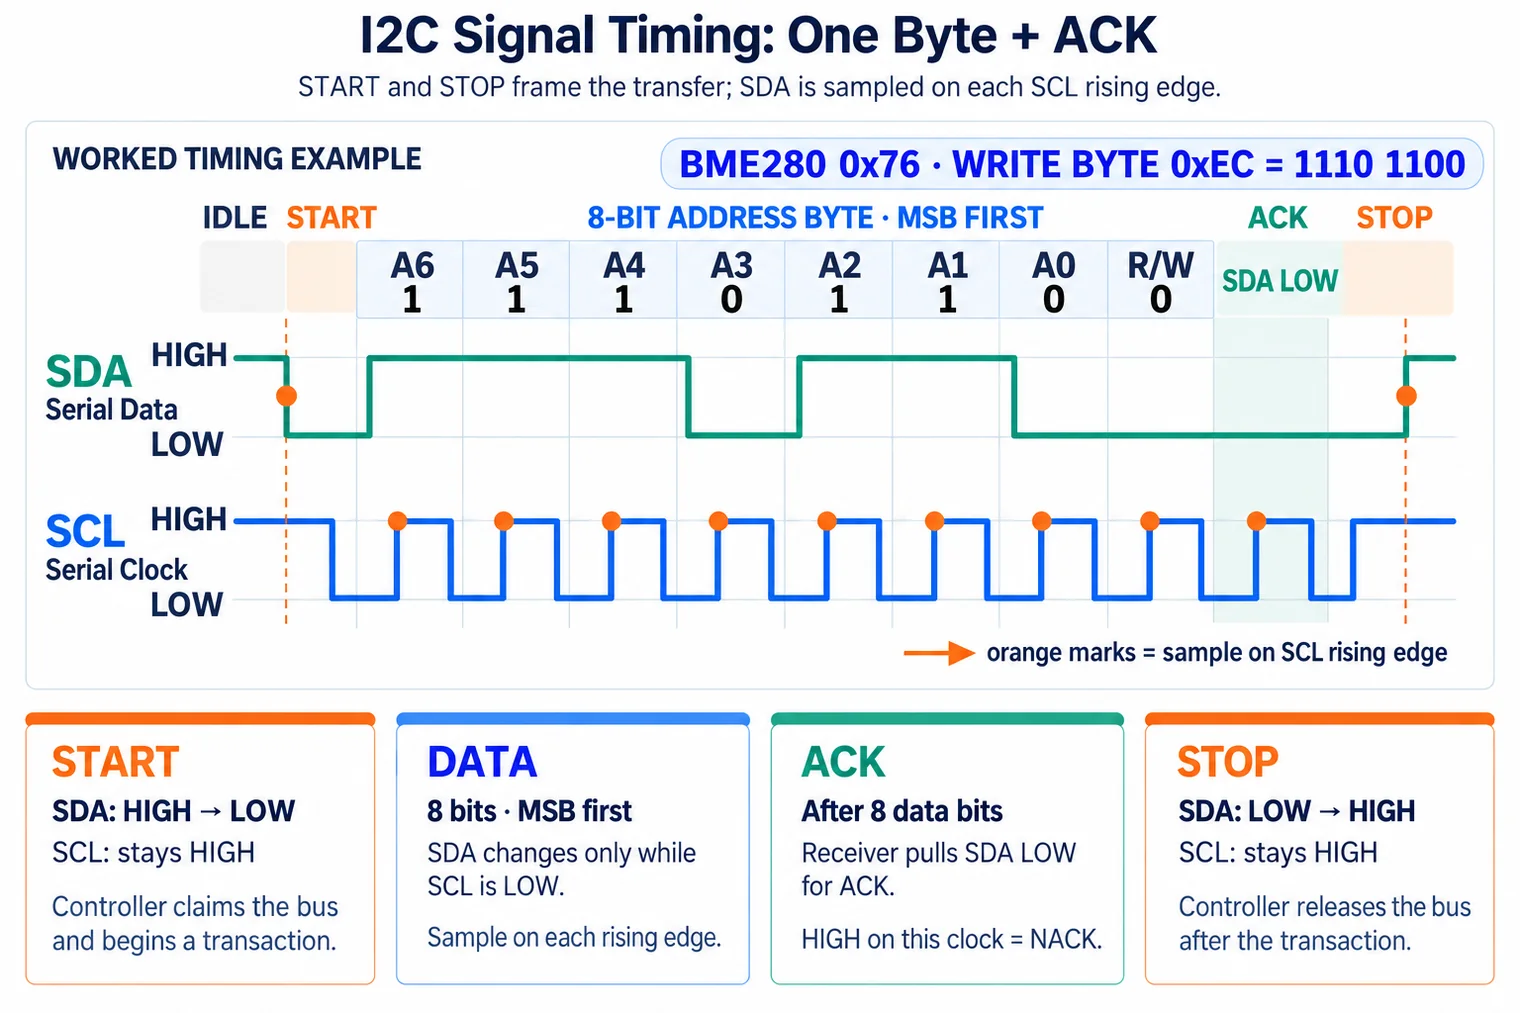
The bus idles with both lines high. START is the exception that opens everything. SDA falls while SCL is still high, which is never allowed during data. Then eight bits go out, most significant first, and the marks show where each one is sampled, on the rising edge of the clock. Between those edges SDA may change, and during them it may not. The worked byte is 0xEC, the write address for the sensor. On the ninth clock the receiver pulls SDA low to acknowledge, and a high there would mean no device answered. STOP closes the frame in Figure 30.3 by reversing the opening move. Start and Stop Conditions:
| Bus event | SDA behavior | SCL behavior | Meaning |
|---|---|---|---|
| Idle bus | HIGH | HIGH | Pull-up resistors are holding both lines released. |
| START | HIGH to LOW | Stays HIGH | The controller claims the bus and begins a transaction. |
| Data bit | Stable while sampled | Pulses LOW/HIGH | The receiver reads SDA while SCL is HIGH. |
| STOP | LOW to HIGH | Stays HIGH | The controller releases the bus after the transaction. |
Data Transfer (1 byte + ACK):
| Phase | Who drives SDA? | What the receiver checks |
|---|---|---|
| 8 data bits | Transmitter | Bits arrive MSB first while SCL pulses. |
| ACK clock | Receiver | Pulls SDA LOW for ACK, leaves it HIGH for NACK. |
| Next byte or STOP | Controller | Continues with another byte, a repeated START, or STOP. |
Data transfer rules:
- During data bits, SDA changes only while SCL is low; START and STOP deliberately change SDA while SCL is high.
- SDA is sampled when SCL is HIGH
- Data transmitted MSB first (most significant bit first)
Use Figure 30.4 to identify the edge relationships that delimit one I2C transaction and acknowledge each byte.
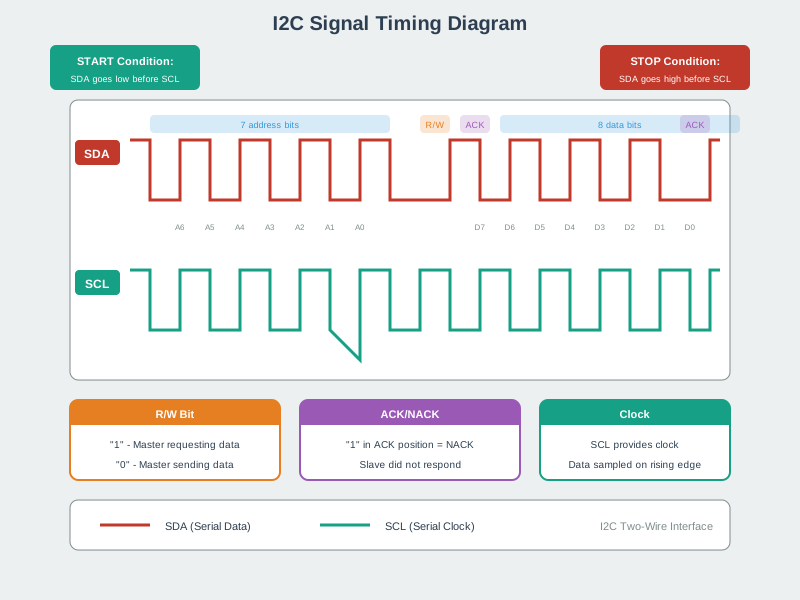
Begin with the START condition, where SDA falls while SCL remains high; ordinary data changes occur while SCL is low so receivers can sample stable bits while it is high. Follow the address and read/write bit into the ninth clock, which carries the receiver’s acknowledgement. Data bytes repeat that eight-bit-plus-ACK pattern. The STOP condition reverses the opening relation: SDA rises while SCL is high. These rules explain why pull-ups, rise time, and stuck-low faults are part of the protocol contract, not merely wiring details.
30.12 I2C Write Transaction
This section: I2C Write Transaction — A write is a fixed sequence, and each block in it must be acknowledged before the next is allowed.
A write is a fixed sequence, and each block in it must be acknowledged before the next is allowed. Figure 30.5 puts that sequence in order.
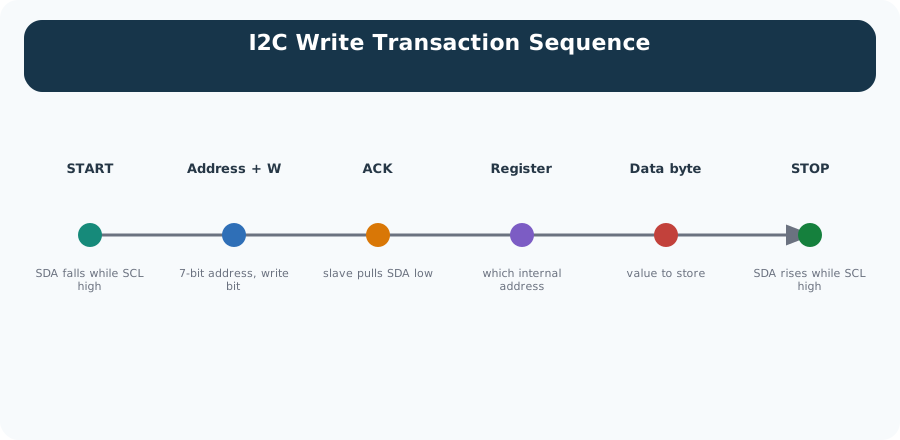
Read Figure 30.5 as six blocks in time order. The opening condition is a falling data line while the clock is still high, a pattern ordinary data bits never produce, so every device on the bus recognises it. Next comes the seven-bit address with a write bit, then the first acknowledgement, where the addressed device pulls the data line low to say it is there. Only after that does the controller name an internal register and send the value for it. The closing condition mirrors the opening one. This order explains most bring-up failures. A missing acknowledgement after the address means the receiver did not accept that address; one after the register byte means it did not accept that byte. Check transaction phase, device readiness, and wiring before blaming the register value.
Steps:
- Master sends START
- Master sends slave address + write bit (0)
- Slave acknowledges (ACK)
- Master sends register address
- Slave ACKs
- Master sends data byte
- Slave ACKs
- Master sends STOP
30.13 I2C Read Transaction
This section: I2C Read Transaction — Follow Figure 30.6 to see why reading a register takes two addressing steps rather than one.
Follow Figure 30.6 to see why reading a register takes two addressing steps rather than one.
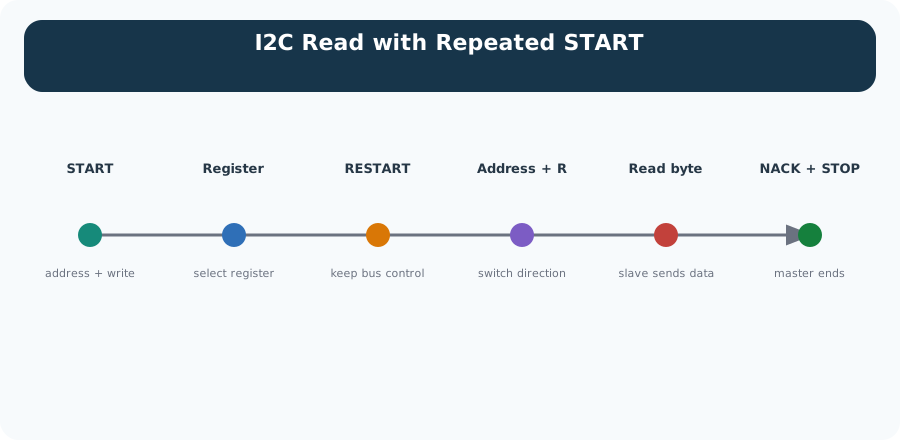
The sequence opens like a write. START, then the device address with the write bit, then the register the controller wants. At that point the controller has said what to read but has not read anything. Instead of stopping, it issues a repeated START, which keeps the bus and stops another controller taking over between the two halves. The address goes out again, now with the read bit, and the device returns the byte. The controller ends with a NACK and then STOP, which tells the device not to send more. Figure 30.6 is one transaction, not two, and that is what protects the register selection.
-

Pete starts the bus and sends the address in write mode.
-

The sensor confirms, then Pete sends the register.
-

A repeated start keeps the same transaction alive.
-

Pete sends the address again in read mode.
-

The sensor sends data, and Pete ends the final byte.
-

A stop releases both shared wires.
The steps below spell out the same transaction that Figure 30.6 draws, in the order a controller issues them.
Steps:
- Master sends START
- Master sends slave address + write bit (0)
- Slave ACKs
- Master sends register address to read from
- Slave ACKs
- Master sends REPEATED START (restart without releasing bus)
- Master sends slave address + read bit (1)
- Slave ACKs
- Slave sends data byte(s); master ACKs each except the last
- Master sends NACK on final byte (signals end of read)
- Master sends STOP
The Repeated START (step 6) is essential: it lets the master switch from write mode (selecting the register) to read mode (receiving data) without another device claiming the bus in between.
This section:
Checkpoint: Addressed Transactions
You now know:
- A normal 7-bit bus uses usable addresses from 0x08 to 0x77, so duplicate module defaults must be planned before wiring.
- Address 0x76 becomes 0xEC for the write phase and 0xED for the read phase because the direction bit is part of the first bus byte.
- A register read is a two-phase exchange: write the register pointer, issue repeated START, then read the returned data before STOP.
This section: — With the bus grammar in place, the next question is practical: can the real board prove that those frames are reaching real devices?
With the bus grammar in place, the next question is practical: can the real board prove that those frames are reaching real devices?
30.14 Arduino/ESP32 I2C Example
This section: Arduino/ESP32 I2C Example — The transaction diagrams and address explorer above are the beginner path.
The transaction diagrams and address explorer above are the beginner path. Use this sketch only when you are ready to test a real I2C sensor.
Look at the blue sensor board before the build checklist. The edge labels show VCC, GND, SCL, and SDA, with other pins beside them and a mounting hole near each end.

Use the visible labels to locate the four basic connections, then confirm the board’s voltage and pinout from its specification before powering it. The photo cannot prove the installed wiring or the scanner result; the checklist below supplies those tests.
| Task | I2C concept being tested | Success evidence |
|---|---|---|
| Wire SDA/SCL correctly | Shared two-wire bus | Scanner detects 0x68 or 0x69. |
| Wake the sensor | Write transaction to a control register | The device stops reporting sleep/default values. |
| Select the X-axis register | Write phase before a register read | Logic trace shows address + write, register byte, repeated START. |
| Read two data bytes | Repeated START and read phase | Two bytes arrive and combine into a signed acceleration value. |
| Repeat slowly first | Stable bus before performance tuning | Values update without missing ACKs or bus lockups. |
Before wiring anything, it helps to recognise the board this checklist assumes. Figure 30.7 shows one, with every pin you will touch printed beside it.

Read the printed labels down the left edge of Figure 30.7. Power and ground come first, then SCL and SDA, the only two signal wires this bus needs and the pair the scanner step drives. Four pins further down are the ones beginners mis-wire. XDA and XCL are a second bus for an extra sensor, not spares for the first. AD0 is the address select: leave it alone and the chip answers at 0x68, pull it high and it answers at 0x69, which is exactly the difference the scanner reports. The chip in the middle carries its own part number, so a board can be identified from a photo before any code runs.
ESP32 wiring reference:
| ESP32 pin | Sensor pin | Note |
|---|---|---|
| GPIO 21 | SDA | Data line; add a pull-up if the sensor board lacks one. |
| GPIO 22 | SCL | Clock line; keep wires short for reliable fast mode. |
| 3.3 V | VCC | Match the sensor module voltage. |
| GND | GND | All I2C devices need a shared ground. |
30.15 Clock Stretching
This section: Clock Stretching — Problem: Slave needs more time to process data.
Problem: Slave needs more time to process data.
Solution: Slave holds SCL LOW to pause communication.
| Step | What happens on SCL | What the controller should do |
|---|---|---|
| Controller releases SCL | SCL should rise HIGH | Wait for the line to actually go HIGH. |
| Device needs more time | Device holds SCL LOW | Do not force the next clock edge. |
| Device finishes processing | Device releases SCL | Resume the transaction. |
| Timeout exceeded | SCL remains LOW too long | Reset or recover the bus. |
Use case: Slow sensors (temperature readings take time), EEPROM write operations.
This section:
Avoiding Address Conflicts:
- Check device datasheets before buying
- Many sensors have address select pins (A0, AD0) to change address
- Use I2C scanner sketch to verify addresses
- Plan device selection to avoid conflicts
Common Conflicts:
- 0x68: MPU6050, DS1307/DS3231 RTC → Use MPU6050 AD0 pin for 0x69
- 0x76/0x77: BMP280, BME280, BME680 → Use SDO pin
- 0x27/0x3F: LCD backpack modules → Check board
Pull-up Resistors:
- 4.7k: Most common (400 kHz)
- 2.2k: Long cables or many devices
- 10k: Short cables, few devices
Pull-up resistor values aren’t arbitrary—they’re calculated from RC time constant requirements.
For I2C Fast-mode (400 kHz), the specified rise time from 30% to 70% of VCC must be no more than 300 ns. For this illustrative bus with pF (three devices plus PCB traces):
Solving for maximum resistance:
| Step | Value |
|---|---|
| Rise-time limit | 300 ns |
| Bus capacitance | 50 pF |
| Maximum pull-up | 300 ns ÷ (0.8473 × 50 pF) = 7,080 Ω |
The I2C spec also requires minimum current drive capability of 3 mA at 0.4 V LOW level for Standard/Fast-mode (UM10204 Table 10). With a 3.3 V supply:
| Step | Value |
|---|---|
| Available voltage across pull-up | 3.3 V - 0.4 V = 2.9 V |
| Allowed sink current | 3 mA |
| Minimum pull-up | 2.9 V ÷ 0.003 A = 967 Ω |
This gives a range of 967 Ω to 7,080 Ω for this 50 pF bus. The standard 4.7 kΩ falls well within this range, which is why it works for most short buses. With 100 pF bus capacitance, the maximum drops to about 3.54 kΩ, so use 2.2–3.3 kΩ.
This section:
30.16 Hands-On Lab: I2C Scanner
This section: Hands-On Lab: I2C Scanner — Objective: Find all I2C devices connected to your ESP32/Arduino.
Objective: Find all I2C devices connected to your ESP32/Arduino.
| Stage | Student action | Evidence to record |
|---|---|---|
| Baseline | Scan with no external sensor attached | No unexpected addresses, or only built-in board devices. |
| Add display | Connect SSD1306 OLED | New address appears at 0x3C or 0x3D. |
| Add sensor | Connect BME280/BMP280 | New address appears at 0x76 or 0x77. |
| Conflict test | Add a second device with the same address if available | Scanner still shows one address, but both devices may respond at once. |
| Fix | Change address pin or use an I2C multiplexer | Each device becomes uniquely selectable. |
Sample scan interpretation:
| Scanner output | Meaning | Next action |
|---|---|---|
0x3C, 0x76 | OLED and BME280 are both visible | Start the sensor/display application. |
Only 0x3C | Sensor not responding | Check BME280 power, SDA/SCL order, and address pin. |
| No addresses | Bus-level fault | Check pull-ups, ground, VCC, and whether SDA/SCL are swapped. |
30.17 Hands-On Lab: BME280 Temperature Sensor
This section: Hands-On Lab: BME280 Temperature Sensor — Objective: Read temperature from BME280 sensor via I2C.
Objective: Read temperature from BME280 sensor via I2C.
The lab reads one sensor over two wires, but the board offers more than two. Figure 30.8 shows which edge belongs to this lab.

The small metal-capped part near the centre of Figure 30.8 is the sensor itself; everything else on the red board exists to reach it. Look at the two edges. One carries just four pads: ground, 3.3 volts, and the SDA and SCL pair this lab uses. The opposite edge carries six, adding a separate clock, data in, data out and chip select, because the same part also speaks the four-wire bus covered elsewhere in this module. Choosing an edge is therefore choosing a protocol. Note too that the holes are bare. The board ships without headers, so soldering is a step the parts list has to include before any scan can succeed.
30.18 Continue to Part 2
This section: Continue to Part 2 — Continue with I2C: Bring-Up and Diagnosis.
Continue with I2C: Bring-Up and Diagnosis.
Find help
3 reviewed answers.
Where should I start in a module?
Open the module page from the sidebar to see its chapters in order. Use the module map to return to a topic you need.
Modules and pathsReviewed
What can I try when a project does not work?
Check the symptom, then work through the diagnostic steps. Keep the error message and the smallest example that reproduces it.
When you are stuckReviewed
How do interactive examples work?
Use the interactive guide to check how examples and simulations work before changing your project.
Interactive examples guideReviewed