2 Mobile Robot Kinematics and the Perception-Action Loop
More
Depth: Practitioner
Progress saves as you read. Mark sections complete as you go; your progress appears in the sidebar.
2.1 Overview: Close the Loop Before Choosing the Motion Model
A mobile robot does more than move. It senses itself and its surroundings, estimates what the readings mean, chooses an action, and checks what changed. Repeating those steps is the perception-action loop. Closing that loop lets the robot act on its own.
1. Perceive
Measure the robot and its environment.
2. Estimate
Turn measurements into a usable state.
3. Decide
Select a control action or planned motion.
4. Act
Drive the mechanism and change the world, but treat the command as the start of the next observation rather than the end of the calculation. Wheel torque, surface friction, load, and collision constraints can make actual motion differ from the requested motion. The next Perceive step must measure that difference so Estimate can correct the state and Decide can revise the command.
The loop can be organized in three increasingly stateful ways:
- A reactive controller maps current sensor readings directly to an action. It is fast, but it has no internal account of what happened before.
- A reactive controller with memory adds state variables or a filter. The action can depend on a history summarized into the current estimate.
- A deliberative controller predicts future states and plans a sequence of actions before committing to one.
These are architectural choices, not a ranking from bad to good. A collision reflex may need to be reactive even inside a robot whose route planner is deliberative.
2.1.1 Two Independent Sensor Axes
Robot sensors are classified along two different axes. Do not collapse them into one list.
Proprioceptive
Measures the robot's own body or internal state: motor speed, joint angle, or battery voltage.
Exteroceptive
Measures the environment around the robot: range, light intensity, or an observed object.
Passive
Receives ambient energy without deliberately illuminating the scene: a camera, microphone, or temperature probe.
Active
Emits energy and measures the response: ultrasonic ranging or an infrared proximity measurement.
A sensor can occupy one category on each axis. An active wheel encoder is proprioceptive because it measures the robot, while an active ultrasonic ranger is exteroceptive because it measures the environment. The hardware mechanism does not decide the information role by itself.
Three camera-driven examples show why the information role must be connected to an action. An AlphaDog-style quadruped uses visual and verbal commands while following people and carrying their gear across rugged terrain. A semi-humanoid companion combines cameras, other sensors, and a touchscreen to support reminders, suggestions, prompts, and scheduling. The JEROS aquatic swarm uses onboard cameras to detect jellyfish, then motors move surface robots toward the population-control task. In each case, “computer vision” names only the observation step; the engineering contract must still name what is detected, which decision follows, and which actuator or user workflow consumes it.
2.1.2 Degrees of Freedom and Controllability
A degree of freedom (DOF) is one independent coordinate needed to describe motion. A motor shaft controls one rotational DOF; a plotter carriage controls one translational DOF. A robot pose on a flat floor normally needs three coordinates, , even if the platform has only two independent motor commands.
That comparison produces the core classification:
- Holonomic: its motion constraints can be expressed as constraints on configuration; an omnidirectional base can command sideways planar motion directly.
- Non-holonomic: it has a velocity constraint that cannot be reduced to a configuration constraint. A differential-drive robot cannot slide sideways instantaneously, though it can reach a sideways position by driving and turning.
- Redundant: controllable DOF exceeds the task’s required DOF. More than one actuator combination can produce the requested task motion.
Uncertainty remains inside every class. Wheels slip, mechanisms carry slack, inexpensive circuits add sensor noise, and the world moves between observations. Kinematics describes the intended geometry; feedback is what keeps that geometry useful in reality.
2.2 Practitioner: Turn Wheel Speeds into a Motion Contract
For a differential-drive robot, let each wheel have radius , let the wheels be separated by axle length , and let their angular speeds be and . The mechanism turns two actuator inputs into two body-frame motion quantities:
↔ Scroll the equation horizontally to inspect both wheel-rate terms.
The average wheel speed gives forward velocity . The wheel-speed difference gives angular velocity . From those equations you can read three useful operating modes without memorizing a table:
- If both wheels turn forward at the same speed, and the robot drives straight.
- If the right wheel is faster, under the stated sign convention and the robot curves left.
- If the wheels turn at equal and opposite speeds, and the robot rotates in place.
In the robot’s body frame, the non-holonomic constraint is explicit:
The zero is load-bearing. It says the drive can create no instantaneous lateral velocity. A path planner may still move the robot to a point beside it, but only through a sequence of forward motion and turns.
2.2.1 Inverse Kinematics: Ask for Feasible Motion
Inverse kinematics runs the contract in the other direction. Given a feasible forward velocity and angular velocity , command:
↔ Scroll the equation horizontally to inspect both wheel commands.
Suppose , , , and . Then:
The right wheel must turn faster, which agrees with the intended positive turn. This sign-and-shape check catches command swaps before a numerical test does.
Motor control and robot motion narrated tour
Play silently with captions on provisional storyboard timing; narration audio is pending. Production pacing is independent of model time. Choose Reduced motion for a complete still at each beat.
Play the tour to open the workbench. Pause, replay a beat, or read the full transcript below. Situations the model cannot show use captions only and keep the existing frame.
Full transcript — Motor control and robot motion (8 beats)
B1 — Connected robot request
You are the engineer guiding a connected mobile robot along a planned route. Your Internet of Things application requests a forward curve, and staying on that route depends on how the wheels actually move. How does a motion request become wheel commands, then a physical response?
Model caption: Your connected robot must follow a planned forward curve. Wheel motion connects the request to the route.
B2 — Individual motor response
Kinematics connects wheel speeds to a robot's ideal motion. Inverse kinematics works backwards: start with the forward speed and turning rate you want, then calculate the wheel speeds to request. The motor simulator explores what happens when a command reaches an individual motor.
Model caption: Inverse kinematics turns requested robot motion into wheel-speed commands. The simulator explores an individual motor's response.
B3 — Robot geometry
Use the chapter's robot example. The wheels are zero point three zero metres apart. Request a forward speed of zero point four zero metres per second, with a turning rate of zero point eight zero radians per second.
Model caption: Chapter example: wheel radius 0.05 m; axle length 0.30 m; forward speed 0.40 m/s; turning rate 0.80 rad/s.
B4 — Left wheel calculation
First, multiply zero point eight by zero point three, giving zero point two four. Divide by two to get zero point one two. For the left wheel, subtract that from zero point four, leaving zero point two eight. Divide by the wheel radius, zero point zero five: five point six radians per second.
Model caption: Left wheel: 0.80 × 0.30 = 0.24; ÷ 2 = 0.12; 0.40 − 0.12 = 0.28; 0.28 ÷ 0.05 = 5.6 rad/s.
B5 — Right wheel calculation
For the right wheel, add zero point one two to zero point four, giving zero point five two. Divide by zero point zero five: ten point four radians per second. The faster right wheel gives the intended leftward curve with the chapter's choice of positive turning direction. Those are the wheel speeds your robot requests.
Model caption: Right wheel: 0.40 + 0.12 = 0.52; 0.52 ÷ 0.05 = 10.4 rad/s. Left: 5.6 rad/s. Faster right wheel gives the intended leftward curve.
B6 — Load and gradual response
In the motor simulator, increasing load slows the open loop motor, which has no feedback correction. Its modeled speed also rises gradually after a command. The chapter's closed loop lets the robot move briefly before measuring its new state. Comparing that state with the path leads to another command, connecting physical response to the next decision.
Model caption: The open-loop model slows under increased load and builds speed gradually after a command. Chapter closed loop: move briefly before measuring; compare the new state with the path to calculate the next command.
B7 — Shaft versus robot path
The misconception is that a spinning motor shaft already tells you the robot's path. The simulator models an individual motor's response. The robot calculation uses both wheel speeds and their geometry. Shaft motion supplies part of the story; the perception-action loop connects movement back to sensing and decisions.
Model caption: An individual shaft's motion does not determine the robot path. The robot model uses both wheel speeds and geometry; the perception-action loop returns movement to sensing and decisions.
B8 — Measured motion takeaway
Calculate the wheel commands, then let measured motion guide the next command.
Model caption: Calculate the wheel commands, then let measured motion guide the next command.
2.2.2 Open Loop or Closed Loop?
After a planner produces a path, the controller still has to follow it.
Open-loop path following
Replay precomputed commands without observing whether the robot remains on the path. The result depends on the model and disturbances staying as expected.
Closed-loop path following
Move briefly, observe the new state, compare it with the path, and recompute. Wheel slip, sensor error, and moving obstacles become evidence for the next command.
Closed loop is more robust because it makes model error visible. It does not make the sensor estimate perfect, nor does it guarantee a feasible replanned path. A production motion contract should therefore record the state estimate used, command limits, update rate, saturation behavior, and the safe response when perception becomes stale.
2.3 Under the Hood: Rotate Frames, Respect Constraints, Plan Curvature
Body-frame motion becomes world-frame motion by rotating the translational axes through heading :
↔ Scroll the equation horizontally to inspect the complete body-to-world mapping.
The inverse rotation gives and , but it does not erase the mechanism’s constraint. A commanded world velocity must still satisfy:
Check the earlier motion request at heading : , , and . Substitution gives , so the request satisfies the no-sideways-motion constraint.
That equation is why an apparently simple pose-error controller cannot independently command arbitrary and for a differential drive. The planner must produce a curve whose tangent follows the robot’s heading.
2.3.1 Goal Poses and Cubic Bezier Curves
A goal pose specifies both a destination and the heading required there. A cubic Bezier path offers one construction. Let be the current position and the goal. Choose positive control-point distances and and place the inner points along the current and goal headings:
The curve now leaves along the current orientation and arrives along the target orientation. Its curvature and a chosen forward-speed schedule together supply the turn-rate schedule. This does not automatically make every choice of and safe: curvature, wheel-speed, obstacle-clearance, and acceleration limits still have to be checked.
2.3.2 Compare Models by State and Control Rank
| Platform | Pose state | Control inputs | Key constraint |
|---|---|---|---|
| Differential drive | : 3 DOF | Forward and angular velocity: 2 controllable DOF | No instantaneous lateral velocity |
| Bicycle model | : 3 DOF | Speed $v$ and steering angle : 2 controllable DOF | couples turning to forward motion |
| Quadrotor | Position plus roll, pitch, yaw: 6 DOF | One body-force and three body-moment inputs: 4 controllable DOF | Translation and attitude are dynamically coupled |
Differential-drive and bicycle models have non-holonomic no-side-slip constraints. The quadrotor is underactuated: its four independent inputs cannot command all six pose coordinates independently at an instant. These are different limits on motion and actuation. Their equations differ because their mechanisms differ. Reusing a differential-drive controller on a bicycle or quadrotor is a model mismatch.
See why the tempting answer fails.
-
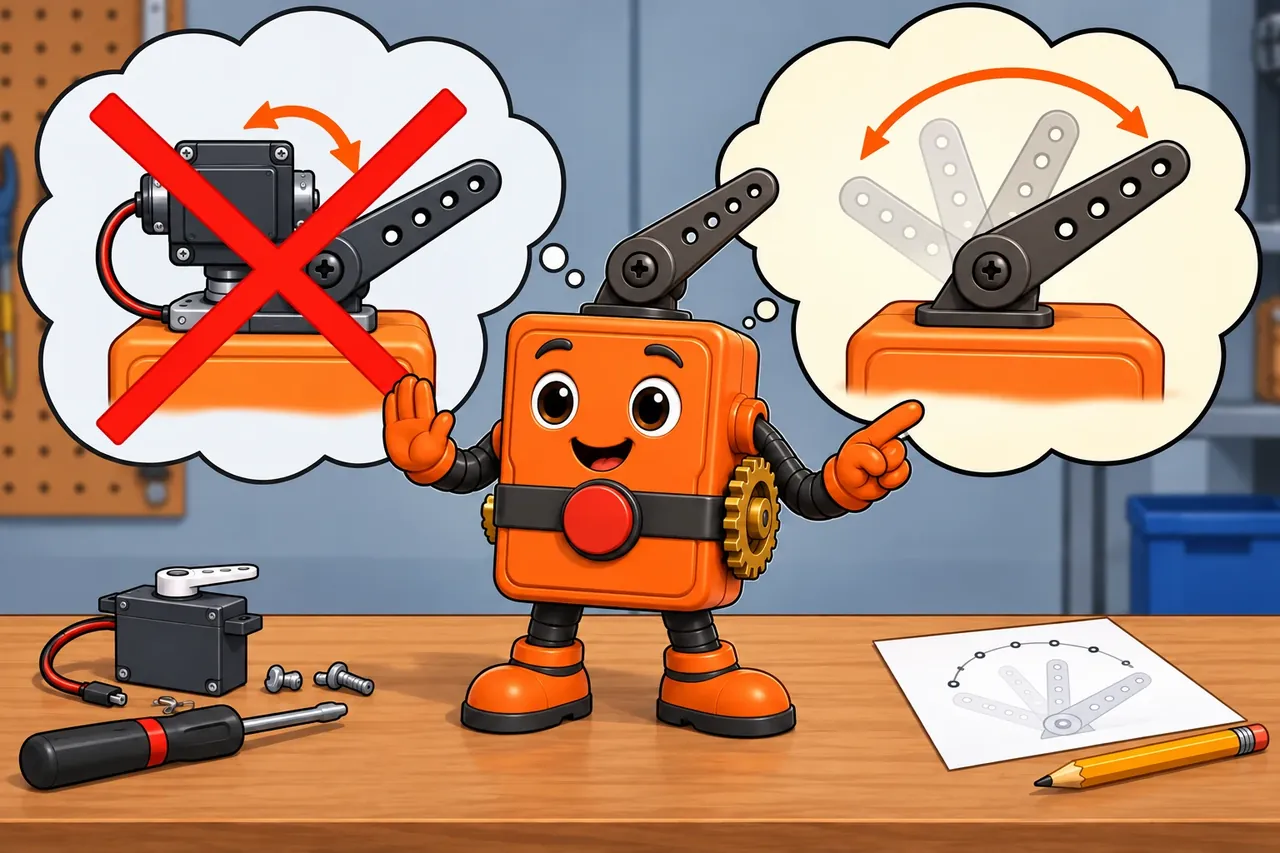
Wrong idea: planning a curved path adds an actuator. The crossed-out extra motor illustrates the mistake: a plan must work with the mechanism's existing controls.
The strip shows an arm and marks an extra motor with a cross. It warns against assuming that a plan adds a motor to the machine. A path is a proposed way to move; it does not change the controls already fitted to the robot. For a two-wheel robot, the plan must respect the limit on sideways motion. The robot can turn and then move along a curve, but it cannot slide sideways at once just because a path asks it to.
2.4 Summary
Follow a motion request around the loop. Sensors observe the robot and its surroundings. An estimate describes the state, and a decision selects a feasible motion. The actuators move the robot, which is then measured again. Kinematics links wheel speeds to ideal motion. Controllability tells us which motions can be commanded at once. Feedback shows where real motion differs from the model.
- The perception-action loop connects sensing, estimation, decision-making, and physical action.
- Proprioceptive/exteroceptive and passive/active are separate sensor-classification axes.
- A differential drive has three planar pose coordinates but only two independently controllable instantaneous motions.
- Forward kinematics predicts motion from wheel speeds; inverse kinematics maps feasible body motion back to wheel commands.
- Closed-loop following repeatedly measures and replans because kinematics alone cannot remove disturbance or uncertainty.
2.5 Key Takeaway
A mobile robot needs a motion model that reflects its limits.
State what the robot can measure and command, and which motions it cannot make. Use feedback to guide the next command.
2.6 See Also
Use the linked chapters to follow the contract in either direction. The actuator chapters move downward from body motion to mechanisms and motor commands; Braitenberg vehicles show a compact perception-to-action loop; UAV control shows how a different platform changes the feasible-motion model. The control-architecture chapter then moves upward from kinematics to the rules, behaviors, and plans that choose each command.
Chapter
Actuator Classifications
the practical actuator-selection framing that this chapter extends into full mobile-platform kinematics.
Chapter
Servo Motors
an arm-specific inverse-kinematics example that contrasts with mobile base motion.
Chapter
UAV Trajectory Control
quadrotor motion theory applied to flight-control practice.
Chapter
Classical Control Architectures for Mobile Robots
the next chapter’s taxonomy of how controllers turn estimates into behavior.