 Phoebe guides
A field team faces an unresolved physical question: Why √N averaging stops helping at the 1/f corner They must answer it before changing one over f corner frequency on the real device. Predict the direction first.
See the relationship before changing it
The chapter figure below shows: 1/f Noise Spectrum: The frequency domain view shows white noise (flat) and 1/f noise (rising at low frequencies) intersecting at the corner frequency. Below the corner, averaging becomes ineffective.
The retained audit below checks several chapter fixtures. This added model holds every other chapter fixture fixed, so the numeric fixture does not switch without explanation.
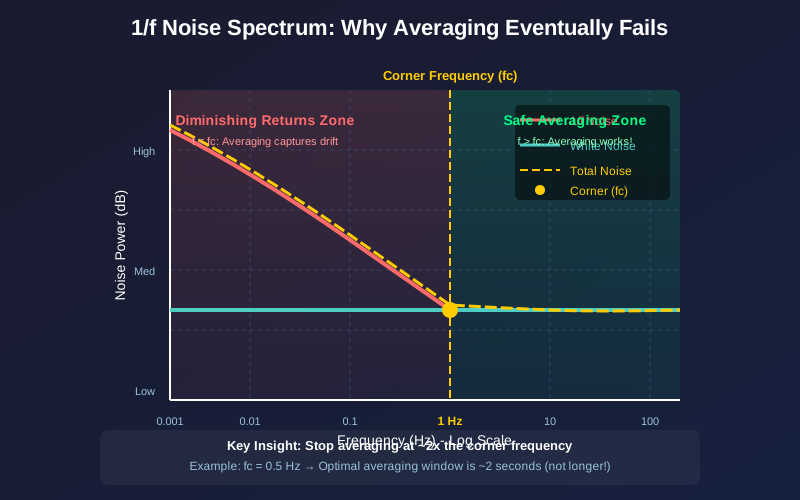
Derive the baseline in four named moves
- 1
Name the input. The chapter baseline for one over f corner frequency is 0.5.
- 2
Name the relationship. Tref=1/(2fc) (comparison only); white improvement=√N
- 3
Substitute the chapter fixture. Set one over f corner frequency to 0.5. The page ledger gives illustrative comparison time as 1.00 s.
- 4
Read the result. Keep s beside the value. Use it only inside the technical boundary on this page.
Predict, then change one over f corner frequency
Try Predict the direction of illustrative comparison time. Move one control, calculate, then check your prediction.
Observe Predict a decrease in illustrative comparison time as the input increases over this range. Reset to the chapter baseline and compare.
Explain Only one over f corner frequency moves here. The other chapter fixtures remain fixed.
Source: content/sensors/sensor-types-advanced.qmd — In 60 Seconds. Use the chapter equation and fixed ledger above; only the named input varies.
Check yourself
What should you do before trusting a moved-control result?
What does this small model leave out?
1. Ask what can cancel
Independent, zero-mean errors sometimes land high and sometimes low. Averaging lets those deviations partly cancel. Slow drift stays similar across neighbouring samples, so copying it into a longer average does not create independent evidence.
2. Derive the white-noise rule
One sampleVariance is σ².
Average N independent samplesThe summed variance is Nσ², then division by N² gives σ²/N.
Take the square rootσmean=σ/√N, so improvement=√N.
3. Connect time to frequency
A length-T average behaves as a low-pass operation with effective bandwidth near 1/(2T). The chapter's normalized 1/f spectrum equals the white floor S0 at fc:
4. Try the corner frequency
TryMove the 1/f corner and watch the comparison time change.
ObserveAt fc=0.5 Hz, Tref=1.00 s; a 100 Hz stream contributes 100 samples and ideal white-noise gain is 10.0×.
ExplainThe comparison time is not an averaging limit; √N describes only the independent white part. Measure noise versus averaging time for the actual chain.
The 1/(2T) bandwidth is an instructional approximation, and the chapter's 5×/6× saturation curve is illustrative rather than an integral of one measured PSD.
- a measured spectrum
- Needs separate evidence
- sample correlations
- Needs separate evidence
- alias filtering
- Needs separate evidence
- sensor drift
- Needs separate evidence
- event duration
- Needs separate evidence
- estimator response
- Needs separate evidence
- validation against held-out data
- Needs separate evidence
Use field evidence or a deeper model before release.
5. Rebuild the chapter's white column
Those results assume independent white samples. They do not promise the same improvement when low-frequency drift is present.
6. Work the MEMS range
The higher assumed corner makes this comparison time ten times shorter. It does not set an optimum; use measured noise versus averaging time for the actual chain.
7. Check yourself
Why does white-noise standard deviation fall as 1/√N?
What is the comparison time Tref at fc=0.5 Hz?
Does a 10× ideal white-noise gain guarantee 10× total improvement?
These are the chapter inputs, worked results, and named teaching assumptions.
- 3.16×
- Percentage, ratio, or gain
- 10.0×
- Percentage, ratio, or gain
- 31.6×
- Percentage, ratio, or gain
- 100× white-noise gains
- Time, interval, or service-life value
- 0.5 Hz corner
- Frequency, sample rate, or event rate
- 1.00 s window
- Time, interval, or service-life value
- 1–10 Hz MEMS range
- Frequency, sample rate, or event rate
- 0.500 s
- Time, interval, or service-life value
- 0.0500 s limits
- Time, interval, or service-life value
- warning about illustrative 5×/6× saturation come from the chapter
- Named teaching assumption
This page does not claim one rectangular-window approximation fully describes a real noise spectrum.