RFID, NFC & UWB · Study deck
UWB Indoor Positioning Systems
Ultra-wideband (UWB) is a radio method that uses very short signals to measure distance.
Radio Remi is your guide for this deck.

After studying this chapter
Learning objectives
You will be able to:
- Explain why anchor geometry and line-of-sight quality can matter more than nominal radio precision.
- Compare TWR, TDoA, and angle-assisted UWB architectures without treating any one mode as universally best.
- Use GDOP as an error-amplification signal rather than as a magic accuracy guarantee.
- Design a site survey that records anchor coordinates, visibility, obstruction classes, calibration evidence, and retest triggers.
Major section
Start With the Story
A dot on a map may look exact, yet a poor anchor layout or blocked path can place that dot on the wrong side of an aisle.
- When confidence falls, the safe response may be to warn, slow down, or ask for another source instead of guessing.
- One site test cannot promise the same result in every room or season.
- That claim depends on anchor placement, synchronization, geometry, line-of-sight quality, filtering, confidence, and how the application reacts when uncertainty grows.
Major section
Eddie's Math Bridge: Link Budget Before Geometry
The mathematical gist: The chapter's 30 m by 20 m floor has a 36.06 m diagonal.
- Geometry cannot amplify a range measurement that the anchor never detected.
- With -14.3 dBm total UWB EIRP, a 4.62 cm wavelength, and free-space exponent 2, that corner sees about 79.8 dB path loss and -94.1 dBm received power: 9.1 dB below the named -85 dBm sensitivity.
Major section
Position Estimates as Evidence
A UWB location estimate should be treated as an evidence record, not as the exact physical truth.
- The record should say what was measured, which assumptions were used, and how confident the engine is in the result.
- Applications should respond differently to high-confidence, low-latency estimates than to stale or low-confidence estimates.
- For example, an asset map can show a broad uncertainty area, while a robot safety workflow may require a recent estimate with enough visible anchors and a low residual before it acts.
Major section
Anchors Turn Ranges Into Coordinates
A UWB positioning system is a set of fixed anchors at known coordinates and mobile tags to be located.
- Ranging gives distances or arrival-time differences; the positioning system combines several of those measurements into an (x, y) or (x, y, z) estimate.
- The two big system questions are geometry and capacity.
- Geometry asks whether anchor placement gives the solver enough independent viewpoints.
- For an asset map, a broad low-confidence region may be acceptable.
Major section
Anchor Geometry and GDOP
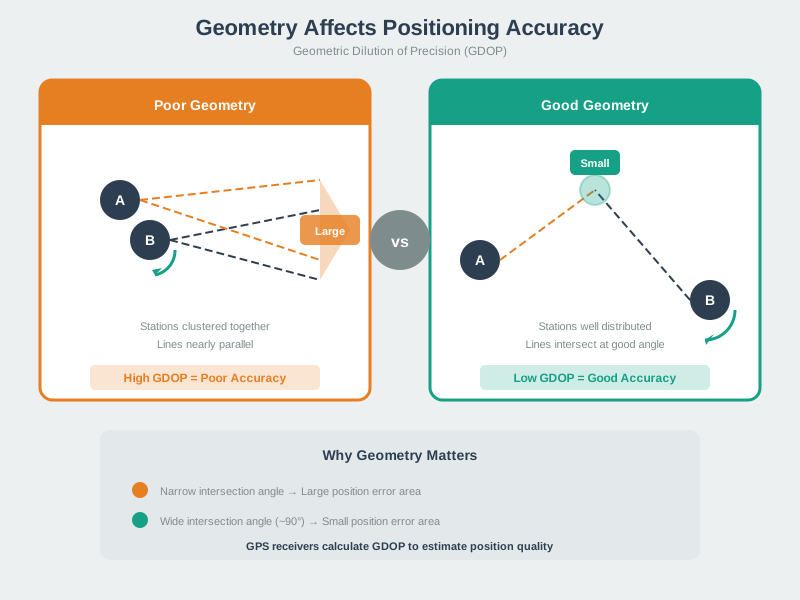
Anchor placement sets the shape of the positioning problem.
- Collinear or near-collinear anchors can make a small distance error appear as a large position error in the weak direction.
- When anchor stations cluster, their measurement lines are nearly parallel, so small range errors can move the estimated position greatly.
- A wider distribution gives intersecting lines at useful angles and reduces that geometric weakness.
Major section
Anchor Geometry and GDOP (continued)
The geometry factor is not the whole error budget, but it is a useful warning sign.
- If the geometry factor is high, improving firmware or filter settings may not fix the installation.
- A 30 m x 20 m work area might use anchors at known map coordinates and a tag mounted on a cart.
- GDOP does not predict every error; it warns when the installation makes small timing errors expensive.
Major section
Measurement Quality Pipeline
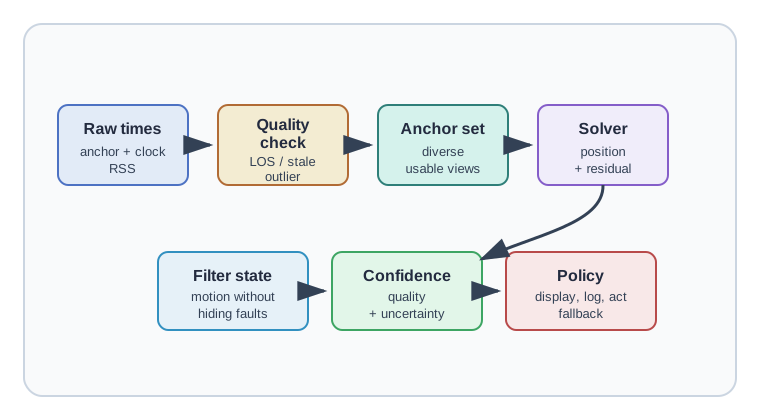
Raw times need an anchor and clock record.
- The solver produces a position and residual; a motion filter can smooth the state but should not conceal faults.
- A coordinate without that evidence can lead an application to act on a weak fix.
- A coordinate without quality fields is not enough for automation or safety decisions.
Major section
Architecture Choices
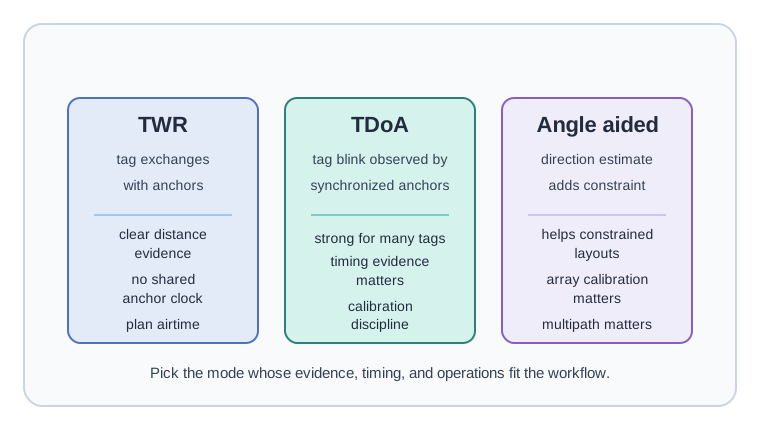
Two-way ranging gives a tag-to-anchor distance without a shared anchor clock, but repeated exchanges consume airtime as tags and anchors grow.
- TDoA observes a tag blink at synchronized anchors and depends on their timing and calibration.
- A theoretical method advantage is not a measured position result.
- TWR positioning uses message exchanges between a tag and anchors.
Major section
Architecture Choices (continued)
The trade-off is that tags and anchors spend airtime on each exchange, so update rate and tag count must be planned.
- TDoA positioning lets a tag transmit a short blink observed by synchronized anchors.
- The trade-off is that anchor timing, cabling or timing distribution, calibration, and timestamp quality become part of the position evidence.
- Angle-assisted positioning adds direction estimates from antenna arrays or phase information.
Major section
Capacity Often Picks the Positioning Method
The reason large deployments often favor TDoA over TWR is channel airtime.
- In TWR, every position needs a back-and-forth exchange between the tag and each anchor, so airtime scales with tags x anchors x update rate.
- In TDoA, a tag transmits one blink and synchronized anchors listen, so one short transmission can support the fix.
- The tradeoff is that anchor synchronization, timestamp quality, and calibration become release-critical evidence.
Major section
Capacity Often Picks the Positioning Method (continued)
If 200 tags need a 1 Hz update, the system must budget about 200 tag reports per second before retries, management frames, and rejected observations.
- If the workflow can accept 0.2 Hz for slow-moving assets, the load drops to 200 x 0.2 = 40 reports per second.
- That change may decide whether TDoA blinks are sufficient, whether TWR exchanges are practical only for a smaller tool fleet, or whether the project needs smaller zones with different update policies.
- A simple review estimate is 0.15 x 2.5 + 0.20 + 0.10 = 0.675 m.
Major section
Selection Workflow: Site Survey and Deployment Process
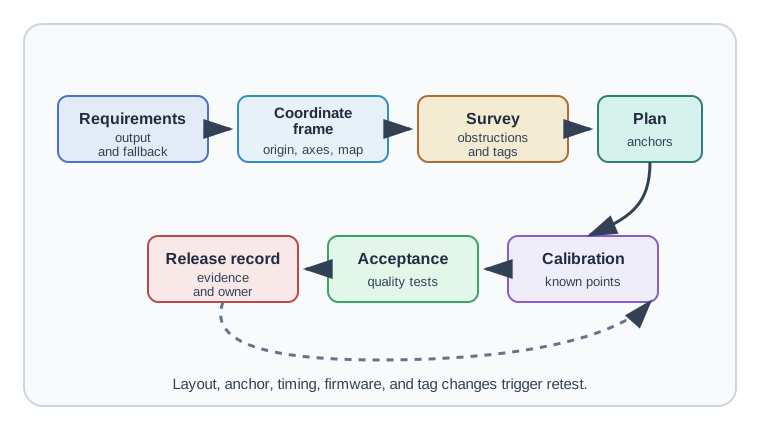
A site survey should produce an installable coordinate system and an evidence trail.
- Anchors must ring the work area, see its edges, and form a sound shape before tuning.
- Tests at known points and on moving paths set the pass limit.
- The release pack names proof and owner for good, weak, and fallback states.
Major section
Common Review Failures
Treating accuracy as a fixed product property: Position quality changes with geometry, line-of-sight, mounting, timing, update rate, and filtering.
- Optimizing the center and ignoring edges: Edges, corners, doorways, lifts, racks, and vehicle paths often have weaker geometry than the open middle of a room.
- Hiding NLOS with smoothing: Filters can make bad data look stable.
- Forgetting the coordinate frame: A precise tag estimate is useless if the anchor map, floor level, axis direction, or application map is misaligned.
Deck summary
Key takeaways
A dot on a map may look exact, yet a poor anchor layout or blocked path can place that dot on the wrong side of an aisle.
- The mathematical gist: The chapter's 30 m by 20 m floor has a 36.06 m diagonal.
- A UWB location estimate should be treated as an evidence record, not as the exact physical truth.
- A UWB positioning system is a set of fixed anchors at known coordinates and mobile tags to be located.
- Anchor placement sets the shape of the positioning problem.
Retrieval practice
Recall check 1 of 3

Radio Remi says: answer from memory, then check your reasoning.
Q1Why is UWB positioning not simply 'indoor GPS'?
Show answer
Answer: D UWB estimates position from timed radio observations, anchor geometry, and clock quality with explicit confidence, unlike satellite GPS.
Retrieval practice
Recall check 2 of 3
Radio Remi says: answer from memory, then check your reasoning.
Q2A UWB system has six anchors, but all of them are mounted along one long wall of a warehouse. Tags near the opposite side produce unstable depth estimates even when several anchors are visible. What is the best diagnosis?
Show answer
Answer: D Anchors on one wall do not surround the tag, so the solver has poor leverage for depth.
Retrieval practice
Recall check 3 of 3
Radio Remi says: answer from memory, then check your reasoning.
Q3A warehouse must locate thousands of asset tags with modest update rates and long tag battery life. Which positioning approach fits, and what is the deciding factor?
Show answer
Answer: D s single-blink, listen-at-all-anchors model minimizes per-tag airtime and energy, so it scales to many tags.
Print reference
Answers
Answer key.
- D · UWB estimates position from timed radio observations, anchor geometry, and clock quality with explicit confidence, unlike satellite GPS.
- D · Anchors on one wall do not surround the tag, so the solver has poor leverage for depth.
- D · s single-blink, listen-at-all-anchors model minimizes per-tag airtime and energy, so it scales to many tags.