IoT Fundamentals · Study deck
Sensor Linearization Methods
Picture a water tank whose level sensor is correct near empty and near full but bends through the middle.
Physics Phoebe is your guide for this deck.

After studying this chapter
Learning objectives
You will be able to:
- Explain: A better workflow is to collect reference points across the shipping range, fit a Steinhart-Hart equation or a lookup table, then compare the converted temperatures against held-out reference readings.
- Explain: The loop in Figure: Validation uses independent holdout points and range guards checks holdout residuals after the fit; notice why a range failure calls for new evidence or a simpler model.
- Explain: The ADC code may change quickly near freezing and slowly at warmer temperatures, so a single slope can make the freezer end look acceptable while the room-temperature end drifts.
Major section
In 60 Seconds
A smooth conversion can still give the wrong depth where the pump decision matters.
- An analog-to-digital converter is a part that turns a changing electrical signal into numbered steps.
- This trial does not prove every sensor or fitting method.
- Linearization turns a curved sensor response into physical units, but it must not hide uncertainty.
Major section
Start With the Story
You will choose a sensor correction method and check where calibration evidence supports its use.
- The mathematical gist: A 90 s excursion is a transient, not a single 0.0111 Hz tone: a 200 s sampling interval can miss it altogether.
Major section
Turn a Curved Response Into Correct Units
Many sensors do not produce an output that is proportional to what they measure.
- A thermistor's resistance, for example, changes steeply and nonlinearly as temperature changes.
- Linearization is the step that converts that curved raw response into the correct physical units.
- Linearization is that conversion for a sensor.
Major section
Turn a Curved Response Into Correct Units (continued)
If the held-out residuals are still larger than the product's tolerance, the display should not imply more accuracy than the calibration proves.
- The pointer still moves, but not evenly, so you need a conversion that knows the spring's curve to read true weight.
- Making the numbers come out smooth is not the same as making them accurate.
- If this gives you the core principle, you can stop here.
Major section
Turn a Curved Response Into Correct Units (continued)
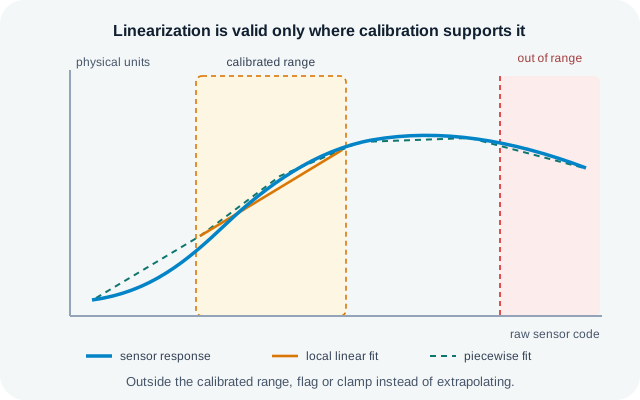
The calibrated region bounds the supported correction; values beyond it need a flag or clamp instead of extrapolation.
- The ADC code may change quickly near freezing and slowly at warmer temperatures, so a single slope can make the freezer end look acceptable while the room-temperature end drifts.
- A better workflow is to collect reference points across the shipping range, fit a Steinhart-Hart equation or a lookup table, then compare the converted temperatures against held-out reference readings.
- Beginner ExamplesA nearly linear sensor over a small range may need only a straight-line fit with an offset and a slope.
Major section
Apply It: Choose a Method From the Evidence
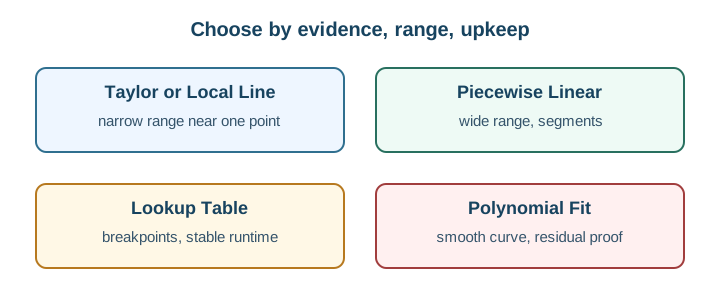
The practical job is to choose the simplest linearization method whose residuals meet the accuracy target within the device's limits, then prove it on held-out data and protect against out-of-range inputs.
- The sensor runs in a narrow band near a known point.
- Error grows quickly away from that point.
Major section
Apply It: Choose a Method From the Evidence (continued)
Memory use and table density set accuracy.
- One smooth equation fit to calibration data.
- The model and its coefficients are trustworthy.
- Piecewise segments can follow moderate curvature; a lookup table trades memory for a fast, repeatable conversion.
- A polynomial gives one smooth equation but can overfit.
Major section
Apply It: Choose a Method From the Evidence (continued)
Small scattered residuals support the fit; a pattern or out-of-range input calls for more points, another method, or a narrower claim.
- Segments extend coverage, tables provide fixed breakpoints, and polynomial fits need residual checks.
- Quantify nonlinearity and range: A nearly straight, narrow-range sensor needs far less than a steeply curved, wide-range one.
- Piecewise-linear, denser where curvature is high.
Major section
Apply It: Choose a Method From the Evidence (continued)
Guard the range and validate at release: Clamp or flag inputs outside the calibrated range, and re-validate against references before shipping and after any sensor or firmware change.
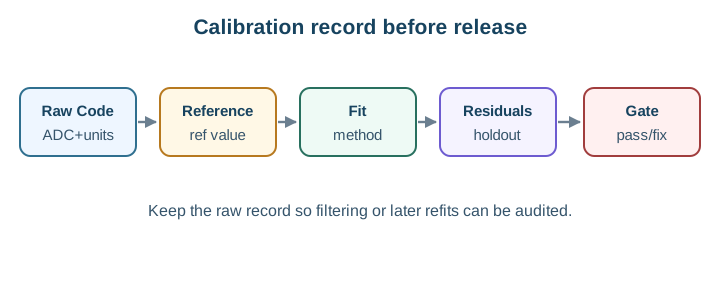
- The record in Figure: A releaseable conversion keeps the raw code keeps raw codes and fit proof together; check the release gate.
- The sequence makes A releaseable conversion keeps the raw code, reference value, fit choice, residuals, and gate decision together auditable for: Walkthrough: From Sensor Curve to Validated Conversion.
- Incremental PracticeBeginner For a near-linear sensor over a small range, justify using a simple slope-and-offset fit.
Major section
Under the Hood: How Each Method Fails
Local (Taylor) LinearizationA local linearization keeps the first-order term of a series expanded around an operating point, which is the local slope, and discards the rest.
- Those discarded higher-order terms are the error, and they grow roughly with the square of the distance from the expansion point.

Major section
Under the Hood: How Each Method Fails (continued)
Polynomial Fit and OverfittingA polynomial of degree n has n + 1 coefficients and can pass exactly through n + 1 points.
- Passing through the points is not accuracy.
- Prefer the lowest degree whose held-out residuals are acceptable.
- The error inside a segment depends on the curve's bend and the segment width.
Major section
Under the Hood: How Each Method Fails (continued)
Residual AnalysisResiduals are the differences between the model and held-out calibration points.
- High-degree fits, especially with equally spaced calibration points, can swing far above and below the true curve between the points, a behavior known as the Runge phenomenon, and they diverge quickly outside the calibrated range.
- Accuracy is therefore bought with more breakpoints or table entries, which costs memory.
- If the reference is uncertain, every converted value inherits that uncertainty.
Major section
Under the Hood: How Each Method Fails (continued)
Piecewise-Linear and Lookup TablesBoth approximate the curve with straight segments, and a lookup table is essentially a piecewise-linear model stored as data.
- Small, randomly scattered residuals suggest a good fit, while a systematic pattern, such as a consistent smile or trend, means the model is missing real structure.
- Residuals measured on the same points used to fit understate the true error, so always check against points the model did not see.
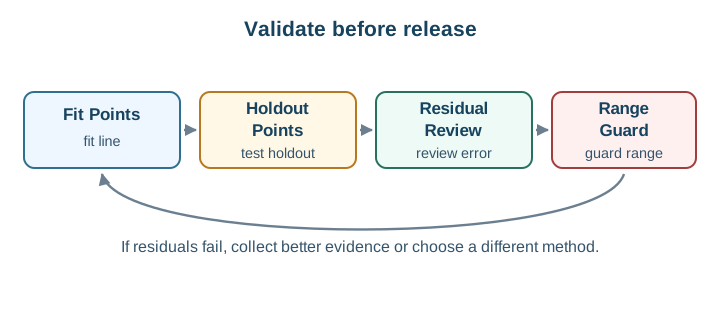
- The loop in Figure: Validation uses independent holdout points and range guards tests the fit on held-out points; revise it if they fail.
Major section
Under the Hood: How Each Method Fails (continued)
Common PitfallsEquating fit with accuracy: Passing through every calibration point can be overfitting, not correctness.
- The loop in Figure: Validation uses independent holdout points and range guards checks holdout residuals after the fit; notice why a range failure calls for new evidence or a simpler model.
- Extrapolation Is UnboundedEvery method is valid only inside the calibrated range.
- Reporting more precision than the calibration supports: The converted value cannot beat its reference.
Major section
Under the Hood: How Each Method Fails (continued)
Outside it, polynomial terms explode and tables have no data, so out-of-range inputs must be clamped or flagged rather than silently converted into confident, wrong numbers.
- Raising polynomial degree to chase residuals: It can oscillate and worsen accuracy between and beyond the points.
- Extrapolating beyond the calibrated range: Error there is unknown and can be large.
- At this depth, linearization is a trade among model flexibility, compute, memory, and honesty about uncertainty.
Deck summary
Key takeaways
A smooth conversion can still give the wrong depth where the pump decision matters.
- You will choose a sensor correction method and check where calibration evidence supports its use.
- Many sensors do not produce an output that is proportional to what they measure.
- If the held-out residuals are still larger than the product's tolerance, the display should not imply more accuracy than the calibration proves.
- The calibrated region bounds the supported correction; values beyond it need a flag or clamp instead of extrapolation.
Retrieval practice
Recall check 1 of 3

Physics Phoebe says: answer from memory, then check your reasoning.
Q1A converted temperature is displayed to six decimal places and looks very smooth. What does that tell you about its accuracy?
Show answer
Answer: C Numeric precision and visual smoothness are not the same as measurement accuracy.
Retrieval practice
Recall check 2 of 3
Physics Phoebe says: answer from memory, then check your reasoning.
Q2A steeply nonlinear sensor must be converted quickly on a small microcontroller with little spare compute but some free memory, across a wide range. Which method is the most reasonable starting point?
Show answer
Answer: D A table converts quickly with little compute and follows the curve as densely as memory allows, giving repeatable conversion across the range.
Retrieval practice
Recall check 3 of 3
Physics Phoebe says: answer from memory, then check your reasoning.
Q3A high-degree polynomial passes through all the calibration points exactly, but between them it swings far from the true curve, and outside the range it diverges. What modeling problem is happening?
Show answer
Answer: B The data fits, but a too-flexible model oscillates between points and diverges outside the range.
Print reference
Answers
Answer key.
- C · Numeric precision and visual smoothness are not the same as measurement accuracy.
- D · A table converts quickly with little compute and follows the curve as densely as memory allows, giving repeatable conversion across the range.
- B · The data fits, but a too-flexible model oscillates between points and diverges outside the range.