Sensors & Measurement · Study deck

Sensor Fusion and Kalman Filtering

Picture a strain sensor on a bridge.

Physics Phoebe is your guide for this deck.

sensortypes
iotclass.org

After studying this chapter

Learning objectives

You will be able to:

  • Identify 1/f noise in sensor data and explain why it limits long-term averaging effectiveness
  • Design multi-sensor fusion architectures that outperform individual sensors
  • Implement Kalman filtering algorithms for optimal state estimation
  • Construct robust sensing systems with error handling, redundancy, and watchdog recovery for production deployment
iotclass.org

Major section

Start With the Measurement Story

Its reading changes with load, but also with heat, age, mounting stress, and small random effects.

  • A clean number on a screen can hide those very different causes.
  • Combining sensors can expose faults, yet it can also combine shared errors.
  • An advanced method is useful only when its limit is visible.
iotclass.org

Major section

Field Sensors Fail Differently

Maria, an agricultural IoT engineer, was frustrated.

  • Her soil moisture sensors worked perfectly in the lab---readings were stable, accurate, and repeatable.
  • The solution wasn't more averaging---it was smarter signal processing and combining multiple sensors together.
  • This chapter takes you on the journey from lab-perfect sensors to field-reliable systems.
iotclass.org

Major section

In 60 Seconds

Advanced sensor topics include 1/f noise (which limits long-term averaging effectiveness), multi-sensor fusion (combining GPS, Wi-Fi, barometer, and IMU for better positioning), and Kalman filtering (optimally blending predictions with measurements).

  • Production sensor systems need robust error handling, redundancy, watchdog timers, and traceable calibration.
  • An approximate window to inspect is T≈1/(2fcorner)T\approx1/(2f_{corner})T≈1/(2fcorner​), or about 1 s for this chain's 0.5 Hz 1/f corner.
  • For an ideal white-plus-flicker model, the Allan-deviation minimum is nearer 0.36/fcorner0.36/f_{corner}0.36/fcorner​ (about 0.7 s here), showing that 1 s is a heuristic rather than an exact optimum.
iotclass.org

Major section

Part 1: The 1/f Noise Problem

You've probably learned that averaging reduces noise.

  • This works beautifully for "white noise"---the random fluctuations that are equally likely at any frequency.
  • But here's what the textbooks often skip: not all noise is white noise.
  • And here's the frustrating part: when you average over longer windows, you're actually capturing more of this low-frequency drift, not averaging it away.
iotclass.org

Major section

Part 1: The 1/f Noise Problem (continued)

Below it, flicker noise increasingly contributes; the corner alone does not say exactly when averaging stops helping.

  • Its power increases at lower frequencies, which means slow, wandering drift dominates over long time periods.
  • The impact is counterintuitive: short-term averaging works exactly as expected (10 samples gives you ~3× improvement), but long-term averaging hits a wall.
  • Know when to stop averaging: Check your sensor's datasheet for the 1/f corner frequency.
iotclass.org

Major section

Optional High-Pass Filter Pattern
This moves your signal above the 1/f corner frequency where noise is well-behaved.

  • The 1/f noise, being correlated between samples, largely cancels out.
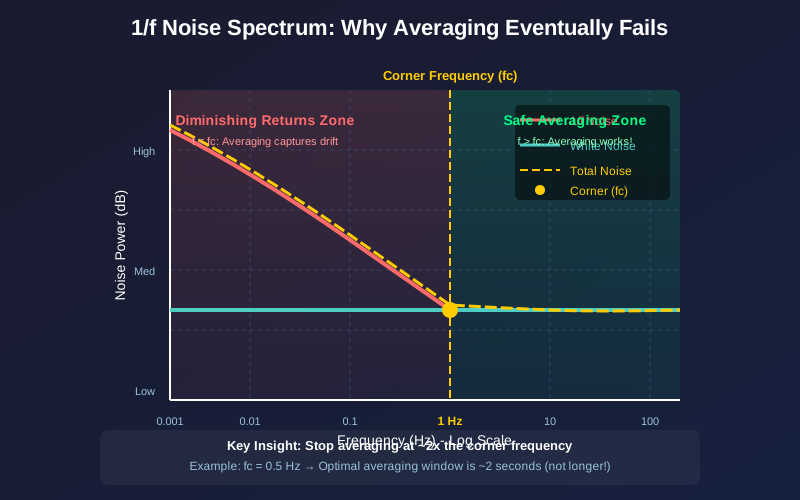
  • The plot separates frequency-independent white noise from the low-frequency rise associated with flicker noise.
  • To decide whether averaging can improve a slow sensor, inspect the 1/f Noise Spectrum: The frequency domain view shows white noise (flat) and 1/f noise (rising at low frequencies) intersecting at the corner frequency. Below the corner, averaging becomes ineffective diagram in the frequency domain first.
  • Longer averaging suppresses independent noise but eventually encounters drift-like low-frequency behaviour, connecting the spectrum to the need for calibration or high-pass treatment.
1/f Noise Spectrum: The frequency domain view shows white noise (flat) and 1/f noise (rising at low frequencies) intersecting at the corner frequency. Below the corner, averaging becomes ineffective.
iotclass.org

Major section

When One Sensor Is Not Enough

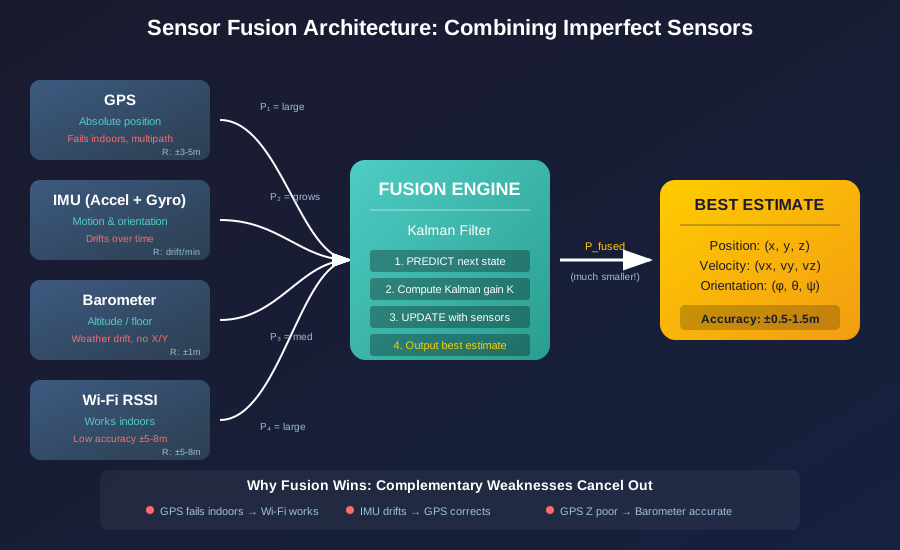
Each sensor has complementary weaknesses.

  • GPS drifts indoors where Wi-Fi works.
  • Accelerometers drift over time where GPS provides corrections.
  • The insight: Instead of trying to build a perfect single sensor (impossible), combine imperfect sensors that fail in different ways.
  • Each witness sees a different angle of the same event.
iotclass.org

Major section

Fusion Rule of Thumb

The route connects redundancy to improved observability while preserving the need to reject correlated faults and biased inputs.

  • The key is figuring out the right weights---how much to trust each sensor at each moment.
Sensor Fusion Architecture: Multiple sensors with complementary strengths feed into a Kalman filter fusion engine, producing a best estimate more accurate than any individual sensor.
iotclass.org

Major section

MEMS Sensor Implementation Chain

Miniaturisation does not remove the measurement chain; it packs the chain into fewer packages and makes power-domain timing more important.

  • The wake sequence is causal.
  • For a simple 1 ms active, 1 s sleep schedule, use charge rather than averaging currents by eye.
  • If IaI_aIa​ is active current, IsI_sIs​ is sleep current, ta=1 mst_a=1\ \text{ms}ta​=1 ms, and ts=1 st_s=1\ \text{s}ts​=1 s, then.

Why it matters

The: ACTIVE · 1 ms overlay is credible only if reference settling, sensor warm-up, radio startup, acknowledgement, and retry work fit inside it; otherwise the apparent sleep ratio hides real energy.

A miniature sensor node converts a transducer signal through bias, analog conditioning, ADC, MCU, and radio under a one-second sleep and one-millisecond active schedule.
iotclass.org

Major section

Miniaturisation Limits Before Actuation

Smaller force sensors gain integration and may gain resonant frequency, but the signal and every noise mechanism do not scale together.

  • A spring mode stores mean energy on the order of kBTk_BTkB​T, giving an RMS displacement.
  • The mechanical transfer function turns that force into displacement, and the readout adds roughly size-independent amplifier, reference, and quantisation noise.
  • Consequently, shrinking geometry does not guarantee a quieter force estimate.
Large and small force sensors compare thermal displacement, surface effects, and fixed electronics noise before a measured command drives an actuator.
iotclass.org

Deck summary

Key takeaways

Its reading changes with load, but also with heat, age, mounting stress, and small random effects.

  • Maria, an agricultural IoT engineer, was frustrated.
  • Advanced sensor topics include 1/f noise (which limits long-term averaging effectiveness), multi-sensor fusion (combining GPS, Wi-Fi, barometer, and IMU for better positioning), and Kalman filtering (optimally blending predictions with measurements).
  • You've probably learned that averaging reduces noise.
  • Below it, flicker noise increasingly contributes; the corner alone does not say exactly when averaging stops helping.
iotclass.org

Retrieval practice

Recall check 1 of 3

Physics Phoebe says: answer from memory, then check your reasoning.

Q1Among the four illustrative 1/f corner values in this chapter's table, which is highest?

AGas sensor (0.01 Hz)
BThermistor (0.1-1 Hz)
CMEMS accelerometer (1-10 Hz)
DPhotodiode (100-1000 Hz)
Show answer

Answer: D The table's assumed corners, low to high, are gas, thermistor, MEMS accelerometer, and photodiode chains.

Q2This chapter lists four mitigation strategies for 1/f noise. Which one works by periodically reversing the sensor's polarity or bias, then subtracting alternate readings to move the signal above the 1/f corner frequency?

AHigh-pass filtering
BCorrelated double sampling
CKnow when to stop averaging
DChopping/modulation
Show answer

Answer: D see answers page

iotclass.org

Retrieval practice

Recall check 2 of 3

Physics Phoebe says: answer from memory, then check your reasoning.

Q3A measurement chain has a measured 1/f noise corner at 0.5 Hz. You average 100 samples over 10 seconds. What limitation should you check?

ANot enough samples - need 1000 for good averaging
BLow-frequency flicker noise may limit the average's improvement
CToo many samples - noise increases with sample count
DThis is optimal - 10 seconds is perfect for noise reduction
Show answer

Answer: B see answers page

iotclass.org

Retrieval practice

Recall check 3 of 3

Physics Phoebe says: answer from memory, then check your reasoning.

Q4Per this chapter's Single-Sensor Problem table, which limitation does GPS have that Wi-Fi RSSI specifically compensates for?

AGPS integrates motion and drifts over time; Wi-Fi never has any positioning drift.
BGPS fails near metal; Wi-Fi radio readings are immune to that interference.
CGPS struggles indoors and in urban canyons; Wi-Fi RSSI provides a weaker indoor location cue.
DGPS cannot show altitude; Wi-Fi RSSI provides precise floor-by-floor height.
Show answer

Answer: C The table pairs GPS's weakness ('Doesn't work indoors; multipath in urban canyons') against Wi-Fi RSSI's strength ('Works indoors'), illustrating the chapter's complementary-weakness pattern that motivates sensor fusion.

iotclass.org

Print reference

Answers 1 of 3

Answer key.

  1. D · The table's assumed corners, low to high, are gas, thermistor, MEMS accelerometer, and photodiode chains.
  2. D · The chapter's four mitigation strategies are: know the corner frequency and stop averaging in time, high-pass filter out low frequencies, chop/modulate by reversing polarity and subtracting alternate readings, and correlated double sampling by subtracting two differently-excited measurements.
iotclass.org

Print reference

Answers 2 of 3

Answer key.

  1. B · The 1/f corner identifies equal flicker and white-noise spectral densities at 0.5 Hz. A 10-second average may not follow the independent white-noise sqrt(N) rule. The approximate 1/(2 × corner) heuristic gives about 1 second to inspect, but the best window must be measured for this chain and application.
iotclass.org

Print reference

Answers 3 of 3

Answer key.

  1. C · The table pairs GPS's weakness ('Doesn't work indoors; multipath in urban canyons') against Wi-Fi RSSI's strength ('Works indoors'), illustrating the chapter's complementary-weakness pattern that motivates sensor fusion.
iotclass.org