Sensors & Measurement · Study deck
Sensor Noise and Averaging Limits
Picture a light sensor whose value jumps beside a motor.
Physics Phoebe is your guide for this deck.
After studying this chapter
Learning objectives
You will be able to:
- Identify thermal, flicker, and ADC quantization noise in sensor front-ends.
- Estimate whether front-end noise, ADC step size, sensor tolerance, or environment dominates the error budget.
- Explain why averaging improves white noise but not slow drift or fixed bias.
- Choose between averaging, bandwidth limiting, shielding, grounding, reference checks, and calibration.
Major section
Start With the Measurement Story
Averaging may calm the display while hiding the real cause.
- The team must learn whether the change is random noise, drift, interference, or a fixed error.
- Bandwidth means the range of change a measurement path can follow.
- Signal-to-noise ratio means the useful signal level compared with the noise level.
Major section
After Sensor Lab Best Practices
Sensor Lab Best Practices teaches the defensive workflow: validate readings, filter noise, fuse sensors, monitor health, and use hysteresis.
- This page explains when those safeguards work and when they only hide the wrong failure mode.
- If variation is random and fast, bandwidth limiting and averaging can help.
- If the value drifts, moves with supply voltage, changes with placement, or disagrees by a fixed offset, the answer is evidence, calibration, or hardware cleanup rather than more samples.
Try it: After Sensor Lab Best Practices in the chapter
Major section
Overview: Every Reading Comes With Noise
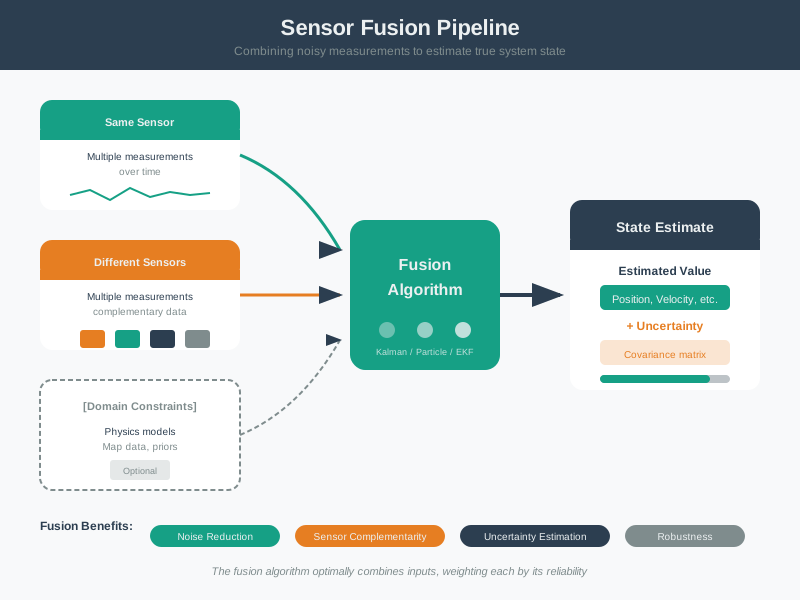
The lab log must keep the test conditions, raw values, and uncertainty needed to show why the result deserves trust.
- Noise management begins by deciding what independent information is available, not by choosing an averaging window.
- Same Sensor means more samples over time: Different Sensors add another kind of evidence.
- That pair is the key lesson.
Major section
Overview: Every Reading Comes With Noise (continued)
These inputs reduce doubt in different ways.
- A smooth number can still be wrong.
- The mathematical gist: A 12-bit ADC over 3.3 V has a 0.8057 mV code step and a uniformly distributed rounding floor of q/12=232.6 μV RMS.
- Bits reduce quantisation; they do not remove reference noise, sensor tolerance, drift, or aliasing.
Major section
Quantify Noise and Averaging
A front end contains several noise sources, and their units must agree before they can be combined.
- The next workbench makes the front-end crossover visible instead of leaving it as separate equations.
- Shot noise is a current-noise process associated with discrete charge crossing a junction.
- At low frequency, junctions and FETs can add flicker noise.
Major section
Quantify Noise and Averaging (continued)
Change only the upper band edge from 1010 Hz to 110 Hz: the shaded band contracts, SNR improves, and quantization becomes the larger remaining floor—but the converter itself remains exactly 16 bit.
- so the amplitude density is in,shot=2qIDC A/Hz.
- The square root matters: 2qIDC is a power density, not an amplitude density.
- A common empirical form is the Hooge relation.
Major section
Quantify Noise and Averaging (continued)
An amplifier voltage-noise density en(f) is already in volts per square-root hertz.
- Its current-noise density in(f) becomes a voltage through source impedance Zs(f), while a source resistance contributes Johnson noise 4kTR.
- Mechanical thermal noise belongs at the transducer input and is converted through the sensor sensitivity before it joins this voltage budget.
- SNR describes random-noise separation over a stated bandwidth; it is not the whole accuracy claim.
Major section
Quantify Noise and Averaging (continued)
Aliased out-of-band noise must be limited by an analog filter; a digital average cannot undo noise already folded into baseband.
- Flicker noise is different: in many semiconductor and resistive devices its measured voltage noise grows with the DC voltage across the device and rises as frequency falls.
- This dimensional form is safer than memorising a transcription with a stray resistance term.
- Across unrelated parts, however, resistance alone cannot predict N or αH; the datasheet or a measured spectrum must supply the device-specific evidence.
Deck summary
Key takeaways
Averaging may calm the display while hiding the real cause.
- Sensor Lab Best Practices teaches the defensive workflow: validate readings, filter noise, fuse sensors, monitor health, and use hysteresis.
- The lab log must keep the test conditions, raw values, and uncertainty needed to show why the result deserves trust.
- These inputs reduce doubt in different ways.
- A front end contains several noise sources, and their units must agree before they can be combined.
Retrieval practice
Recall check 1 of 5

Physics Phoebe says: answer from memory, then check your reasoning.
Q1A stable reference shows fast random jitter; another sensor has a fixed offset; a third changes when a motor starts. Which remedy plan fits?
Show answer
Answer: B Correct: the three symptoms have different causes and need different remedies.
Retrieval practice
Recall check 2 of 5

Physics Phoebe says: answer from memory, then check your reasoning.
Q2A sensor report shows only a smooth final reading. What should the lab record add before using it for an alert?
Show answer
Answer: A Correct: these show the signal, its conditions, and how much trust the result deserves.
Retrieval practice
Recall check 3 of 5

Physics Phoebe says: answer from memory, then check your reasoning.
Q3Which three noise sources fundamentally limit a typical sensor front-end?
Show answer
Answer: D Thermal noise, flicker noise, and quantization noise set the practical front-end noise floor, and each responds to different fixes.
Retrieval practice
Recall check 4 of 5

Physics Phoebe says: answer from memory, then check your reasoning.
Q4Averaging 4 independent samples of a white-noise-limited reading improves SNR by how much, and by what mechanism?
Show answer
Answer: B sqrt(4) = 2, which is 20·log10(2) ≈ 6 dB, matching 3 dB for each of the two doublings.
Retrieval practice
Recall check 5 of 5

Physics Phoebe says: answer from memory, then check your reasoning.
Q5A near-DC measurement is limited by 1/f (flicker) noise and slow thermal drift. Why does averaging thousands of samples give disappointing improvement?
Show answer
Answer: A Averaging needs independent samples; low-frequency noise and drift behave like a wandering baseline rather than independent hiss.
Print reference
Answers 1 of 2
Answer key.
- B · Correct: the three symptoms have different causes and need different remedies.
- A · Correct: these show the signal, its conditions, and how much trust the result deserves.
- D · Thermal noise, flicker noise, and quantization noise set the practical front-end noise floor, and each responds to different fixes.
- B · sqrt(4) = 2, which is 20·log10(2) ≈ 6 dB, matching 3 dB for each of the two doublings.
Print reference
Answers 2 of 2
Answer key.
- A · Averaging needs independent samples; low-frequency noise and drift behave like a wandering baseline rather than independent hiss.
