IoT Interfaces, Location and Privacy · Study deck

Location Awareness: Technology Tradeoffs

A hospital tag and a delivery truck need different ways to find their place.

UX Uma is your guide for this deck.

locationawareness
iotclass.org

After studying this chapter

Learning objectives

You will be able to:

  • Explain: UWB uses radio timing for tighter ranging; an anchor is a fixed site point used as a reference. Figure: Select GPS splits low-cost room or present/absent hints from a tight range.
  • Explain: In Figure: Architecture diagram showing location service components with privacy, begin with the heterogeneous signal sources, follow them into the location engine, then inspect the services that consume its estimate.
  • Explain: That connects the beginner example to the chapter's running claim: a location estimate should drive automation only when its source, age, confidence, and consequence are understood.
  • Explain: Location data is sensitive.
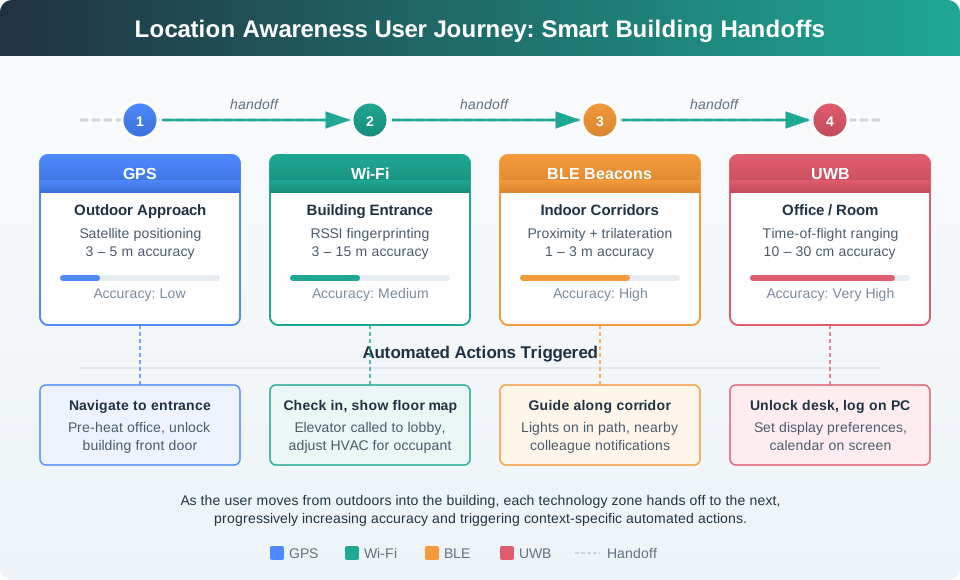
Location Awareness User Journey: Following a person through a smart building showing technology handoffs (GPS to Wi-Fi to BLE to UWB) and automated actions triggered at each stage.
iotclass.org

Major section

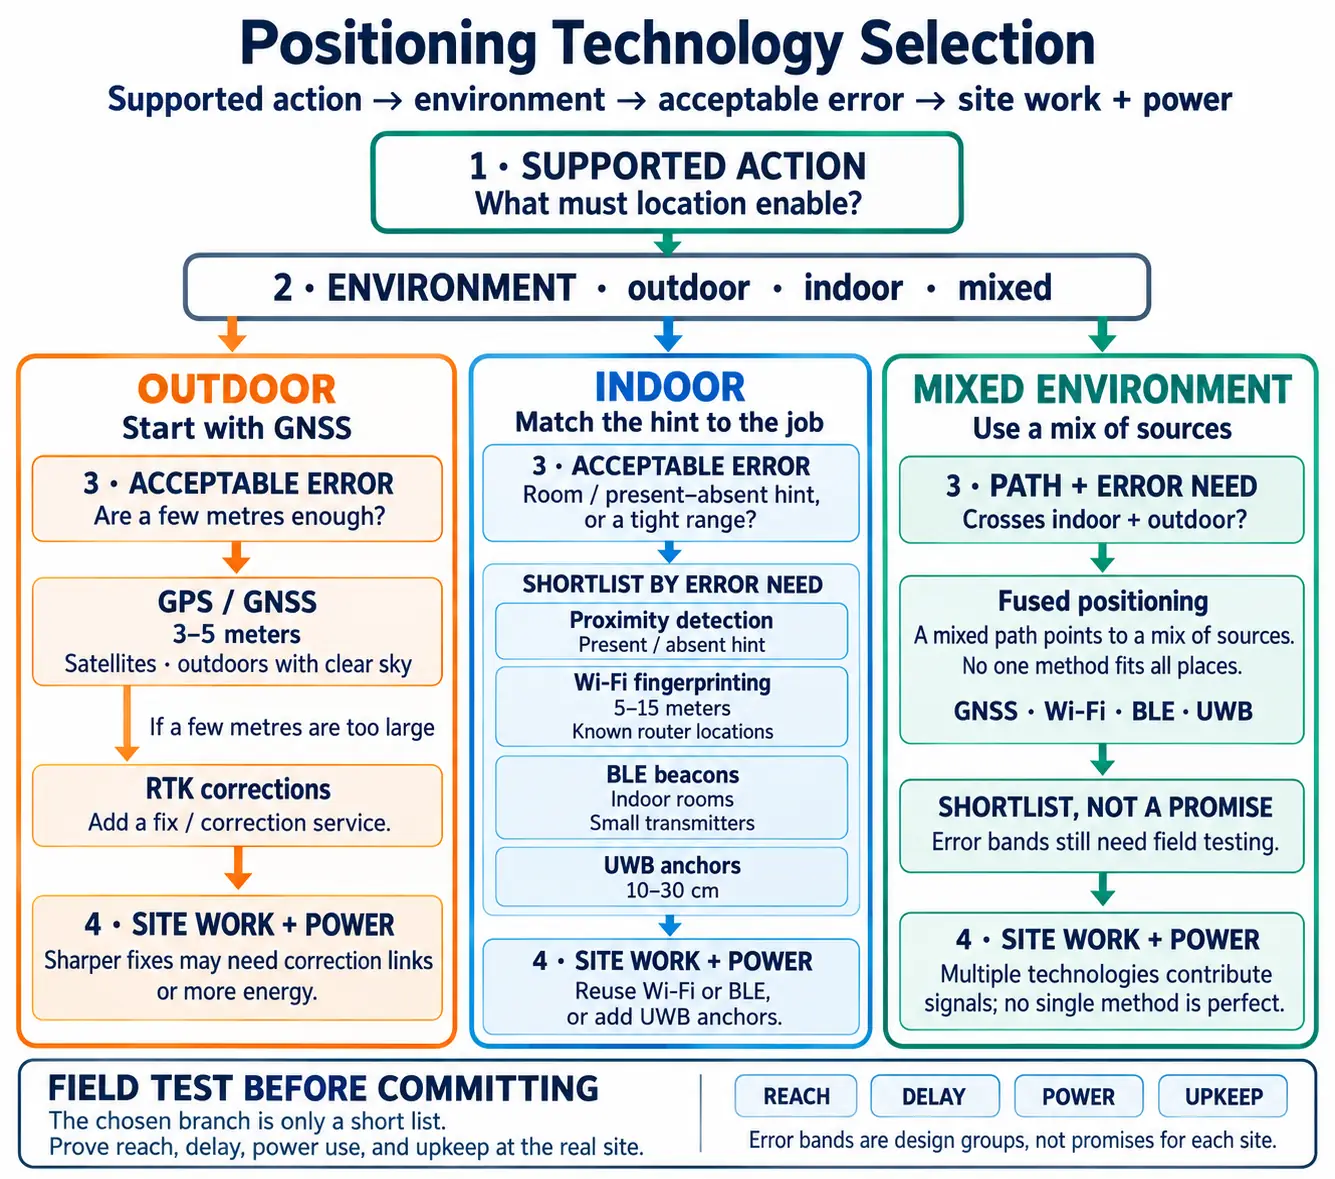
Positioning Tech Decision Tree

GNSS uses satellite signals to estimate an outdoor position.

  • BLE is Bluetooth Low Energy, a short-range radio option.
  • UWB uses radio timing for tighter ranging; an anchor is a fixed site point used as a reference. Figure: Select GPS splits low-cost room or present/absent hints from a tight range.
  • Cell identity gives a broad area.

Key terms

Location data
Location data is sensitive.
Decision tree for selecting positioning technology based on environment, accuracy needs, and infrastructure constraints
Select GPS, RTK, Wi-Fi fingerprinting, BLE beacons, UWB anchors, proximity detection, or fused positioning from the supported decision, operating environment, acceptable error, and maintainable infrastructure.
iotclass.org

Major section

Positioning Tech Decision Tree (continued)
The chosen branch is only a short list.

  • The outdoor path starts with GNSS, then adds a fix service when an error of a few metres is too large.
  • The indoor path asks whether the site can reuse Wi-Fi or BLE, or must add UWB anchors.
  • Location data is sensitive.
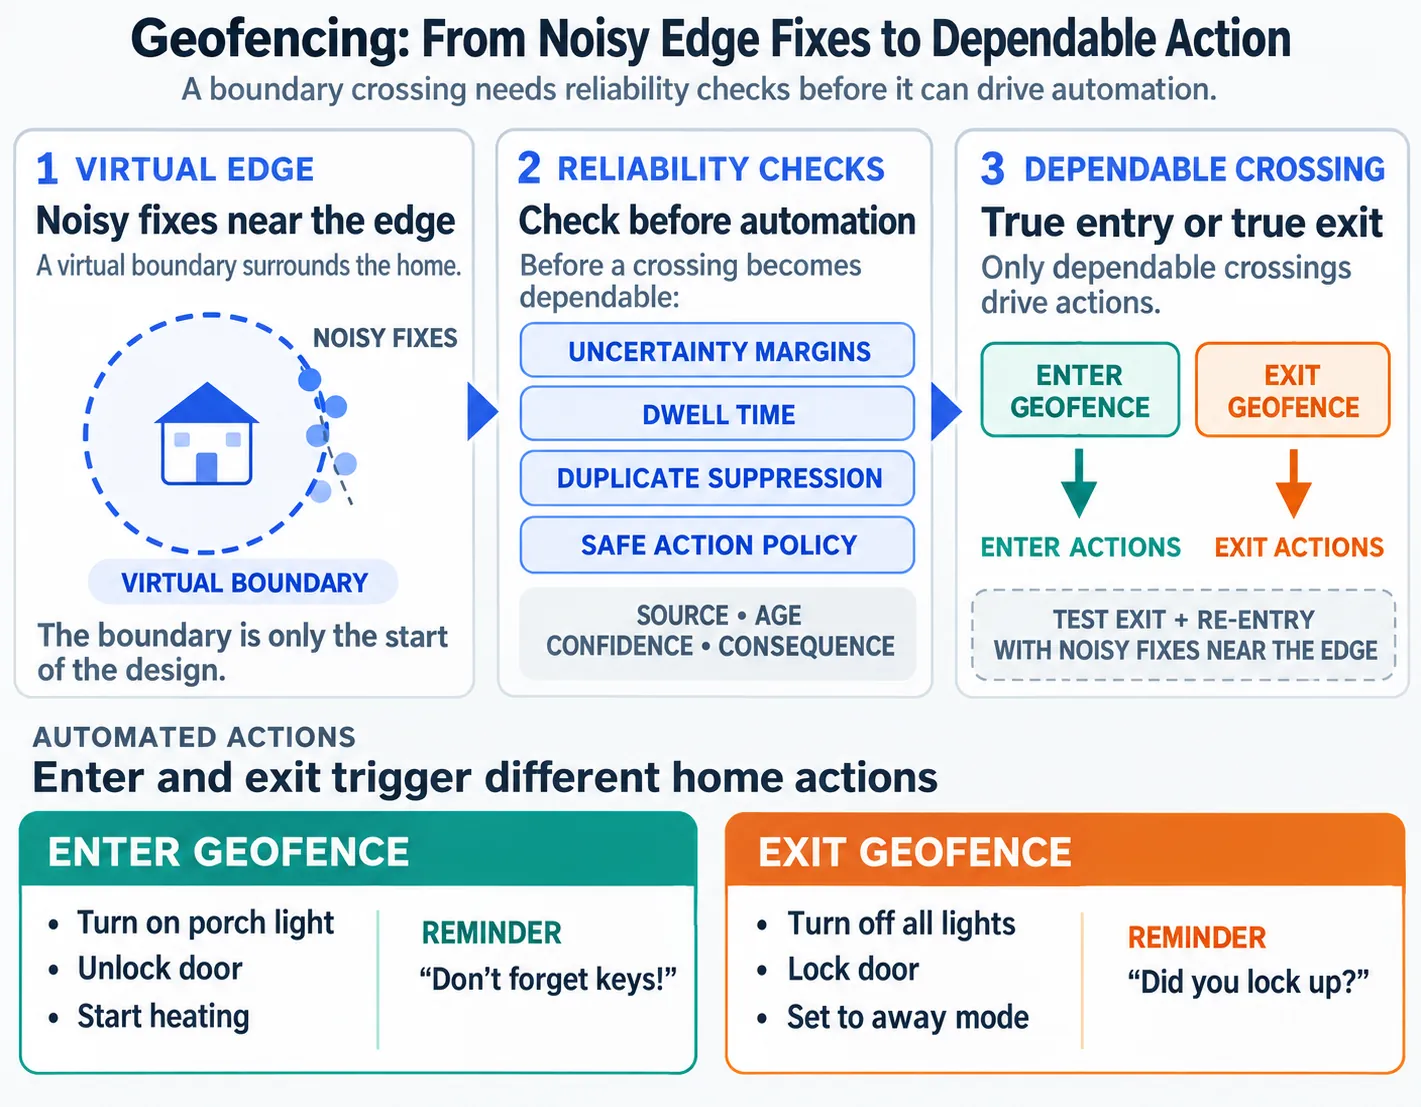
Geofencing diagram showing virtual boundary around a home with enter and exit triggers for automated actions
Diagram illustrating geofencing: a virtual boundary around a home location with automated triggers when user enters or exits.
iotclass.org

Major section

Positioning Tech Decision Tree (continued)

A path that crosses both spaces points to a mix of sources; no one method fits all places.

  • Field tests must still prove its reach, delay, power use, and upkeep at the real site.
  • GNSS gives an outdoor point with a clear sky, while UWB can give a tight local range when its anchors are kept in place.
  • Figure: Diagram illustrating geofencing shows why the boundary is only the start of the design.
Geofencing diagram showing virtual boundary around a home with enter and exit triggers for automated actions
Diagram illustrating geofencing: a virtual boundary around a home location with automated triggers when user enters or exits.
iotclass.org

Major section

Positioning Tech Decision Tree (continued)

The tree can narrow the options, but only a field test can show that the chosen error band holds in the real building or outdoor path.

  • The system must add uncertainty margins, dwell time, duplicate suppression, and a safe action policy before a crossing becomes dependable.
  • That connects the beginner example to the chapter's running claim: a location estimate should drive automation only when its source, age, confidence, and consequence are understood.
  • Exit and re-entry tests should cover noisy fixes near the edge.
Geofencing diagram showing virtual boundary around a home with enter and exit triggers for automated actions
Diagram illustrating geofencing: a virtual boundary around a home location with automated triggers when user enters or exits.
iotclass.org

Major section

For Kids: Meet the Sensor Squad!

The Human GPS Game: This game shows how GPS uses multiple satellites to find your location!

  • Location Awareness is like having a magic treasure map that always knows where you are!: Imagine you have a special map that follows you wherever you go.
  • "I know!" said Temperature Terry. "We can use LOCATION AWARENESS!
  • Each person measures how many "giant steps" away you are from them and says it out loud:.
iotclass.org

Major section

Introduction

Device mobility is fundamentally about moving through space, so localisation is at the core of many mobile services and applications.

  • The dashed circles are ranges inferred from signal strength, not exact distances.
  • Combining three beacons gives an approximate fix, with roughly 3–5 m accuracy to test in the building.
  • The acts by code come after those handoffs.

Why it matters

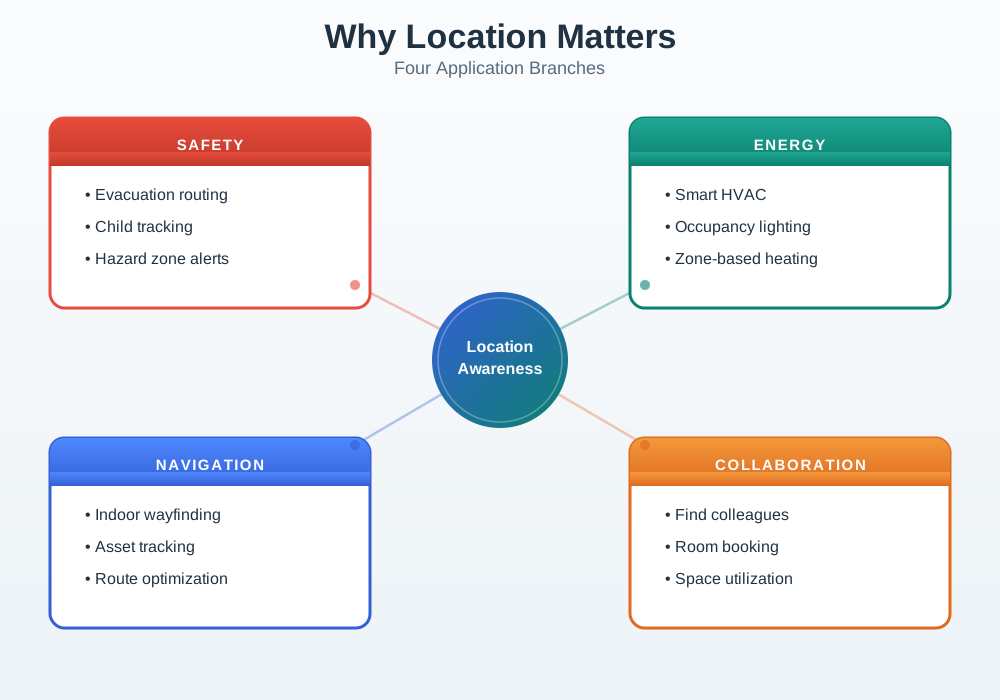
The right-hand actions—protect people, reduce energy, guide movement, and coordinate resources—depend on what that error band permits.

Three BLE beacon ranges yield an approximate indoor fix with metre-scale uncertainty, then connect that estimate to safety, energy, navigation and coordination decisions.
iotclass.org

Major section

Introduction (continued)

A product should use the estimate only at a precision the field test supports.

  • That order shows the main point: the service must keep the level of trust and note when its source changes.
  • A smooth line on screen does not mean that each point is just as exact.
  • Every handoff needs its own fallback and pass rule.
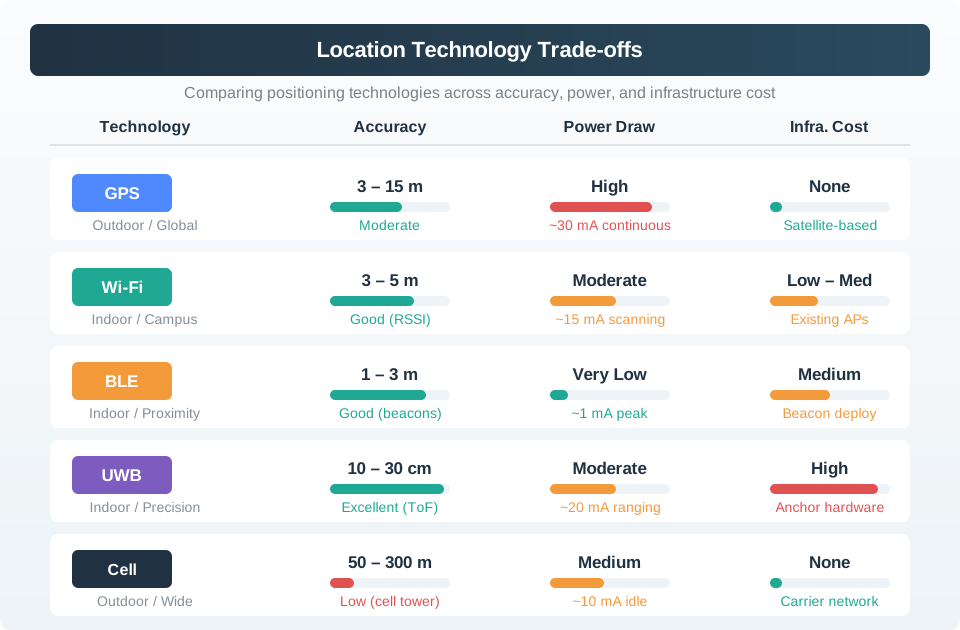
Location-accuracy decision record starts with an action, allowed error, confidence, update interval, cost, and recovery path, then compares cellular, Wi-Fi, BLE, and other signals against field evidence before approval.
iotclass.org

Major section

Introduction (continued)

The journey now needs a system boundary.

  • In Figure: Architecture diagram showing location service components with privacy, begin with the heterogeneous signal sources, follow them into the location engine, then inspect the services that consume its estimate.
  • That boundary lets navigation, safety, geofencing, and analytics share one quality-aware estimate while retaining consent and retention rules.
  • Methods that sharpen a position can require anchors, surveys, correction links, or more energy; low-infrastructure choices may return only a coarse zone.
Location-accuracy decision record starts with an action, allowed error, confidence, update interval, cost, and recovery path, then compares cellular, Wi-Fi, BLE, and other signals against field evidence before approval.
iotclass.org

Major section

Introduction (continued)

Architecture alone does not choose a sensor, so Figure: Location-accuracy decision record starts with an action next compares what each candidate demands from the product.

  • Those coupled costs complete the architecture story by showing why the engine needs multiple sources and why applications must declare the accuracy they truly require.
  • Collaboration: "Where is X?", "Is Y in yet?".
  • The right-hand actions—protect people, reduce energy, guide movement, and coordinate resources—depend on what that error band permits.
Location-accuracy decision record starts with an action, allowed error, confidence, update interval, cost, and recovery path, then compares cellular, Wi-Fi, BLE, and other signals against field evidence before approval.
iotclass.org

Deck summary

Key takeaways

GNSS uses satellite signals to estimate an outdoor position.

  • The chosen branch is only a short list.
  • A path that crosses both spaces points to a mix of sources; no one method fits all places.
  • The tree can narrow the options, but only a field test can show that the chosen error band holds in the real building or outdoor path.
  • The Human GPS Game: This game shows how GPS uses multiple satellites to find your location!
iotclass.org

Retrieval practice

Recall check 1 of 2

UX Uma says: answer from memory, then check your reasoning.

Q1A designer is comparing BLE and UWB for an indoor service. What should precede the technology choice?

AThe supported action, acceptable error, and infrastructure limits
BChoose the outdoor branch because satellite positioning provides usable fixes inside this building.
CA universal method independent of the service route
DThe technology with the smallest advertised error alone
Show answer

Answer: A The decision tree starts from environment and accuracy before accepting infrastructure and power consequences.

iotclass.org

Retrieval practice

Recall check 2 of 2

UX Uma says: answer from memory, then check your reasoning.

Q2A BLE estimate varies when reflected signals change the measured RSSI. What should the team infer?

ARadio variation contributes to uncertain distance estimates
BA radio specification replaces calibration in the building
CRSSI gives the same precision as a wideband timing measurement
DExtra decimal places remove the physical uncertainty
Show answer

Answer: A The chapter connects RSSI variation and multipath with distance uncertainty.

iotclass.org

Print reference

Answers

Answer key.

  1. A · The decision tree starts from environment and accuracy before accepting infrastructure and power consequences.
  2. A · The chapter connects RSSI variation and multipath with distance uncertainty.
iotclass.org