IoT Interfaces, Location and Privacy · Study deck
Indoor Positioning: BLE Beacons and Ranging
This first route explains why indoor positioning differs from GPS, the satellite-based location system.
UX Uma is your guide for this deck.
After studying this chapter
Learning objectives
You will be able to:
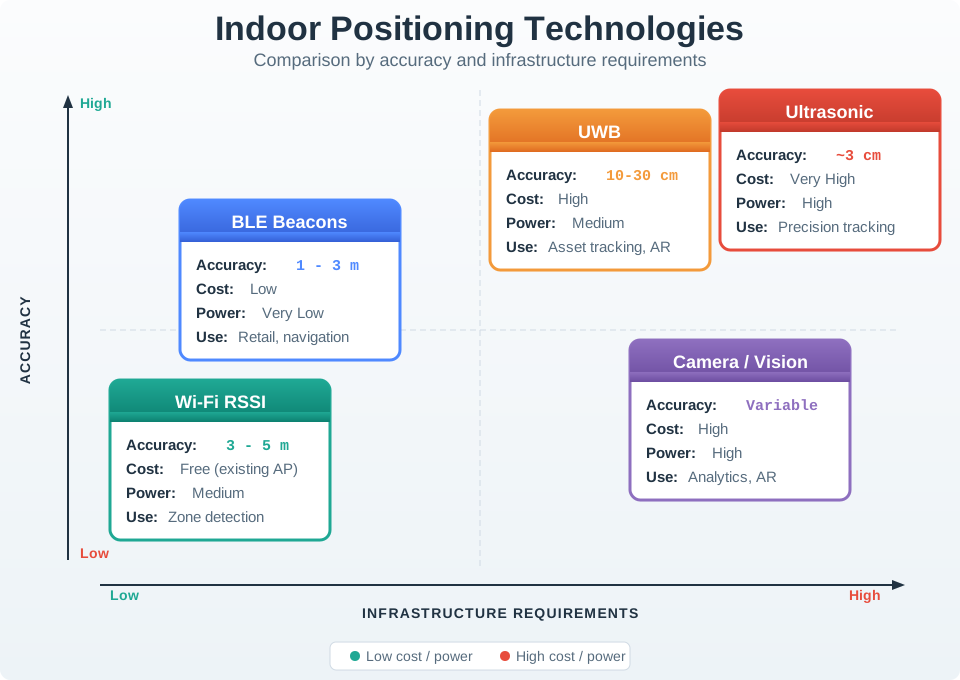
- Compare Indoor Positioning Technologies: Evaluate Wi-Fi, BLE, UWB, and ultrasonic systems for accuracy and cost
- Apply Trilateration Calculations: Compute position estimates from beacon distance measurements
- Design Sensor Fusion Systems: Combine GPS, Wi-Fi, BLE, and IMU for seamless indoor-outdoor transitions
- Troubleshoot Multipath Effects: Identify and mitigate RF interference in indoor environments
Major section
Overview · Start Simple
This first route explains why indoor positioning differs from GPS, the satellite-based location system.
- It then uses Bluetooth Low Energy (BLE) beacons, short-range radio transmitters, to estimate distance.
- That estimate is called ranging.
- The calibrated case uses measurements at known site points to tune and check the estimate.
- Each needs installed points and a measured site model.
Major section
In 60 Seconds · Indoor Positioning Basics
Satellite positioning is often unreliable indoors, so test alternatives at the site.
- BLE beacons and existing Wi-Fi can support room or zone estimates; UWB and ultrasonic systems may support tighter ranging with suitable anchors and geometry.
- GPS does not work indoors -- building walls attenuate satellite signals by 20-40 dB, making them too weak to use.
- Real-world systems combine multiple technologies with sensor fusion to provide seamless positioning as you walk from outdoors to indoors.
Major section
Indoor Place in Building Models · Checkpoint: Indoor Place Model
Indoor positioning is rarely about latitude and longitude.
- The useful answer is usually a building, floor, room, aisle, doorway, dock, bed bay, exhibit, or safe walking route.
- A simple application taxonomy keeps the old localization vocabulary connected to product decisions.
- Represent the answer at the level the application can defend.
Major section
Match Tech to Indoor Jobs · Indoor Accuracy Needs Infrastructure
Wi-Fi fingerprinting can reuse access points but drifts when the building changes.
- BLE proximity, Wi-Fi fingerprinting, Wi-Fi RTT, UWB ranging, ultrasonic beacons, QR/NFC check-in, camera/vision, powerline fingerprinting, active floors, barometers, and IMU dead reckoning each fail differently.
- Different estimators fail for different mathematical reasons.
- Triangulation uses angles.
Major section
Why Indoor Positioning is Different · Indoor Positioning Technologies
UWB needs anchors for tighter position estimates, while ultrasonic systems need their own sensors.
- Satellite signals are extremely weak (~10^-16 watts received).
- This requires alternative technologies designed for indoor environments.
- Walls, device placement, and update interval can change whether the estimate is useful for the product action.
Major section
BLE Beacon Positioning · Phoebe's Field Notes: Why RSSI Ranging Needs Calibration
The simple exchange in Figure: BLE iBeacons for Indoor Positioning shows what a BLE beacon broadcasts and what a receiver observes.
- That observation establishes proximity evidence, not a precise position by itself.
- The application still has to compare signals, know where beacons are installed, and decide what action the estimate can support.
- A weak or missing broadcast should lead to an uncertain state rather than a silently confident location.
Major section
BLE Beacon Retail Trilateration · Checkpoint: BLE Ranging
The positioning system uses trilateration from RSSI measurements to estimate shopper location.
- Solving these approximate circles gives a position near (1.5, 0.8) m.
- RSSI uncertainty changes each estimated range; quantify position error with calibrated site measurements before reporting a confidence bound or room assignment.
- Key Insight: BLE trilateration depends on path-loss calibration.
Deck summary
Key takeaways
This first route explains why indoor positioning differs from GPS, the satellite-based location system.
- Satellite positioning is often unreliable indoors, so test alternatives at the site.
- Indoor positioning is rarely about latitude and longitude.
- Wi-Fi fingerprinting can reuse access points but drifts when the building changes.
- UWB needs anchors for tighter position estimates, while ultrasonic systems need their own sensors.
Retrieval practice
Recall check 1 of 2

UX Uma says: answer from memory, then check your reasoning.
Q1A nurse searches for a cart and the location estimate spans more than one room. What should the system communicate?
Show answer
Answer: D The example prefers an honest bounded estimate to a precise-looking wrong room.
Retrieval practice
Recall check 2 of 2

UX Uma says: answer from memory, then check your reasoning.
Q2A hospital needs positioning as users move from outdoors to indoors. Which approach matches the chapter’s account?
Show answer
Answer: A The chapter describes mixed systems to bridge the indoor and outdoor paths.
Q3Three beacons sit at A (0, 0) m, B (8, 0) m, and C (0, 6) m. A calibrated range estimate is 5 m from each. Which position fits all three ranges?
Show answer
Answer: D (4, 3) m.
Print reference
Answers
Answer key.
- D · The example prefers an honest bounded estimate to a precise-looking wrong room.
- A · The chapter describes mixed systems to bridge the indoor and outdoor paths.
- D · (4, 3) m.
