IoT Interfaces, Location and Privacy · Study deck
GPS Location: Ranging Methods
A GPS receiver measures travel time, not a dot on a map.
UX Uma is your guide for this deck.
After studying this chapter
Learning objectives
You will be able to:
- Explain GPS/GNSS Architecture: Describe the space, control, and user segments of satellite navigation systems
- Calculate Positioning from Satellites: Apply Time of Flight and TDoA principles to determine position
- Diagnose Multipath Effects: Distinguish how signal reflections degrade positioning accuracy in different environments
- Justify Clock Synchronization: Explain why atomic clocks are essential and demonstrate how pseudoranges compensate for receiver clock errors
Major section
GPS and Outdoor Positioning
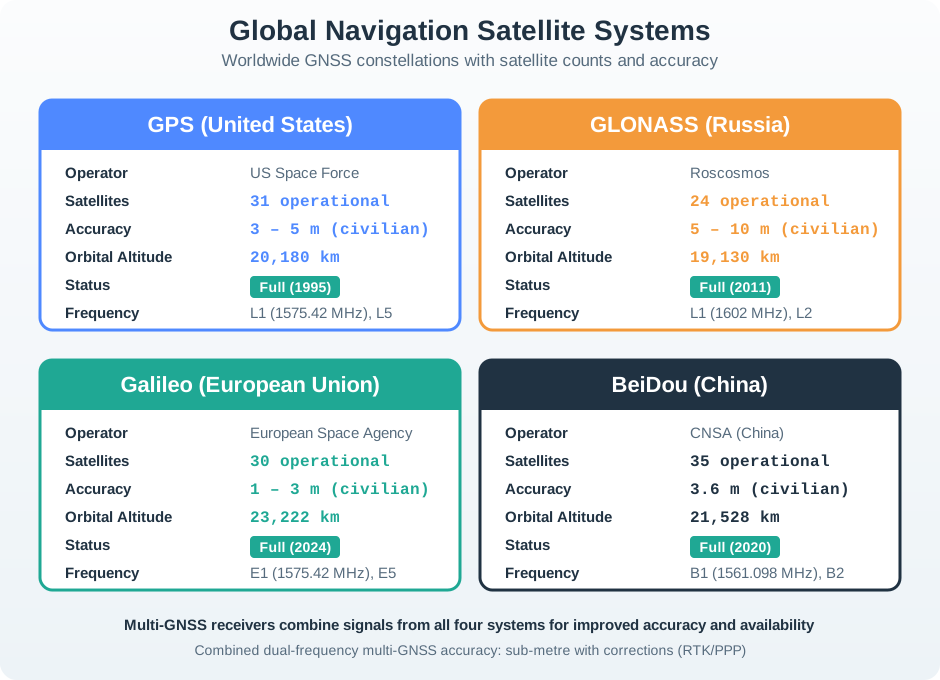
GPS (Global Positioning System) works by measuring the time it takes for radio signals to travel from satellites to your device.
- With signals from at least 4 satellites, a receiver can calculate its 3D position.
- Satellite clocks provide accurate transmission times; a 1 microsecond receiver-clock bias adds about 300 meters to each pseudorange, and the receiver estimates that bias using a fourth satellite.
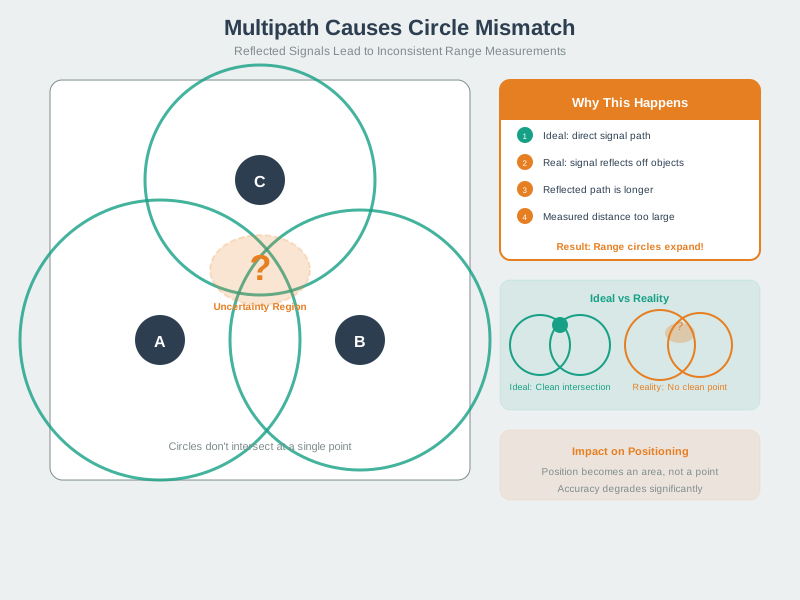
- The biggest real-world challenge is multipath -- signals bouncing off buildings in cities can degrade accuracy from 5 meters to 50+ meters.
Major section
GPS Timing as Product Context
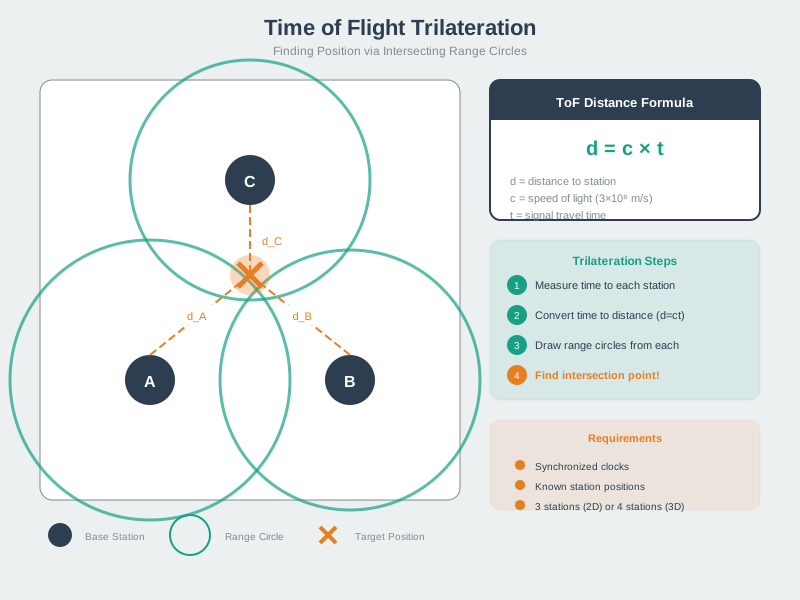
Three ranges narrow the point in three axes, but the cheap receiver clock does not match satellite time.
- GPS/GNSS is not just a map dot.
- The receiver uses signal travel time to form a pseudorange.
- A fourth range lets the solver find that clock error as well as north-south, east-west, and height.
Major section
GPS Timing as Product Context (continued)
The product decision is what the system should do with that context: show a vehicle route, confirm a gate arrival, enforce a geofence, steer a machine, timestamp a field event, or refuse an unsafe automation.
- The final point comes from a timed set of measures; it is not a direct sensor value.
- A poor sky shape, weak signal, or lost satellite can make the doubt wider even when the solver still returns a point.
- Good outdoor location design starts by separating the fix lifecycle from the user promise.
- The interface should not show all of those states as the same precise blue dot.
Major section
GPS Timing as Product Context (continued)
That distinction matters because the same receiver can be excellent in one context and misleading in another.
- A receiver may be searching, downloading assistance data, using a two-dimensional fix, using a three-dimensional fix, coasting on dead reckoning, or reporting a stale position after losing sky view.
- A field sensor with a clear antenna view may produce stable fixes every few minutes.
- The product should expose the quality difference before it triggers an action.
Major section
Receiver State Machine Design
During setup, record whether the device has a valid time source, recent almanac, recent ephemeris, enough satellites, acceptable HDOP, and a clear antenna view.
- For battery IoT devices, the correct update rate is rarely "as fast as possible." A livestock collar, rental scooter, delivery app, and safety beacon have different duty cycles.
- A dashboard can show a stale position with a timestamp and grey styling.
- A dispatch workflow can route a driver only after speed, heading, and map-matched road segment agree.
- Those rules make uncertainty operational instead of leaving support staff to explain why a blue dot looked exact.
Major section
Under the Hood: The Fix Is a Pipeline
A practical GNSS pipeline starts with RF acquisition and ends with a position, velocity, and time solution.
- The product should keep the quality fields near the coordinate.
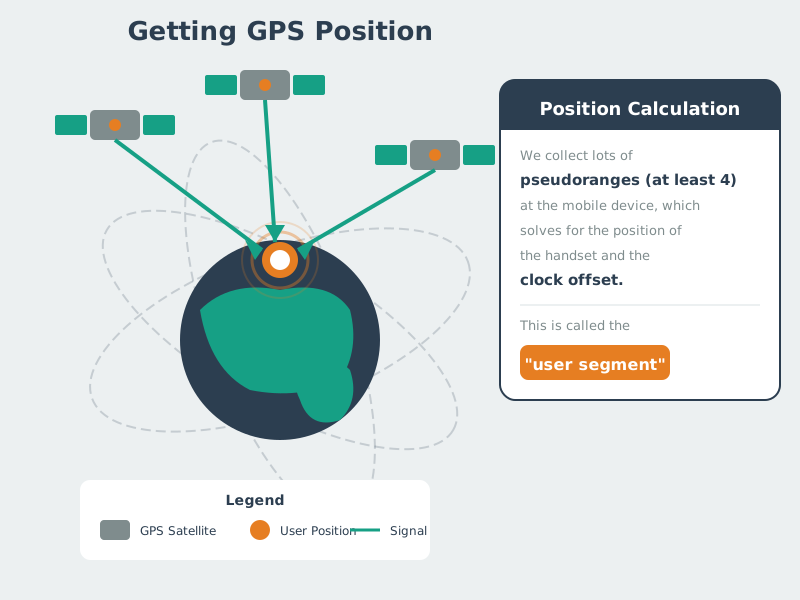
- The receiver clock is the reason GPS needs at least four satellites for a full fix.
- Each satellite gives one pseudorange equation.
Major section
Under the Hood: The Fix Is a Pipeline (continued)
Assistance and correction services change the pipeline.
- If a cloud service or map layer changes the coordinate, keep both the raw fix and the processed position so operations teams can distinguish receiver behavior from product logic.
- The unknowns are receiver x, y, z, and receiver clock offset from GNSS time.
- Assisted GNSS can provide approximate time, approximate location, almanac, or ephemeris data over a network to reduce time-to-first-fix.
Major section
Under the Hood: The Fix Is a Pipeline (continued)
Once more than four satellites are available, the solver can use an overdetermined least-squares solution and report dilution-of-precision values that describe the geometry.
- For the counterexample, leave every satellite coordinate, pseudorange, clock term, and noise value unchanged and vary only the enabled measurements from three to four.
- SBAS, DGPS, RTK, or PPP can reduce some satellite, clock, and atmospheric errors when the receiver and service support them.
- Those features should be represented in product metadata because a centimeter-capable RTK rover in fixed mode is making a different claim from a phone-grade coarse fix.
Major section
Under the Hood: The Fix Is a Pipeline (continued)
Cold-start risk: without valid time, location, almanac, or ephemeris, first fix can be slow; assisted data over SUPL or a vendor service changes startup behavior.
- Urban risk: multipath and blocked sky can pass through the solver as plausible coordinates; map matching and inertial smoothing help but can also hide real uncertainty.
- System risk: a geofence, route, or safety command should consume the quality-aware location event, not a naked latitude/longitude pair.
- Good geometry does not remove all error, but poor geometry can make otherwise valid measurements produce a weak position.
Major section
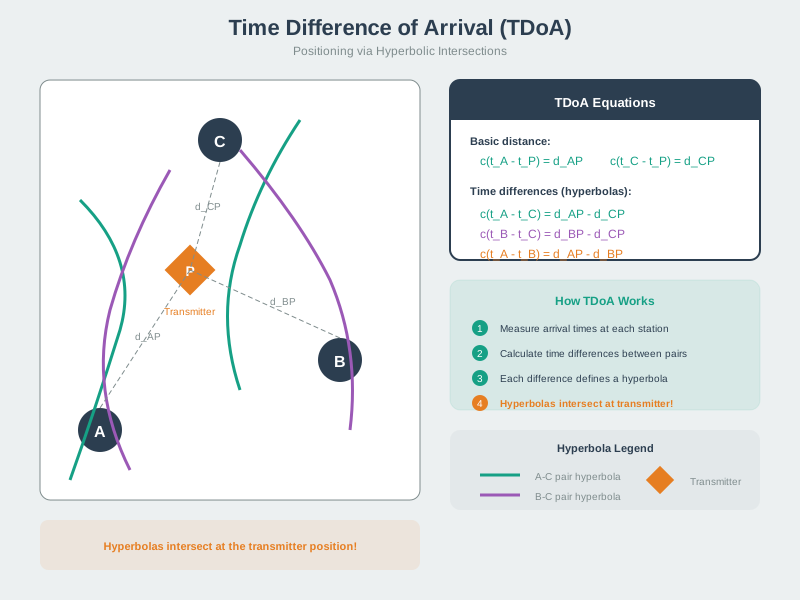
Time Difference of Arrival (TDoA)
These erroneous ranges are called pseudoranges.
- Comparing two arrival times removes the need to know the transmitter's exact send time and gives a difference in path length.
- Each station pair defines a curve of possible points; the curves intersect near the transmitter position P.
- 3D position + clock offset = 4 unknowns → need 4 satellites.
Deck summary
Key takeaways
GPS (Global Positioning System) works by measuring the time it takes for radio signals to travel from satellites to your device.
- Three ranges narrow the point in three axes, but the cheap receiver clock does not match satellite time.
- The product decision is what the system should do with that context: show a vehicle route, confirm a gate arrival, enforce a geofence, steer a machine, timestamp a field event, or refuse an unsafe automation.
- That distinction matters because the same receiver can be excellent in one context and misleading in another.
- A practical GNSS pipeline starts with RF acquisition and ends with a position, velocity, and time solution.
Retrieval practice
Recall check 1 of 2

UX Uma says: answer from memory, then check your reasoning.
Q1A receiver clock differs from satellite time. Why does a GPS range estimate need a clock-bias correction?
Show answer
Answer: C Measured travel time includes receiver clock error, so the solver must estimate that bias.
Q2A radio signal travels at 300,000,000 m/s. If its measured travel time is 2 microseconds, what range does time of flight imply before clock error?
Show answer
Answer: A 600 m.
Retrieval practice
Recall check 2 of 2
UX Uma says: answer from memory, then check your reasoning.
Q3A GPS-based delivery tracking app works well in suburban areas but shows the driver jumping between streets in downtown. What is the primary cause?
Show answer
Answer: C Multipath interference in urban canyons causes GPS signals to reflect off buildings, degrading accuracy from 5-10m to 50+ meters.
Print reference
Answers
Answer key.
- C · Measured travel time includes receiver clock error, so the solver must estimate that bias.
- A · 600 m.
- C · Multipath interference in urban canyons causes GPS signals to reflect off buildings, degrading accuracy from 5-10m to 50+ meters.