Prototyping · Study deck
Hardware Components: Power and Load Integration
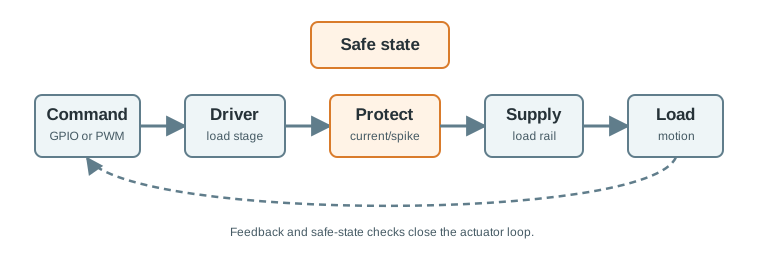
A controller pin sends a command signal; it is not the supply for the motor or valve used here.
Voltage Vera is your guide for this deck.

After studying this chapter
Learning objectives
You will be able to:
- Explain: Scope the 3.3 V controller rail while the pump starts, and record whether the controller resets, whether sensor readings shift, and whether wiring changes reduce the disturbance.
- Explain: If the same sensor later moves from a breakout board to a PCB footprint, the pull-up and placement decisions must be reviewed again.
- Explain: A firmware command that turns the pump on is not enough evidence unless the power rail, driver stage, and safe state are also understood.
- Explain: Light sensor: Sensor whose spectral response and placement match the measured light condition rather than only board convenience.
Major section
Actuators and Loads
Actuator selection starts with the load.
- A controller pin is a command signal; it is not a motor supply, heater supply, relay supply, valve supply, or lighting supply.
- The GPIO line carries a command to the driver; it does not carry the pump current.
- Current sensing or a measured output can confirm what happened after a command.
Major section
Communication Modules
Communication modules are hardware components with system-level consequences.
- They affect antenna placement, provisioning, credentials, energy use, enclosure design, update paths, and operational support.
- Provisioning path: How the module receives credentials, identity, keys, addresses, or pairing information during test and later deployment.
- Antenna evidence: Placement, ground clearance, enclosure material, cable routing, and orientation should be tested before the layout is frozen.
Major section
Power, Protection, Level Fit
Many integration failures are caused by treating the power tree as an afterthought.
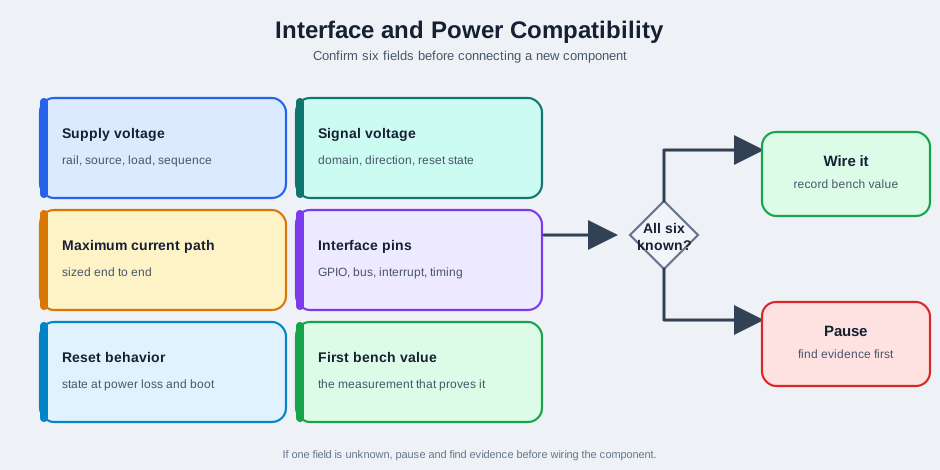
- A GPIO can command a driver but cannot power that load.
- The six fields then expose missing facts: startup current, driver input, and safe reset state still need evidence.
- Until those checks and a suitable driver and protection are chosen, the gate says pause.
Major section
Power, Protection, Level Fit (continued)
The first bench value is a measured startup current from a current-limited supply; the rail should also be scoped during pump start.
- GPIO needs voltage compatibility, pull state, drive strength, interrupt behavior, and reset defaults.
- Analog inputs need input range, source impedance, filtering, reference stability, and noise review.
- I2C-style buses need address uniqueness, pull-up selection, bus capacitance, shared-ground integrity, and recovery from a stuck device.
Major section
Bench Tools and Evidence
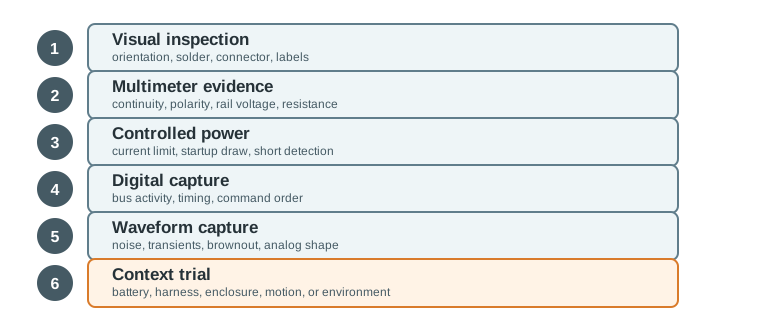
A team with only a working demo but no measurements has weak evidence.
- Visual inspection catches orientation, connector, and solder faults before power is applied.
- Digital capture answers a different question: whether bus traffic and command order match the intended sequence.
- Waveform capture can reveal transients, noise, or a brownout that a digital trace misses.
Major section
Incremental Examples
A classroom logger needs temperature readings inside a plastic enclosure.
- A BME280 breakout looks convenient, but the acceptance decision should stay tied to the measurement task.
- The component can be accepted only if the team can explain both the measurement fit and the interface fit.
- A plant-watering prototype needs a small 5 V pump.
Major section
Incremental Examples (continued)
The logger must record temperature, humidity, light level, and enclosure-open events while supporting local storage and small-battery operation.
- If the same sensor later moves from a breakout board to a PCB footprint, the pull-up and placement decisions must be reviewed again.
- The controller GPIO cannot power that load directly, so the component decision includes the pump, driver, supply, protection, and feedback path.
- Component acceptance therefore needs evidence for both the readings and the electrical connections.
Major section
Incremental Examples (continued)
Scope the 3.3 V controller rail while the pump starts, and record whether the controller resets, whether sensor readings shift, and whether wiring changes reduce the disturbance.
- A firmware command that turns the pump on is not enough evidence unless the power rail, driver stage, and safe state are also understood.
- Once the sensor bus is stable, add local storage and observe writes during reset and low-power transitions.
- Controller: Development board with enough digital buses, sleep support, serial logging, and accessible test points.
- Temperature and humidity sensor: Digital sensor with documented accuracy, mounting guidance, calibration notes, and environmental limits.
Major section
Incremental Examples (continued)
Light sensor: Sensor whose spectral response and placement match the measured light condition rather than only board convenience.
- Accepted: The component meets the requirement, works with the selected interface, survives the power state, and has a recorded bench result.
- Rejected: The component fails a requirement, creates electrical risk, lacks enough documentation, or blocks a later layout decision.
- Deferred: The component might fit later, but the current prototype does not need its complexity or cannot test it yet.
Deck summary
Key takeaways
Actuator selection starts with the load.
- Communication modules are hardware components with system-level consequences.
- Many integration failures are caused by treating the power tree as an afterthought.
- The first bench value is a measured startup current from a current-limited supply; the rail should also be scoped during pump start.
- A team with only a working demo but no measurements has weak evidence.
Retrieval practice
Recall check 1 of 4
Voltage Vera says: answer from memory, then check your reasoning.
Q1A controller pin must switch a pump. What belongs in the load path before approving the prototype?
Show answer
Answer: A The controller command and the load supply have different jobs.
Retrieval practice
Recall check 2 of 4
Voltage Vera says: answer from memory, then check your reasoning.
Q2A valve controller loses power while its output pin is floating. What should the design record specify?
Show answer
Answer: A The actuator needs a known state even when firmware cannot act.
Retrieval practice
Recall check 3 of 4
Voltage Vera says: answer from memory, then check your reasoning.
Q3A sensor measures the right physical quantity, but its data pin uses a higher logic voltage than the controller input. What is the best next review action?
Show answer
Answer: D The component may still be usable, but the interface boundary needs evidence before the prototype is powered.
Retrieval practice
Recall check 4 of 4
Voltage Vera says: answer from memory, then check your reasoning.
Q4A BME280 breakout reports plausible temperature and humidity values on a 10 cm jumper harness, but it fails intermittently when moved to an 80 cm cable inside the enclosure. Which evidence should drive the next component decision?
Show answer
Answer: B The component decision depends on the actual interface and placement boundary the prototype will use.
Print reference
Answers
Answer key.
- A · The controller command and the load supply have different jobs.
- A · The actuator needs a known state even when firmware cannot act.
- D · The component may still be usable, but the interface boundary needs evidence before the prototype is powered.
- B · The component decision depends on the actual interface and placement boundary the prototype will use.