Design Methodology · Study deck
Accelerometer Datasheets: Validation Evidence
A typical current is a data-sheet example, not a promise for every board.
Blueprint Bina is your guide for this deck.
After studying this chapter
Learning objectives
You will be able to:
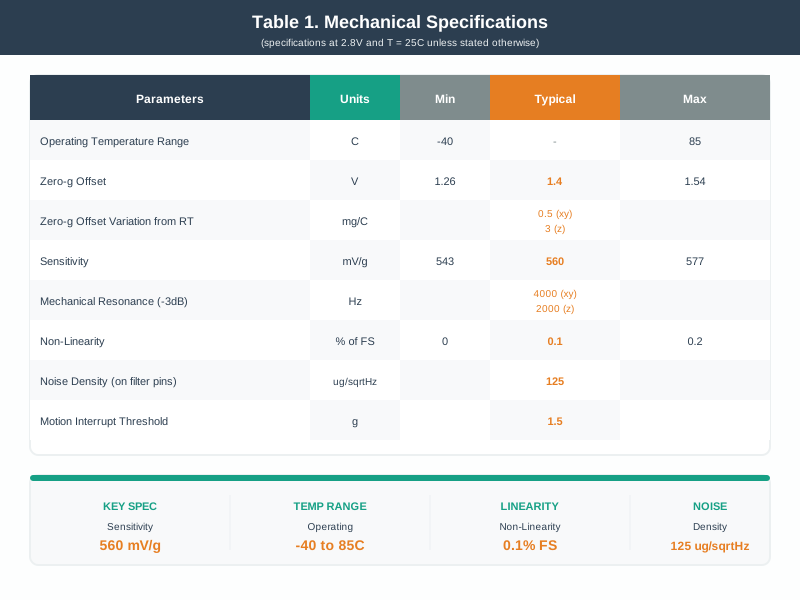
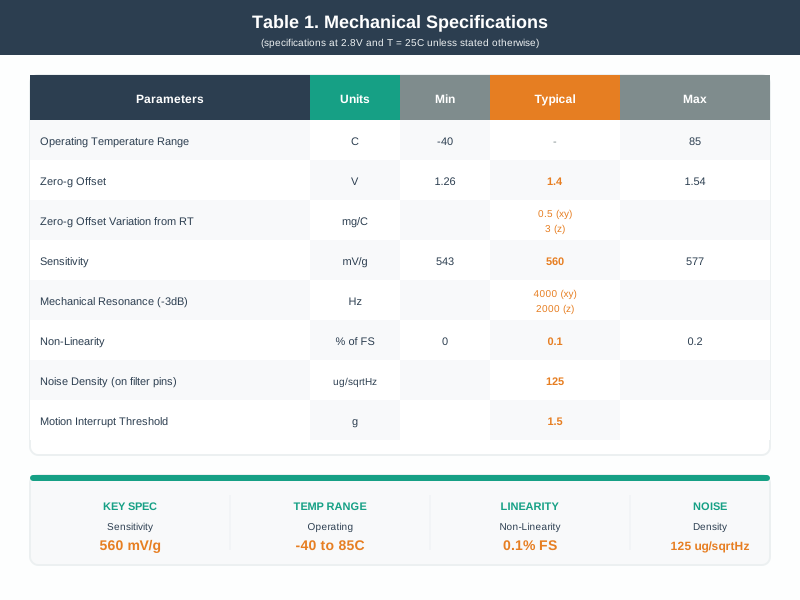
- Explain: The Parameters: Units: Min: Typical, and: Max columns establish which values are bounded across parts and conditions, which are merely typical, and which must be converted into firmware and bench-test assumptions.
- Explain: The team chooses the ADXL345 range, BW_RATE, POWER_CTL, INT_ENABLE, INT_MAP, THRESH_ACT, and TIME_INACT settings, then captures interrupt timing while the tag is shaken, left idle, and exposed to background vibration.
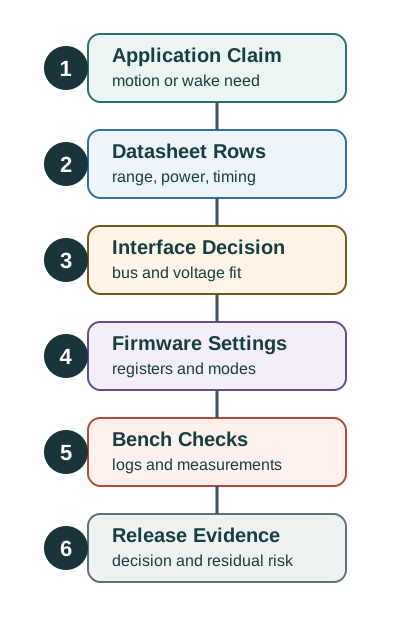
- Explain: The six-stage route in Figure: The same route can be checked by asking starts with an application claim and datasheet rows; check where range, power, and timing evidence belongs.
Major section
Start With the Decision
A typical current is a data-sheet example, not a promise for every board.
- Offset is the reading error at a known starting input.
- Bench proof measures the actual board under those conditions before the design accepts the number.
Major section
Range and Resolution
Accelerometer range selection starts with clipping risk.
- Resolution only matters after the sensor can survive and represent the acceleration range the product will see.
- Tilt Small motion Gravity-dominated orientation use cases often prefer a low range, provided installation shocks and transport events are handled separately.
- In ADXL345 full-resolution mode, the scale factor remains about 4 mg per LSB while the selected range changes the full-scale limit.
Major section
Interface, Voltage, and Host Fit
A common datasheet failure is checking the sensor supply but missing the I/O voltage and bus timing.
- The ADXL345 separates sensor supply and I/O supply.
- Your schematic review must show both are valid for the selected host and bus.
- Pin budget, bus sharing, pullups, timing limits, driver support, and trace observability.
Major section
Register Defaults Are Not a Design
If a release record cannot say which range, data format, output data rate, FIFO mode, interrupt mapping, and power mode are configured, the datasheet review is incomplete.
- Defaults may be useful for first communication, but release behavior should be explicit.
Major section
Power, FIFO, and Interrupt Strategy
Low-power accelerometer design is not only about the sensor current.
- The device can stop measuring while the product is inactive or during transport/storage states.
- The product needs continuous motion awareness but can accept the mode's performance trade-offs.
- The MCU should wake on useful motion rather than polling samples continuously.
Major section
Range, Noise, and Release Decision
The Parameters: Units: Min: Typical, and: Max columns establish which values are bounded across parts and conditions, which are merely typical, and which must be converted into firmware and bench-test assumptions.
- The Parameters, Units, Min, Typical, and Max columns establish which values are bounded across parts and conditions, which are merely typical, and which must be converted into firmware and bench-test assumptions.
- Across the Operating temperature, zero-g offset, sensitivity, and mechanical resonance are listed in the accelerometer specification table diagram, begin with the -40 to 85 C operating range, then compare the 1.26 / 1.4 / 1.54 V zero-g offset bounds with zero-g drift of 0.5 mg/C on x-y and 3 mg/C on z.
Major section
Bench Validation Summary
Final enclosure or mounting may change interpretation.
- Field shocks outside the profile may still clip.
- Thresholds may need pilot tuning.
- Battery chemistry and temperature still need system validation.
- Temperature and aging may need follow-up checks.
Major section
Incremental Examples
A first bench pass can use an Arduino, Raspberry Pi Pico, or ESP32 board with an ADXL345 breakout over I2C.
- A Saleae Logic, Bus Pirate, or sigrok/PulseView capture can confirm the I2C address, register reads, and pullup voltage.
- This evidence proves communication and axis mapping; it does not yet prove wake-on-motion, battery life, or field vibration behavior.
- The first bench pass should tie a physical connection to an observed reading.
- In the This ADXL345 breakout is the physical board in the six-orientation bench pass. Its labeled interface pads make the communication choice inspectable, while the square sensor package at the center is what must be mapped to the product enclosure's X, Y, and Z axes. Photo: SparkFun Electronics, CC BY 2.0 diagram, the GND and VCC pads identify the power connections on the breakout board; the labeled data pads show where the host interface is attached.

Major section
Incremental Examples (continued)
In Figure: This ADXL345 breakout is the physical board in, the GND and VCC pads identify the power connections on the breakout board; the labeled data pads show where the host interface is attached.
- The sensor package sits at the center, beside the printed axis marks.
- That layout matters when the six known board orientations are compared with logged X, Y, and Z counts.
- A device ID read and bus trace can confirm communication, while the axis test checks the map and polarity.
- An equipment tag can use activity and inactivity interrupts so the MCU sleeps between useful motion events.
Major section
Incremental Examples (continued)
The team chooses the ADXL345 range, BW_RATE, POWER_CTL, INT_ENABLE, INT_MAP, THRESH_ACT, and TIME_INACT settings, then captures interrupt timing while the tag is shaken, left idle, and exposed to background vibration.
- A Joulescope, Nordic Power Profiler Kit, or calibrated current probe records sleep, wake, sample, and transmit current.
- The release claim should name the configured thresholds, the observed false-wake behavior, and the battery model used for the estimate.
- A field-ready product should repeat the selection check across board revision, enclosure orientation, firmware hash, and installation profile.
Major section
Choose ADXL345 Evidence
The final stages require bench measurements and a release record, connecting the initial need with tested behavior.
- The six-stage route in Figure: The same route can be checked by asking starts with an application claim and datasheet rows; check where range, power, and timing evidence belongs.
- The six-stage route in the The same route can be checked by asking which artifact belongs at each stage of the accelerometer decision diagram starts with an application claim and datasheet rows; check where range, power, and timing evidence belongs.
Major section
1. Feature Lists Are Not Reviews
"Supports FIFO" or "supports interrupts" is not enough.
- The review must show how the firmware configures the feature and how bench evidence proves it works on the board.
Major section
2. Choose Range From Motion Profile
Range selection should come from expected acceleration, installation, shipping, handling, and field events.
- A low range can produce clean-looking data until the first real event clips.
Major section
5. State Calibration and Drift
Raw accelerometer output includes offset and variation.
- A release record should state whether the product uses factory trim, board-level calibration, field calibration, software compensation, or no compensation.
Major section
Summary
An accelerometer datasheet becomes useful when it is connected to a design claim.
- The strongest workflow is to extract the relevant rows, configure firmware explicitly, verify board behavior on the bench, and record residual risk.
- The datasheet supports the decision, but the assembled product still needs evidence.
Major section
Key Takeaway
The accelerometer case study shows why part selection depends on range, noise, bandwidth, power, interface, and calibration needs.
- The best component is the one whose real limits fit the application.
Deck summary
Key takeaways
A typical current is a data-sheet example, not a promise for every board.
- Accelerometer range selection starts with clipping risk.
- A common datasheet failure is checking the sensor supply but missing the I/O voltage and bus timing.
- If a release record cannot say which range, data format, output data rate, FIFO mode, interrupt mapping, and power mode are configured, the datasheet review is incomplete.
- Low-power accelerometer design is not only about the sensor current.
Retrieval practice
Recall check 1 of 3

Blueprint Bina says: answer from memory, then check your reasoning.
Q1What provides sensor selection evidence without proving the board achieved the datasheet feature?
Show answer
Answer: B Datasheet rows belong with the bounded claim because they are selection evidence, not proof that the board achieved the feature.
Retrieval practice
Recall check 2 of 3
Blueprint Bina says: answer from memory, then check your reasoning.
Q2A team chooses the smallest accelerometer range because it wants high sensitivity, but field logs show repeated saturated raw readings during normal handling. What should the datasheet review conclude?
Show answer
Answer: B Range selection is an evidence decision.
Retrieval practice
Recall check 3 of 3
Blueprint Bina says: answer from memory, then check your reasoning.
Q3The datasheet says the accelerometer supports FIFO and activity interrupts. What is the strongest release evidence for a low-power wake design?
Show answer
Answer: D Release evidence connects datasheet features to firmware settings and measured board behavior.
Print reference
Answers
Answer key.
- B · Datasheet rows belong with the bounded claim because they are selection evidence, not proof that the board achieved the feature.
- B · Range selection is an evidence decision.
- D · Release evidence connects datasheet features to firmware settings and measured board behavior.