 Phoebe guides
A field team faces an unresolved physical question: How 20 mV becomes useful ADC resolution They must answer it before changing instrumentation amplifier gain on the real device. Predict the direction first.
See the relationship before changing it
The chapter figure below shows: Signal conditioning prepares a small sensor signal for ADC conversion through gain, filtering, level shifting, and sampling.
The retained audit below checks several chapter fixtures. This added model holds every other chapter fixture fixed, so the numeric fixture does not switch without explanation.
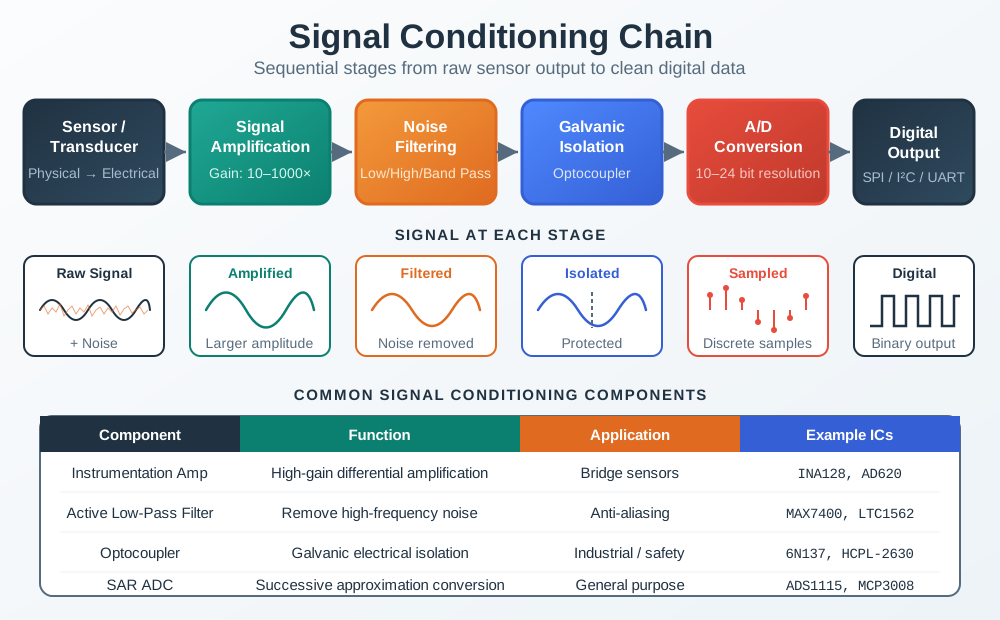
Derive the baseline in four named moves
- 1
Name the input. The chapter baseline for instrumentation amplifier gain is 150.
- 2
Name the relationship. V_span=G V_sensor; q=V_ADC,FS/4096; ΔT=q/(G S); |H|=1/√(1+(f/f_c)²)
- 3
Substitute the chapter fixture. Set instrumentation amplifier gain to 150. The ideal 3.3 V ADC code width is 0.806 mV regardless of gain.
- 4
Read the result. Keep mV beside the value. Use it only inside the technical boundary on this page.
Predict, then change instrumentation amplifier gain
Try Predict the direction of temperature per code. Move one control, calculate, then check your prediction.
Observe All four readouts use the same gain, division, slope, and first-order filter formulas derived on this page. Reset the control to 150 and compare temperature per code.
Explain Only instrumentation amplifier gain moves here; ADC code width stays fixed. The other chapter fixtures remain fixed.
Check yourself
What should you do before trusting a moved-control result?
What does this small model leave out?
1. Start with a small span
The sensor moves from 10 to 30 mV, a span of 20.0 mV. Gain multiplies the difference from the chosen offset; it does not create information that the sensor never produced.
2. Size the gain
To fill 3.3 V exactly, G = 3.3/0.0200 = 165. The chapter chooses a practical 150×, so the sensor span becomes 0.0200×150 = 3.00 V and leaves headroom.
3. Turn the span into converter steps
Count binsA 12-bit ADC has 4,096 codes.
Divide the ADC full-scale span3.3 V/4,096 = 0.000806 V = 0.806 mV/count.
Refer the step back to temperature0.806/(150×1.00 mV/C) = 0.00537 C/count.
4. Try the practical gain
TryMove the gain and stop at the chapter's practical 150× setting.
ObserveAt 150× the span is 3.00 V, the bin is 0.806 mV, the referred step is 0.00537 C, and the filter gives −15.7 dB at 60 Hz.
ExplainAll four readouts use the same gain, division, slope, and first-order filter formulas derived on this page.
The conditioning calculation assumes a linear amplifier and a valid 1 mV/C sensor slope, with converter and filter settings held fixed. The computed span, code width, and filter attenuation still require measured evidence before they describe the installed measurement chain.
- measured evidence
- Needs separate evidence
Use field evidence or a deeper model before release.
5. Derive the filter answer
For 16 kohm and 1 uF, RC = 0.016 s and f_c = 1/(2πRC) = 9.95 Hz. At 60 Hz, |H| = 1/√[1+(60/9.95)²], so 20log₁₀|H| = −15.7 dB.
6. Keep loading separate
A 10 kohm source feeding 10 Mohm loses only 0.0999% through the divider. Feeding 100 kohm loses 9.09%. A buffer protects the voltage; it does not replace the gain or anti-alias filter.
7. Check yourself
Why choose 150× instead of 165×?
What is the ideal 12-bit step across the full 3.3 V ADC range?
Does the buffer provide anti-alias filtering?
The conditioning calculation assumes a linear amplifier and a valid 1 mV/C sensor slope, with converter and filter settings held fixed. The computed span, code width, and filter attenuation still require measured evidence before they describe the installed measurement chain.
- 20.0 mV span
- Unamplified sensor voltage span
- gains 165
- Gain that exactly fills converter range
- 150
- Practical amplifier gain leaving voltage headroom
- 3.00 V
- Amplified sensor voltage span
- 4,096 codes
- Twelve-bit analog-to-digital converter code count
- 0.806 mV/count
- Converter code width across full voltage range
- 0.00537 C/count
- Input-referred temperature change per converter count
- 16 kohm
- Low-pass filter resistance
- 1 uF
- Low-pass filter capacitance
- 9.95 Hz
- Low-pass filter cutoff frequency
- −15.7 dB
- Filter attenuation at sixty hertz
- loading examples reproduce the chapter's ideal calculations
- Ideal source-loading voltage-loss comparisons
Treat these figures as teaching evidence, not as a complete release claim.