 Max guides
A technician must decide whether angular deadband is safe before changing servo deadband on the real device. The result is unresolved until the rule and units are checked. Predict the direction first.
See the relationship before changing it
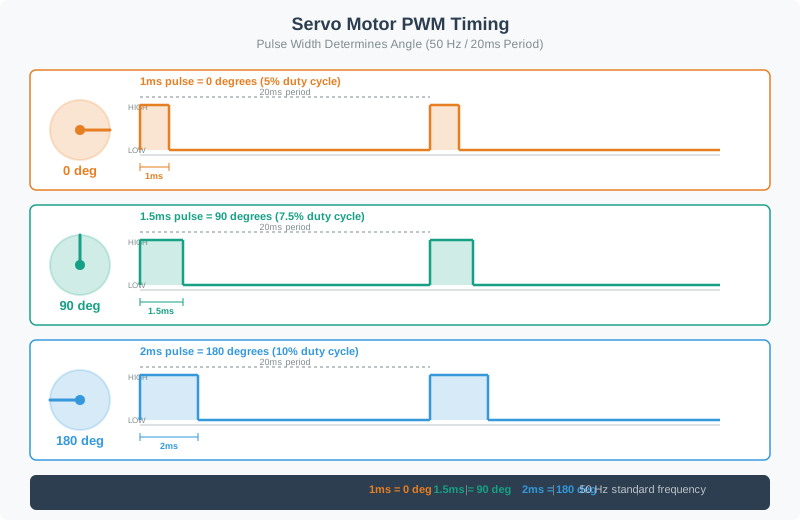
The chapter figure below shows: A servo repeats a 20 ms frame while high pulses of 1.0, 1.5, and 2.0 ms command increasing angles.
The retained audit below checks several chapter fixtures. This model keeps those stated values fixed and changes only servo deadband, so the numeric fixture does not switch without explanation.
Derive the baseline in four named moves
- 1
Name the input. The chapter baseline is 5 us.
- 2
Name the relationship. angle = deadband x 180 degrees / 1,900 us
- 3
Substitute with units. 5 x 180 / 1,900 = 0.474 degrees
- 4
Read the result. Keep the unit beside the value. Use it only inside the technical boundary on this page.
Predict, then change servo deadband
Try Predict the direction of angle = deadband x 180 degrees / 1,900 us. Test another servo deadband, then compare angular deadband.
Observe A wider timing deadband creates a wider angle that the servo cannot resolve. Reset servo deadband to 5 and compare angular deadband.
Explain Servo deadband ignores a span of pulse durations, so a wider ignored pulse span corresponds to a proportionally wider range of unresolved command angles.
Check yourself
What should you do before trusting a moved-control result?
What does this small model leave out?
1. A servo receives timed commands
The frame repeats at 50 Hz. Pulse width chooses angle. A timer rounds pulse width to fixed ticks. The servo also ignores a small deadband to avoid hunting.
2. Map pulse width to angle
Find the pulse span2,400−500=1,900 µs.
Spread 180 degreesq=180°/1,900 per 1 µs.
Find RMS roundingσq=q/√12.
3. Add sampling and deadband
Nyquist limits motion content. Timer ticks limit requested angle spacing. Deadband is a larger physical no-response zone.
4. Try the servo deadband
TryChange the deadband while the chapter's timer and 50 Hz stream stay fixed.
ObserveAt ±5 µs, the 50 Hz stream gives 25 Hz, the chapter's sweep has 50× sampling margin, one timer tick is 0.0947°, RMS rounding is 0.0273°, and deadband is ±0.474° or 17.3× the RMS floor.
ExplainThe physical deadband, not the timer's tiny rounding error, sets the larger fine-position limit in this example. The 25 Hz value answers a separate motion-speed question.
The timing-to-angle conversion assumes a straight-line mapping across 180 degrees and a 1,900 us pulse span, with the timer and 50 Hz command stream fixed. It does not model actual servo endpoints, potentiometer noise, backlash, load, torque and speed, supply sag, controller tuning, horn geometry, saturation, jitter, or mechanical stops.
- servo-specific endpoints
- Needs separate evidence
- potentiometer noise
- Needs separate evidence
- gear backlash
- Needs separate evidence
- load
- Needs separate evidence
- torque-speed behaviour
- Needs separate evidence
- supply sag
- Needs separate evidence
- control-loop tuning
- Needs separate evidence
- horn geometry
- Needs separate evidence
- saturation
- Needs separate evidence
- jitter
- Needs separate evidence
- mechanical stops
- Needs separate evidence
Use field evidence or a deeper model before release.
5. Read the one-second sweep
A 0°→180°→0° cycle taking about two seconds has a fundamental near 0.5 Hz. The 25 Hz Nyquist ceiling is 50 times higher, so command sampling is comfortable even though mechanics may still lag.
6. Verify position safely
Calibrate real endpoints under load. Record supply current, pulse width, measured angle, deadband, repeatability, backlash, temperature, stall behaviour, and the safe parked state.
7. Check yourself
What angle does one microsecond represent here?
Why is ±0.474° larger than 0.0273°?
Does a 25 Hz command limit mean the horn can move at 25 Hz?
The timing-to-angle conversion assumes a straight-line mapping across 180 degrees and a 1,900 us pulse span, with the timer and 50 Hz command stream fixed. It does not model actual servo endpoints, potentiometer noise, backlash, load, torque and speed, supply sag, controller tuning, horn geometry, saturation, jitter, or mechanical stops.
- 50 Hz
- Servo command refresh rate
- 20 ms
- Servo command frame period
- 500–2,400 µs
- Assumed servo pulse-width endpoints
- 1,900 µs
- Pulse-width span for full travel
- 180°
- Assumed full servo travel
- 25 Hz
- Command-stream Nyquist frequency
- 0.5 Hz
- Example sweep fundamental frequency
- 50×
- Nyquist ceiling divided by sweep frequency
- 1 µs
- Timer tick duration
- 0.0947°
- Angle represented by one timer tick
- 0.0273°
- Root mean square timer-rounding angle error
- ±5 µs
- Pulse-width deadband magnitude
- ±0.474°
- Angular deadband magnitude
- 17.3×
- Deadband divided by timer-rounding error
- around-1° whole-servo
- Approximate whole-servo angular resolution
They do not certify loaded positioning.